VEX V5 Robotics Competition Override - Game Manual  | |||||||||||||||||||||||||||||||||||
Appendix B - Glossary of TermsAdult - Anyone who is not a Student or another defined term (e.g., Head Referee ). Alliance - A pre-assigned grouping of two Robots that are paired together during a given Head-to-Head Match. Alliance Captain - One of the Teams with the privilege of inviting another available Team to form an Alliance for Elimination Matches. See T16. Alliance Selection - The process of choosing the permanent Alliances for Elimination Matches. The Alliance Selection proceeds as follows:
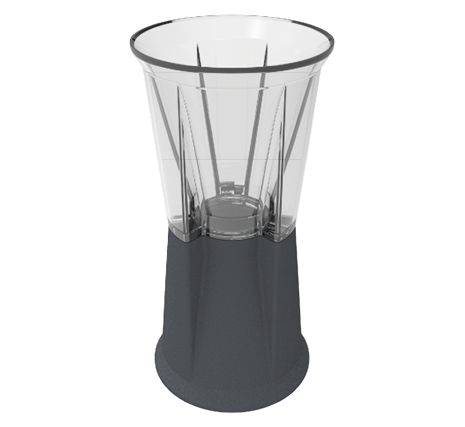
Alliance Station - The designated regions where the Drive Team Members must remain for the duration of the Match. Autonomous Bonus - A point bonus awarded to the Alliance that has earned the most points at the end of the Autonomous Period. See SC7 for more information. Autonomous Coding Skills Match - see Match. Autonomous Line - The pair of white tape lines that run diagonally across the Field and around the Midfield, and the space between those lines. See SG7 for more information. Autonomous Period - A time period during which Robots operate and react only to sensor inputs and pre-programmed commands. Autonomous Points (AP) - The second basis of ranking Teams. An Alliance who wins the Autonomous Bonus during a Qualification Match earns ten (10) Autonomous Points. In the event of a tie, both Alliances will receive five (5) Autonomous Points. Autonomous Win Point (AWP) - An additional Win Point awarded to any Alliance that has completed a defined set of tasks at the end of the Autonomous Period of a Qualification Match. Both Alliances can earn an Autonomous Win Point if both Alliances accomplish these tasks. See SC7 for more information. Builder - Any Student Team member who helps build the Robot. Adults are permitted to teach Builders associated concepts, but should never work on the Robot. Bye - A situation in which an Alliance automatically advances to the next round of Tournament play without competing. Coder - Any Student Team member who contributes to the computer code that is downloaded onto the Robot. Adults are permitted to teach Coders associated concepts, but should never work on the code that goes on the Robot. Cup - A Scoring Object, measuring approximately 3.15” (80mm) in diameter and 6.5” (164.5mm) tall. Each Cup consists of two halves: one transparent and one opaque.
Figure C-1: A Cup Defensive - A category of strategies, Robot actions, and/or Robot statuses that can be employed by a Team during a Match ; see rules GG14 and GG15 for more information. A Robot is Defensive while it is engaged in actions that cannot increase its Alliance’s score for the current Match, and instead limits an opponent’s ability to score or play the game. A Robot can be in Possession of a Scoring Object and capable of scoring, but still be Defensive based on its actions. Examples include, but are not limited to:
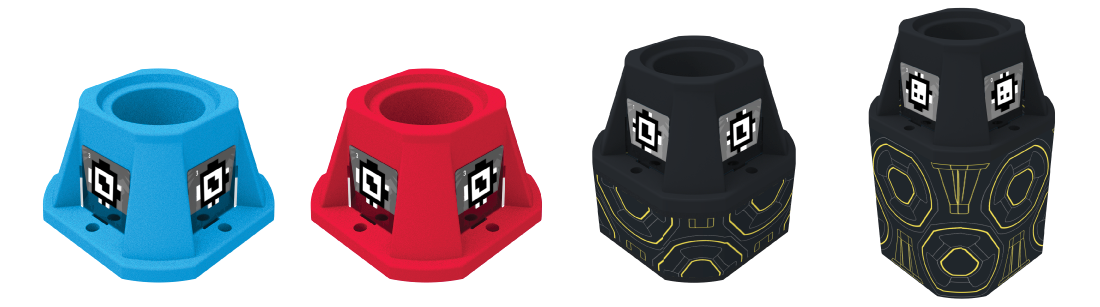
Designer - Any Student Team member who helps design the Robot to be built for competition. Adults are permitted to teach Designers associated concepts, but should never work on the design of the Robot. Disablement - A penalty applied to a Team for a safety Violation. A Team that receives a Disablement is not allowed to operate their Robot for the remainder of the Match, and the Drive Team Member (s) will be asked to place their controller(s) on the ground or another safe location outside of the Field, as directed by the Head Referee. Disqualification - A penalty applied to a Team for a Major Violation (see GG6 for more details). If a Team receives a Disqualification in a Match, the Head Referee will notify the Team of their Violation at the end of the Match. A Team that receives a Disqualification in a Qualification Match receives zero Win Points, zero Autonomous Win Points, zero Autonomous Points, and zero Strength of Schedule Points. When a Team receives a Disqualification in an Elimination Match, the entire Alliance is Disqualified and they receive a loss for the Match. At the Head Referee’s discretion, repeated Violations and/or Disqualifications for a single Team may lead to its Disqualification for the entire Tournament (see GG6 ). A Team that receives a Disqualification in a Driving Skills Match or Autonomous Coding Skills Match receives a score of zero for that Robot Skills Match. Drive Team Member - A Student who stands in the Alliance Station during a Match. Adults are not allowed to be Drive Team Members. See rule GG1. Driver Controlled Period - A time period during which Drive Team Members operate their Robot using a VEX V5 controller. Driving Skills Match - see Match. Elimination Bracket - A schedule of Elimination Matches for eight (8) to sixteen (16) Alliances. See T17. Elimination Match - see Match. Endgame - A time period consisting of the last 10 seconds of a Head-to-Head Match, in which Robots attempt to end the Match in the Midfield. See rule SG12. Entanglement - A Robot status. A Robot is Entangled if it has grabbed, hooked, or attached to an opposing Robot or a Field Element. See rule GG14. Event Partner - The volunteer VEX V5 Robotics Competition Tournament coordinator who serves as an overall manager for the volunteers, venue, event materials, and all other event considerations. Field - The entire playing Field, comprising the Floor and the Field Perimeter. Field Element - The Field, white tape, Loaders, Goals, Toggles, and all supporting structures and accessories (such as field monitors, etc.). Field Perimeter - The outer part of the Field, made up of 12 straight sections. Floor - The interior flat part of the playing Field, made up of an array of six (6) gray foam field tiles wide by six (6) gray foam field tiles long (totaling 36 Field tiles) that are within the Field Perimeter. Game Design Committee (GDC) - The creators of Override, and authors of this Game Manual. The Game Design Committee is the only official source for rules clarifications and Q&A responses; see Section 1. Goal - One of the nine (9) designated locations around the Field in which Robots attempt to score Pins and Cups. Goals are octagonal, and each Goal is one of three colors: red, blue, or black. The center Goal is 8.7” (222.7mm) tall, neutral Goals in Quadrants are 5.8” (146.5mm) tall, and Alliance -specific Goals are 3.25” (82.5mm) tall.
Figure G-1: The four types of Goals in a VEX V5 Override Match Head Referee - A certified impartial volunteer responsible for enforcing the rules in this manual as written. Head Referees are the only people who may discuss ruling interpretations or scoring questions with Teams at an event. Large events (e.g., Signature Events, World Championships, etc.) might include multiple Head Referees at the Event Partner’s discretion. Head-to-Head Match - see Match. Holding - A Robot status; see rule GG17 for more information. Holding is legal until it exceeds the limits in GG17. A Robot is considered to be Holding if it meets any of the following criteria during a Match :
Loader - One of the four designated locations (two per Alliance ) around the Field where Drive Team Members can introduce Match Load Pins and Cups. See rule SG11.
Figure L-1: A Loader Load Zone - An infinitely tall three-dimensional volume bounded by the inner edges of the Field Perimeter and the outer edges of the red or blue tape lines surrounding each Loader. Match - A set time period, consisting of an Autonomous Period and/or Driver Controlled Periods, during which Teams play a defined version of Override to earn points. Match types:
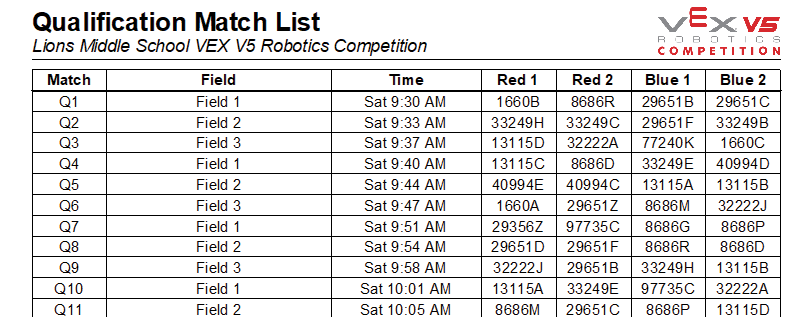
Match Load - One of the 20 Cups, 10 per Alliance, or 22 Pins, 11 per Alliance, that begin the Match in an Alliance Station and which may be introduced during the Match. See rule SG11. Match Schedule - A list of Matches that is generated at the start of an event. The Match Schedule includes the predetermined, randomly-paired Alliances that will be competing in each Qualification Match, and the expected start times for these Matches. The Match Schedule may be subject to change at the Event Partner’s discretion.
Figure MS-1: An example of a Qualification Match Schedule Midfield - The square-shaped central area of the Field in which Robots attempt to end the Match to score additional points. The Midfield is an infinitely tall three-dimensional volume bounded by the inner edges of the white tape line square, and can be entered by all Robots during the Autonomous Period See Figure Q-1. Notebooker - Any Student Team member who contributes to the Team’s engineering notebook or associated documentation. Adults are permitted to teach Notebookers associated concepts, but should never work on the engineering notebook or other documentation. Offensive - A category of strategies, Robot actions, and/or Robot statuses that can be employed by a Team during a Match ; see rules GG14 and GG15 for more information. A Robot is Offensive while it is engaged in actions that could directly increase its Alliance’s score for the current Match. Examples include, but are not limited to:
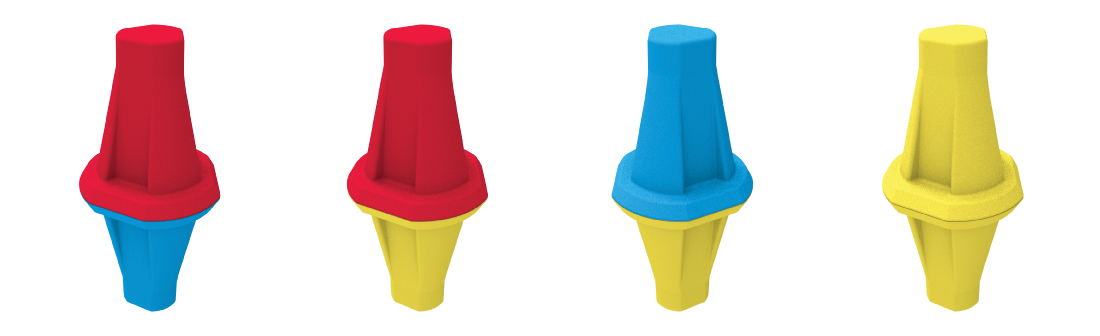
Owned - A yellow Pin status. A Placed yellow Pin is Owned by an Alliance if the Toggle in that Quadrant is set to the Alliance’s color. Placed - A Scoring Object status. See SC2. Plowing - A Robot / Scoring Object status. A Robot is considered to be Plowing a Scoring Object if the Robot is intentionally moving it in a preferred direction with a flat or convex face of the Robot or with another Scoring Object. Pin - A Scoring Object measuring approximately 1.6” (40mm) in diameter and 6.5” (165mm) tall. Each Pin consists of two halves, and each half is red, blue, or yellow.
Figure P-1: The four types of Pins in a VEX V5 Override Match Possession - A Robot / Scoring Object status. A Scoring Object is considered Possessed by a Robot if a Robot’s change in direction would result in controlled movement of the Scoring Object. This typically requires at least one of the following to be true:
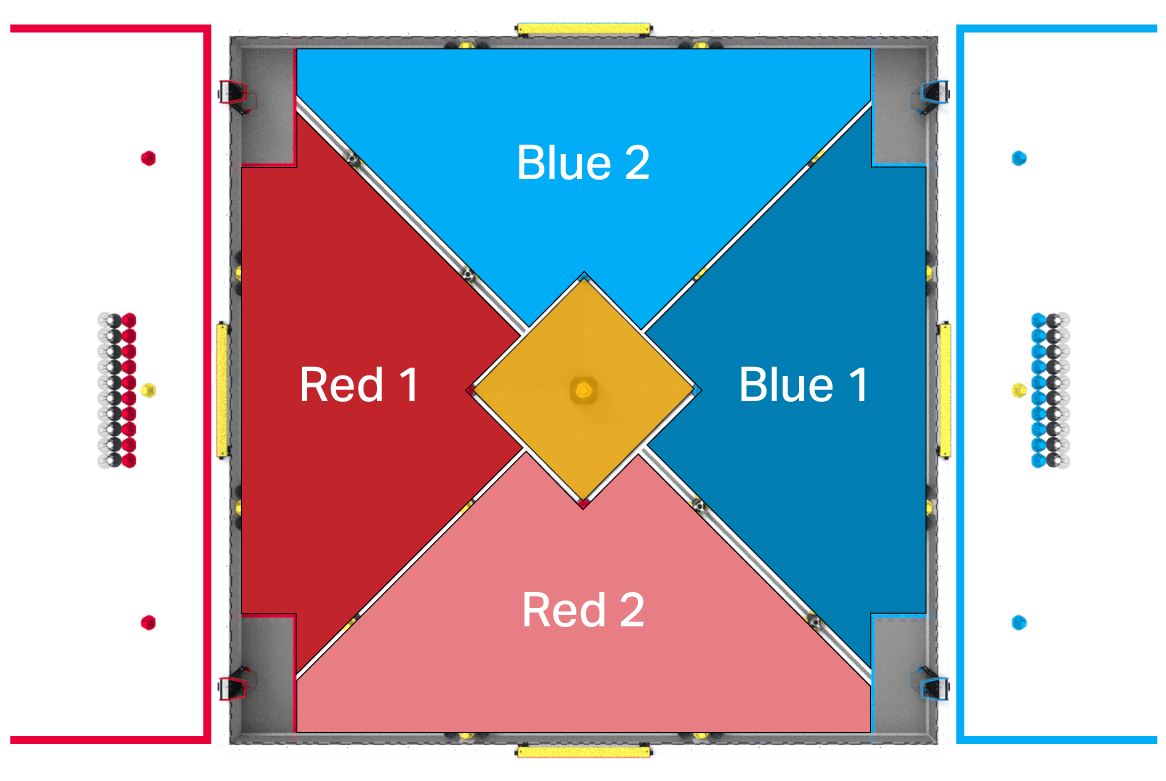
Practice Match - see Match. Preload - The Pins, one (1) per Robot, placed by each Team prior to the start of each Match. See SG5. Quadrant - One of four designated triangular areas of the Field. Each Quadrant contains two Goals and one Toggle. Robots may score Pins in the Goals within a Quadrant and may attempt to set that Quadrant’s Toggle to control ownership of yellow Pins Scored in that Quadrant. A Quadrant is defined by the outer edges of the white tape lines, the Field Perimeter, and the colored tape that defines the Load Zones. Each Quadrant is described as red or blue based on the Alliance-colored Goal it includes. See Figure Q-1.
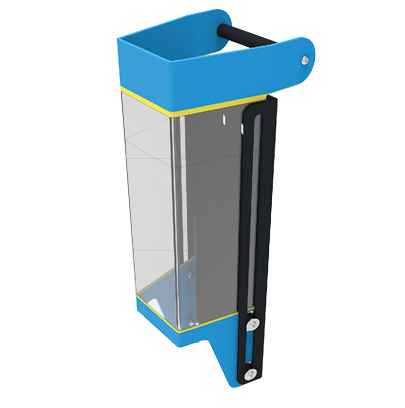
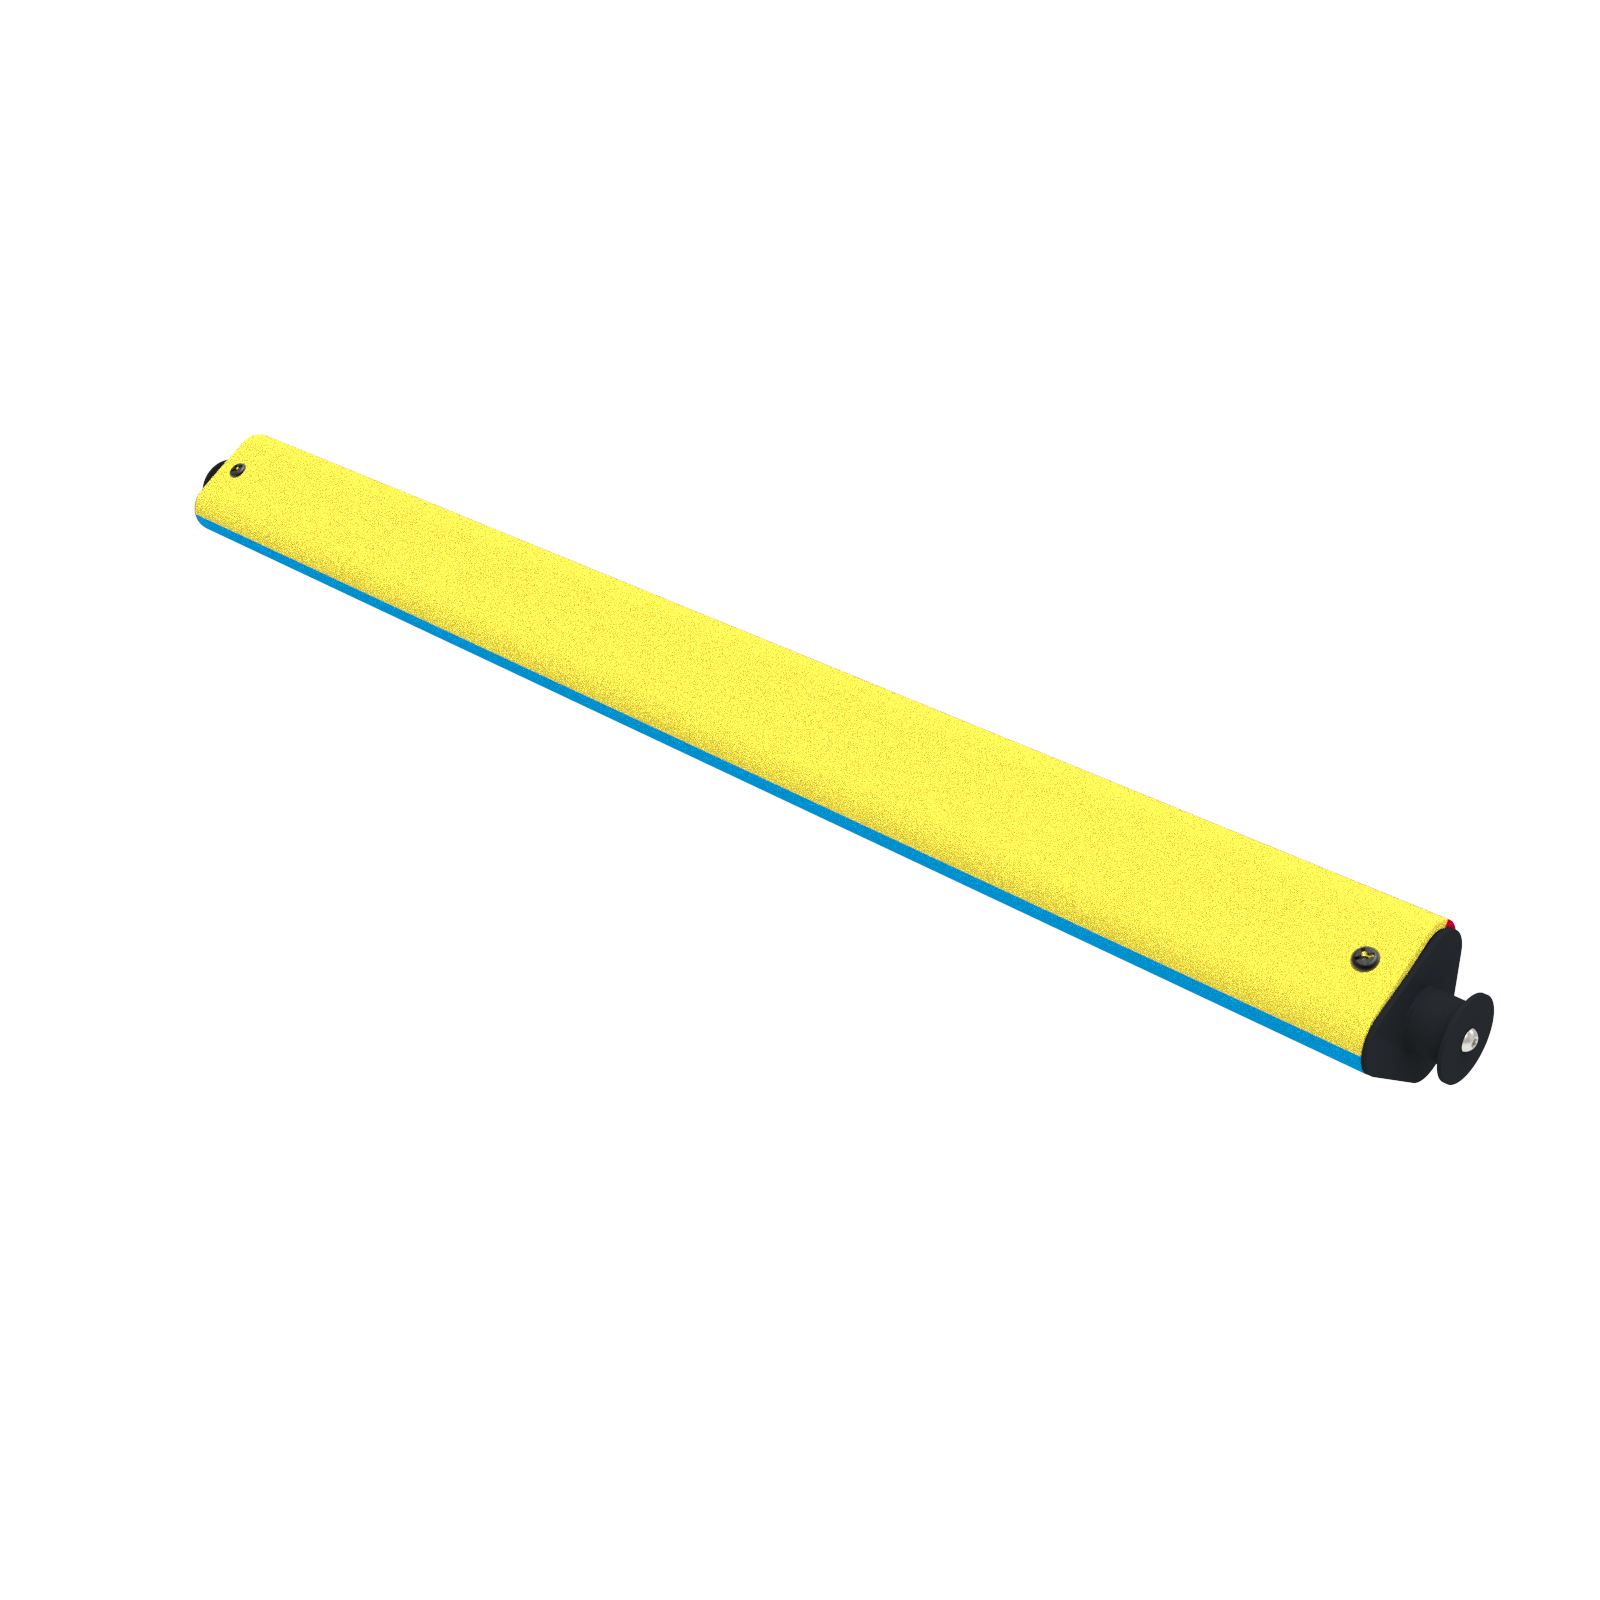
Figure Q-1: An overhead view of the Override Field with the four Quadrants (red and blue) and Midfield (yellow) highlighted. The Quadrant labels (Red 1, Red 2, Blue 1, and Blue 2) correspond to scoring input areas inside Tournament Manager, and are not relevant outside of the Tournament Manager software. Qualification Match - see Match. Robot - A machine that has passed inspection, designed by Student Team members to execute one or more tasks autonomously and/or by remote control from a Drive Team Member. Robot Skills Match - see Match. Scoring Object - A Cup or Pin. Scored - A Scoring Object status. See SC3. Scorekeeper Referee - An impartial volunteer responsible for tallying scores at the end of a Match. Scorekeeper Referees do not make ruling interpretations, and should redirect any Team questions regarding rules or scores to a Head Referee. Skills Stop Time - The time remaining in a Robot Skills Match when a Team ends the Match early. See RSC5 for more details. Strategist - Any Student Team member who contributes to the Match strategies used to score points during a Qualification Match or Robot Skills Match, including assessing the impact of other Teams’ performance and strategies on the Team’s strategy (e.g., scouting). Adults are permitted to teach Strategists associated concepts, but should never create or dictate a Team’s Match strategy. Strength of Schedule Points (SP) - The third basis of ranking Teams. Strength of Schedule Points are equivalent to the score of the losing Alliance in a Qualification Match. In the event of a tie, both Alliances receive Strength of Schedule Points equal to the tie score. If both Teams on an Alliance are Disqualified, the Teams on the not Disqualified Alliance will receive their own score as Strength of Schedule Points for that Match. Student - A person that meets the Student Eligibility Policy requirements for their respective competition program and level. Team - One or more Students make up a Team. In the context of this game manual, Student Team members fill multiple roles related to Robot design, build, coding, strategy, and documentation. See G2, G4, G5 for more information. Adults may not fulfill any of these roles. See Appendix D for more information about Team classifications and Student roles. Time-out - A single break period no greater than three minutes (3:00) allotted for each Alliance during the Elimination Bracket. See GG7. Toggle - One of four (4) triangular shaped Field Elements mounted to the Field Perimeter that can be Owned to control yellow Pins Scored in the corresponding Quadrant. Each Toggle has 3 sides that, when viewed from inside the Field, indicate which Alliance Owns the Toggle. Toggles are 25.8” (656.2mm) long and each face of the triangle is approximately 2.05” (52.2mm) wide. See SC4 for more information.
Figure T-1: A Toggle Tournament - A competition event that includes scored Matches, and which is run by an Event Partner. Violation - The act of breaking a rule in the game manual. See Appendix C for additional information on Violations and penalties.
Win Percentage (WP) - Replaces Win Points in a league event. Win Percentage is calculated by the number of wins divided by the number of Qualification Matches the Team plays. In cases of a tie, the Team is given a 0.5 number of “wins” for that Match. The Autonomous Win Point is also considered 0.5 “wins,” added to the total number of wins. Win Points (WP) - The first basis of ranking Teams. Teams will receive zero (0), one (1), two (2), or three (3) Win Points for each Qualification Match. Unless a Team is Disqualified, both Teams on an Alliance always earn the same number of Win Points.
|


↑ ↓ to move · Enter to open · Esc to close