Updated R23a to allow anodizing, painting, dyeing, or otherwise changing the color of any legal VEX parts (other than for official events held in mainland China)
Updated T6 to add white tape in place of blue/red tape for Load Zones as a permissible Field modification
The VEX V5 Robotics Competition Game Manual is the most authoritative source of information for the VEX V5 Robotics Competition. Contained within this document are all of the rules, boundaries, constraints, and other relevant information you will need to properly understand and play this year’s game.
This manual is:
A technical reference document for gameplay, Robot construction, and event operation
A binding set of rules for Teams, coaches, referees, Event Partners, and all other volunteers and participants to adhere to
The primary source of truth for all things related to the VEX V5 Robotics Competition
The rules in this game manual are intended to work together to create a system of constraints. These rules are not intended to be understood independently of one another or in isolation from other information contained in this document. Many situations may require Teams, referees, or other volunteers to use logic from multiple places in the manual to properly form an interpretation. It is critical that the entire manual is read and understood, not just parts.
Information in the game manual is presented in the following ways:
Definitions in Appendix B establish the meaning of a term with regards to this document. Sometimes, these definitions may not perfectly match a more commonly accepted dictionary definition. In that case, the VEX definition takes precedence. If there is no VEX definition for a term, it can be reasonably assumed that a dictionary definition can be used.
General Rules establish the baseline rules for competition that Teams must adhere to at all times. These include, but are not limited to, conduct at an event, roster eligibility, competition integrity, and authority and enforcement.
General Game Rules begin to outline the rules that Teams must follow in every VEX game, not just the rules specific to this season’s game. Many of these rules do not change from year to year, and help prevent the game from devolving into immediate chaos.
Scoring Rules define how points are earned and evaluated.
Specific Game Rules describe what Robots and Drive Team Members may and may not do during a Match, specifically for this season’s game. These rules are subject to change from year to year, depending on how the game is designed and meant to be played.
Robot Rules define how Robots may be built and configured.
Tournament Rules describe how competitions are run, and how Teams are ranked at events.
Some rules also reference Violation Notes that are located in Appendix C. These notes provide additional guidance on enforcement, escalation, or special circumstances. If a rule doesn’t include a cross-reference to Violation Notes, standard Violation definitions apply. See Appendix C for information about rule Violations and penalties.
This manual will have a series of “major” and “minor” updates over the course of the season. Each version is official and must be used in official VEX V5 events until the release of the next version, upon which the previous version becomes void.
Minor typographical errors or formatting issues found in the initial release, with very few rule changes expected
July 2, 2026
July 9, 2026
Version 1.0
May include gameplay or rule changes inspired by input from the official Q&A system and the VEX community
August 6, 2026
August 13, 2026
Version 1.1
Clarification / minor update
September 3, 2026
September 10, 2026
Version 2.0
May include gameplay or rule changes inspired by early-season events
October 8, 2026
October 15, 2026
Version 2.1
Clarification / minor update
December 3, 2026
December 10, 2026
Version 2.2
Clarification / minor update
January 28, 2027
February 4, 2027
Version 3.0
May include gameplay or rule changes inspired by mid-season events
March 25, 2027
April 1, 2027
Version 4.0
May include gameplay or rule changes pertaining specifically to the VEX Robotics World Championship
In addition to these known major updates, there may also be unscheduled updates released throughout the season if deemed critical by the Game Design Committee.
Any scheduled or unscheduled updates will always be released on a Thursday, no later than 5:00 PM CST (11:00 PM GMT). These updates will be announced via the VEX Forum, automatically pushed to the VEX V5 Hub app, and shared via VEX Robotics social media & email marketing channels. Once announced, the new version of the Game Manual will be immediately available at the link above.
Generally, Game Manual updates, scheduled or unscheduled, will include a grace period before the updated rules go into effect for competitions. See the release table above for specific dates. This grace period does not apply to the Version 0.1 Release, which serves as the initial rule set for the season.
Any events that begin before the 7-day grace period has ended must continue using the rules from the previous Game Manual Release. This policy ensures fairness and consistency, allowing Teams to adapt their strategies and gameplay accordingly before the changes are enforced in official competitions.
The Game Design Committee reserves the right to enforce critical updates to the Game Manual as effective immediately upon release, if we feel that the changes are critical for competitive integrity, safety, and/or other extenuating circumstances.
Multi-week league events (or similar) that cross over a grace period should use the version of the Game Manual that is in effect at the beginning of each league session. Leagues should update to new versions of the Game Manual between sessions as appropriate.
When first reviewing a new robotics game, it is natural to have questions about situations which may not be immediately clear. Navigating the Game Manual and seeking out answers to these questions is an important part of learning a new game. In many cases, the answer may just be in a different place than you first thought - or, if there is no rule explicitly prohibiting a gameplay strategy, then that usually means it is legal!
However, if a Team is still unable to find an answer to their question after closely reviewing the relevant rules, then every Team has the opportunity to ask for official rules interpretations and clarifications in the VEX Robotics Question & Answer System. These questions may be posted by a Team’sAdult representative via the events.vex.com account that is associated with that Team.
All responses in this Q&A system should be treated as official rulings from the VEX Robotics Game Design Committee, and they represent the correct and official interpretation of the VEX V5 Robotics Competition rules. The Q&A system is the only source besides the Game Manual for official rulings and clarifications, and is functionally an extension of the Game Manual. Unlike Game Manual updates, Q&A rulings are effective immediately upon release.
Before posting on the Q&A system, be sure to review the Q&A Usage Guidelines:
If there are any conflicts between the English-language PDF of the Game Manual and other supplemental or translated materials (e.g., referee training materials, the VEX V5 Hub app, the game reveal video, a translated game manual, etc.), the most current version of the English-language PDF of the Game Manual takes precedence.
Similarly, it can never be assumed that definitions, rules, or other materials from previous seasons apply to the current game. Q&A responses from previous seasons are not considered official rulings for the current game. Any relevant clarifications that are needed should always be re-asked in the current season’s Q&A.
This Game Manual is the authoritative source for all gameplay, Robot, and event rules. For these matters, official information ranks as follows:
The current version of this Game Manual, including all published updates
The official Q&A system
Other VEX Robotics or Global Robotics and Science Foundation supplementary documents and training materials
Q&A answers are official rulings, effective when posted. An answer that conflicts with this Manual takes precedence until a Manual update addresses it. Answers not addressed by an update remain in effect.
The following companion documents are authoritative within their own scopes and take precedence over any summary or restatement of their content in this Manual:
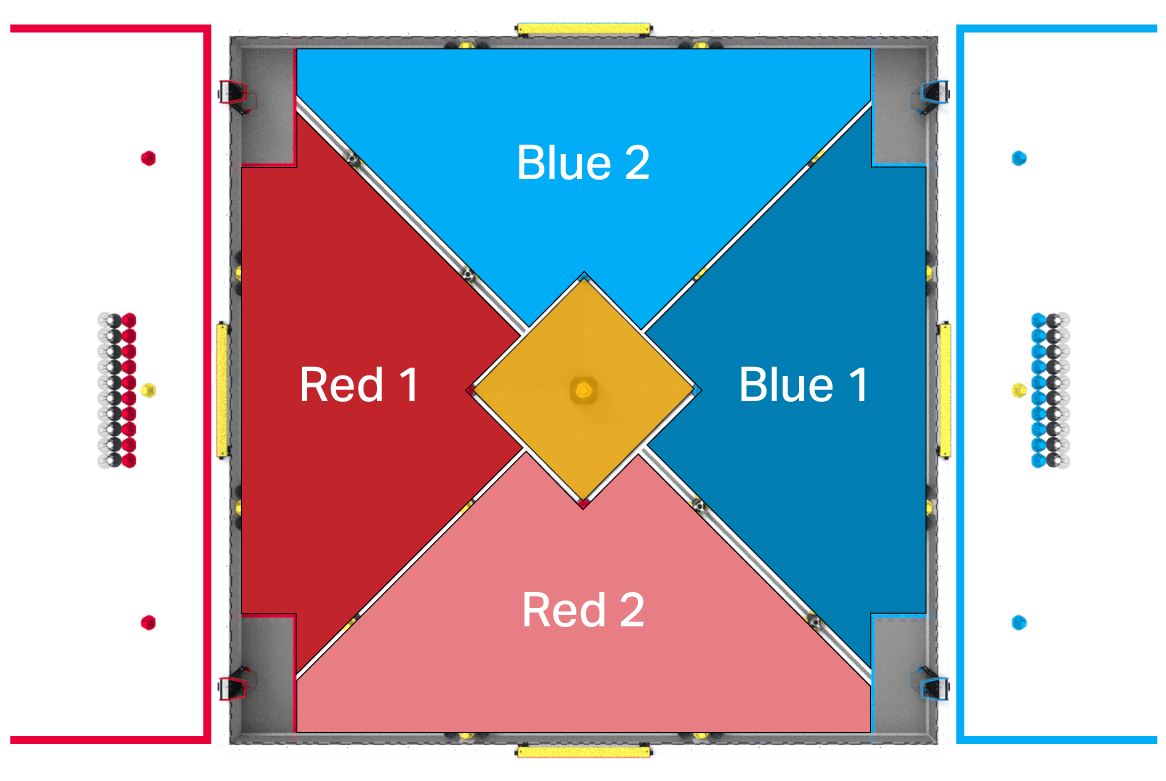
The object of the game is to attain a higher score than the opposing Alliance by stacking Pins and Cups on Goals, setting Toggles to your Alliance color, and ending the Match with your Robot in the contested Midfield.
Teams may also compete in Robot Skills Matches, where one (1) Robot tries to score as many points as possible. See Section 3 for more information.
At the VEX U Collegiate level, Teams play in a modified Tournament with a 30-second Autonomous Period and additional Robot build challenges. See Section 6.
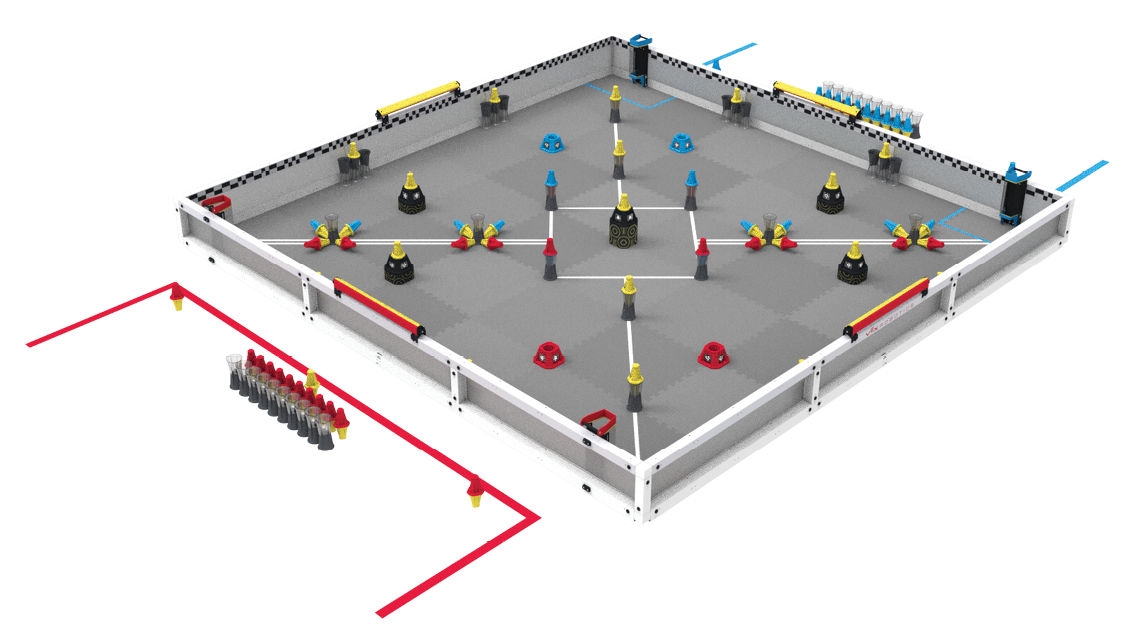
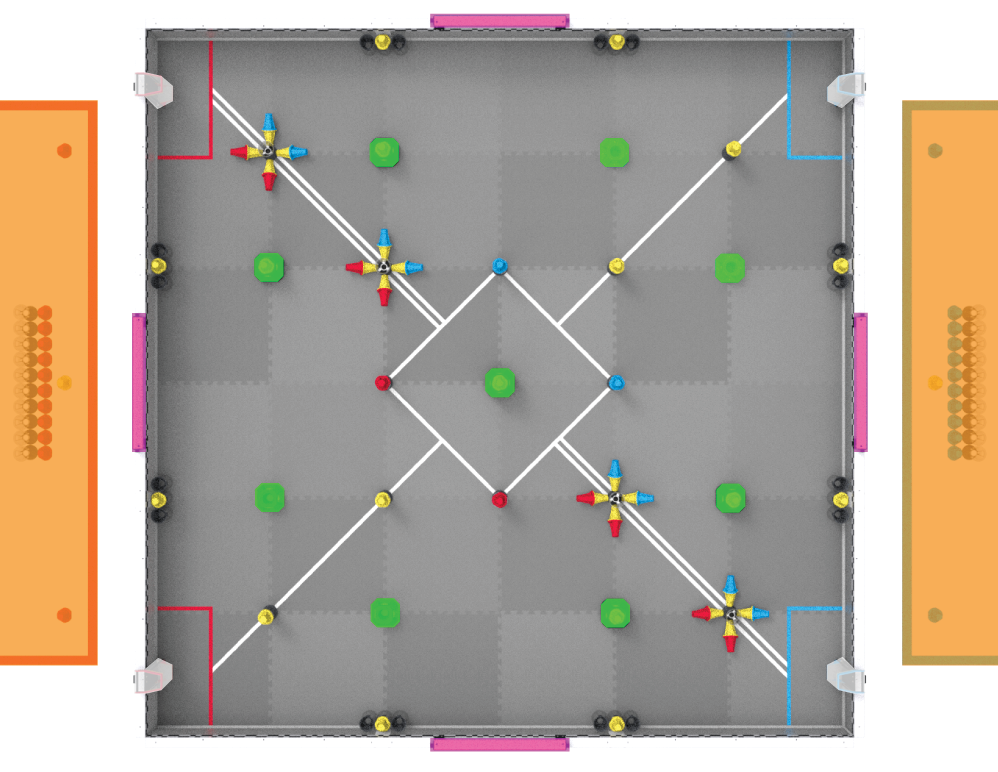
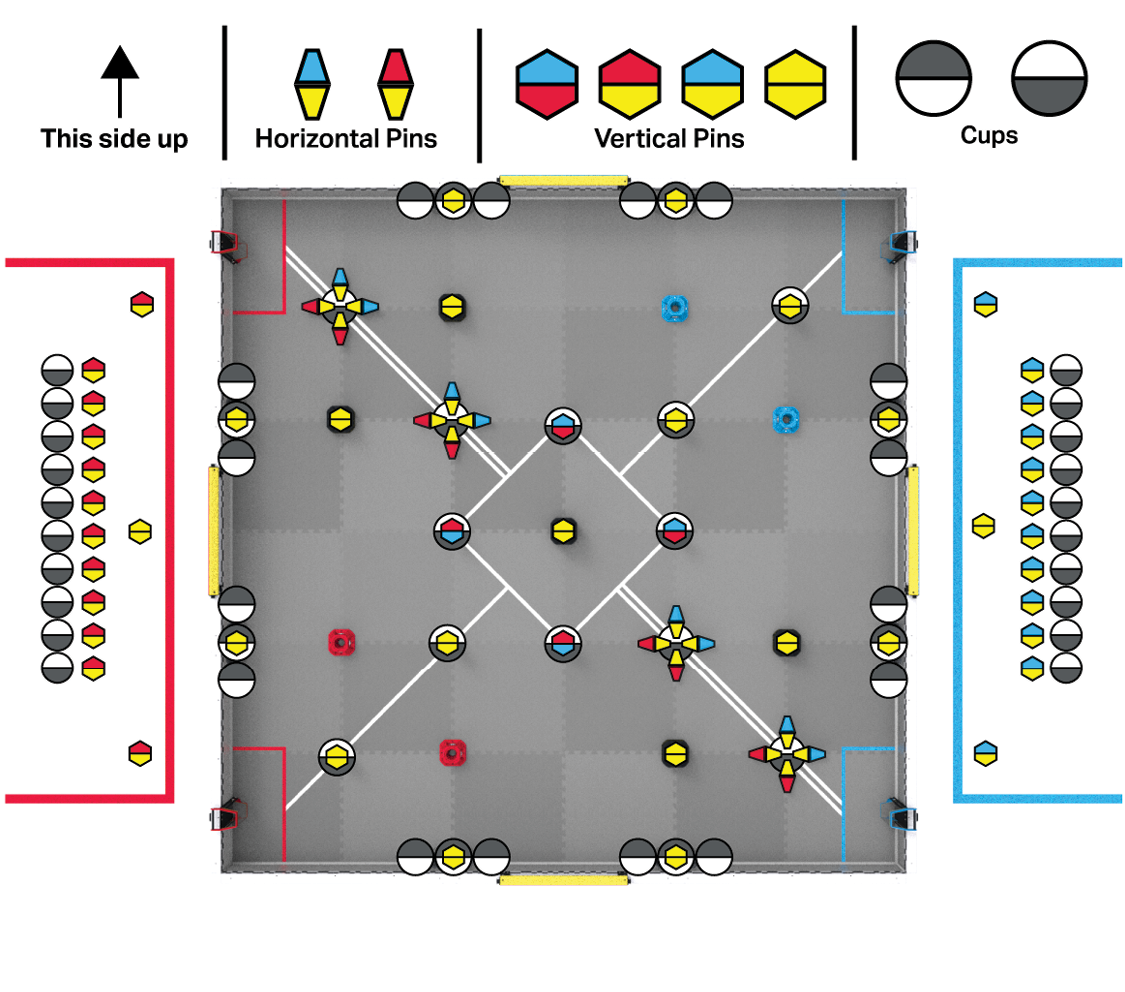
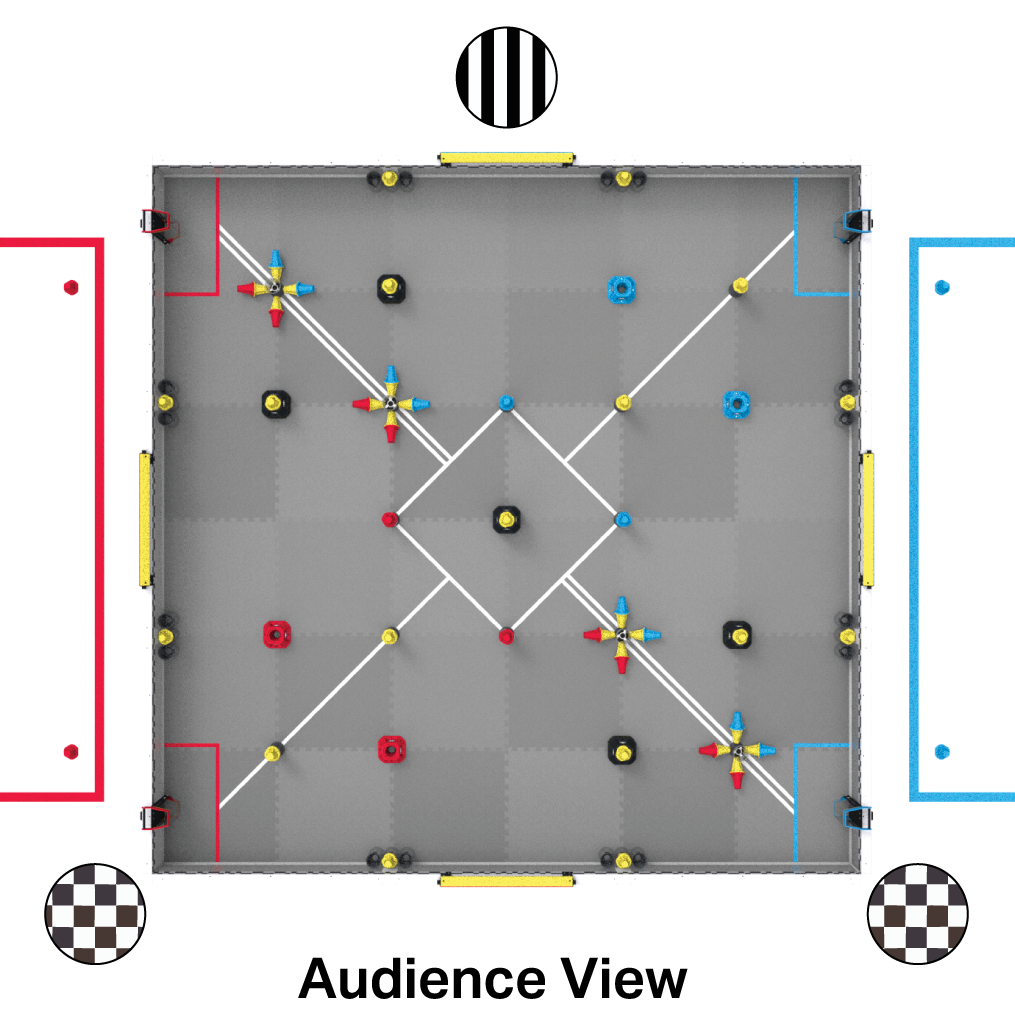
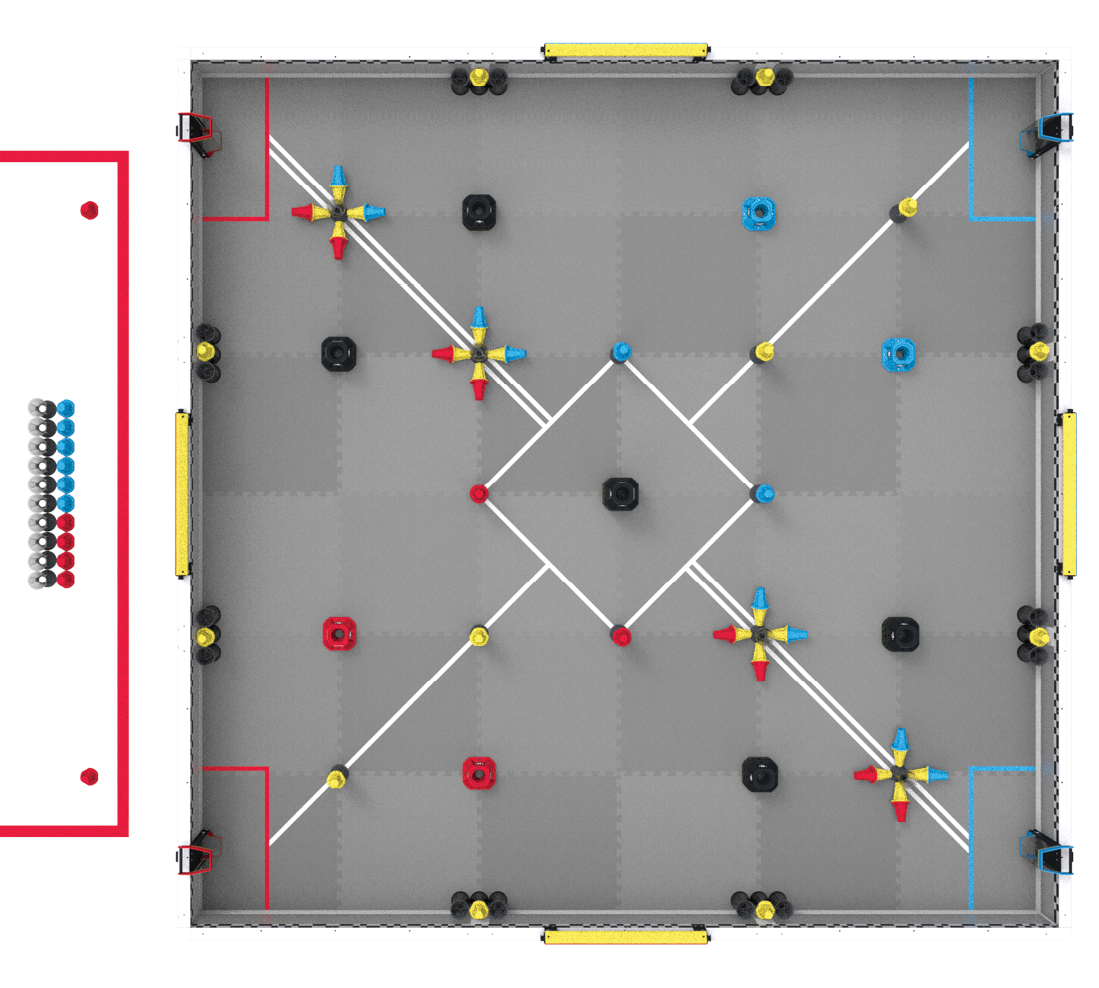
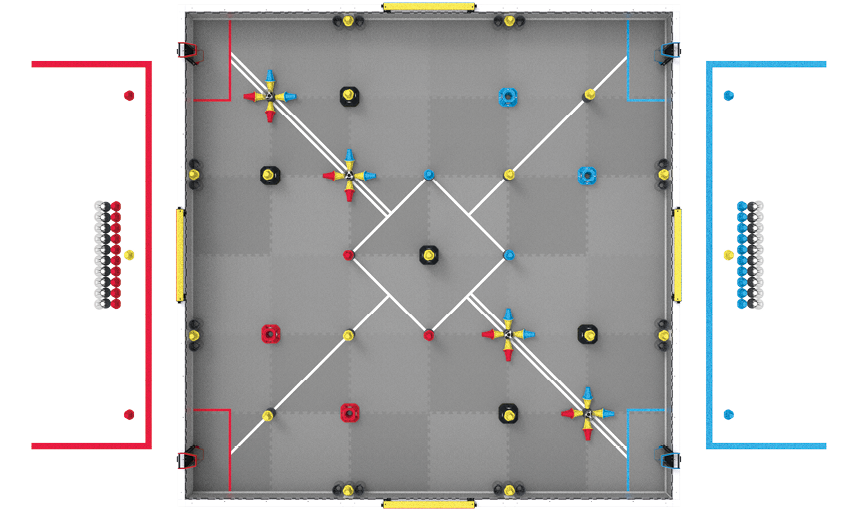
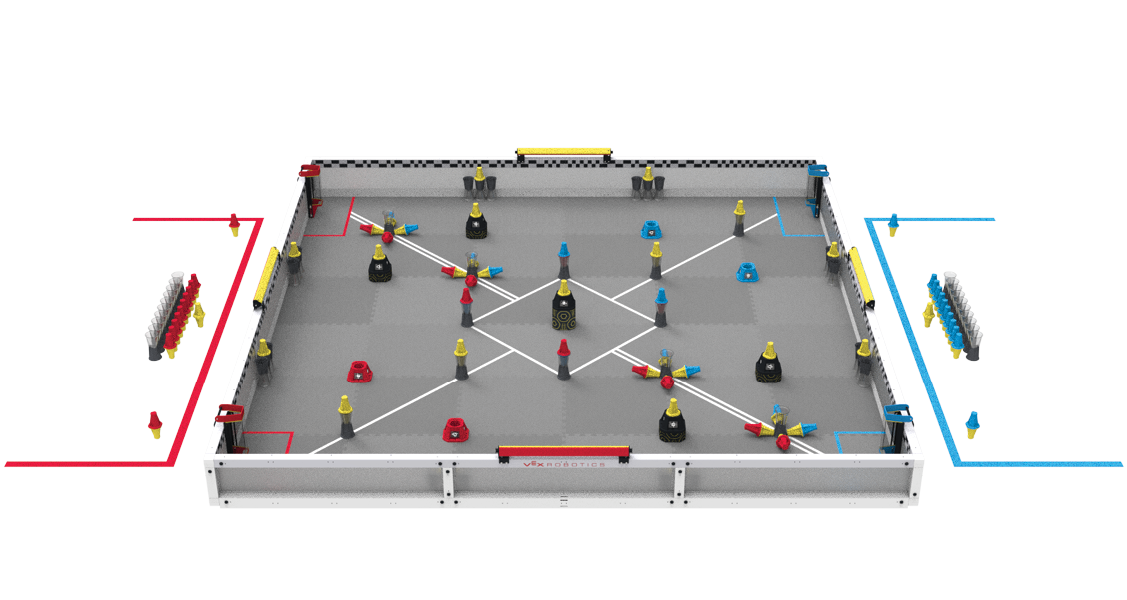
Note: The illustrations in this section of the Game Manual are intended to provide a general visual understanding of the game. Some figures may highlight or change the appearance of certain Field Elements and Scoring Objects to emphasize or clarify intent.
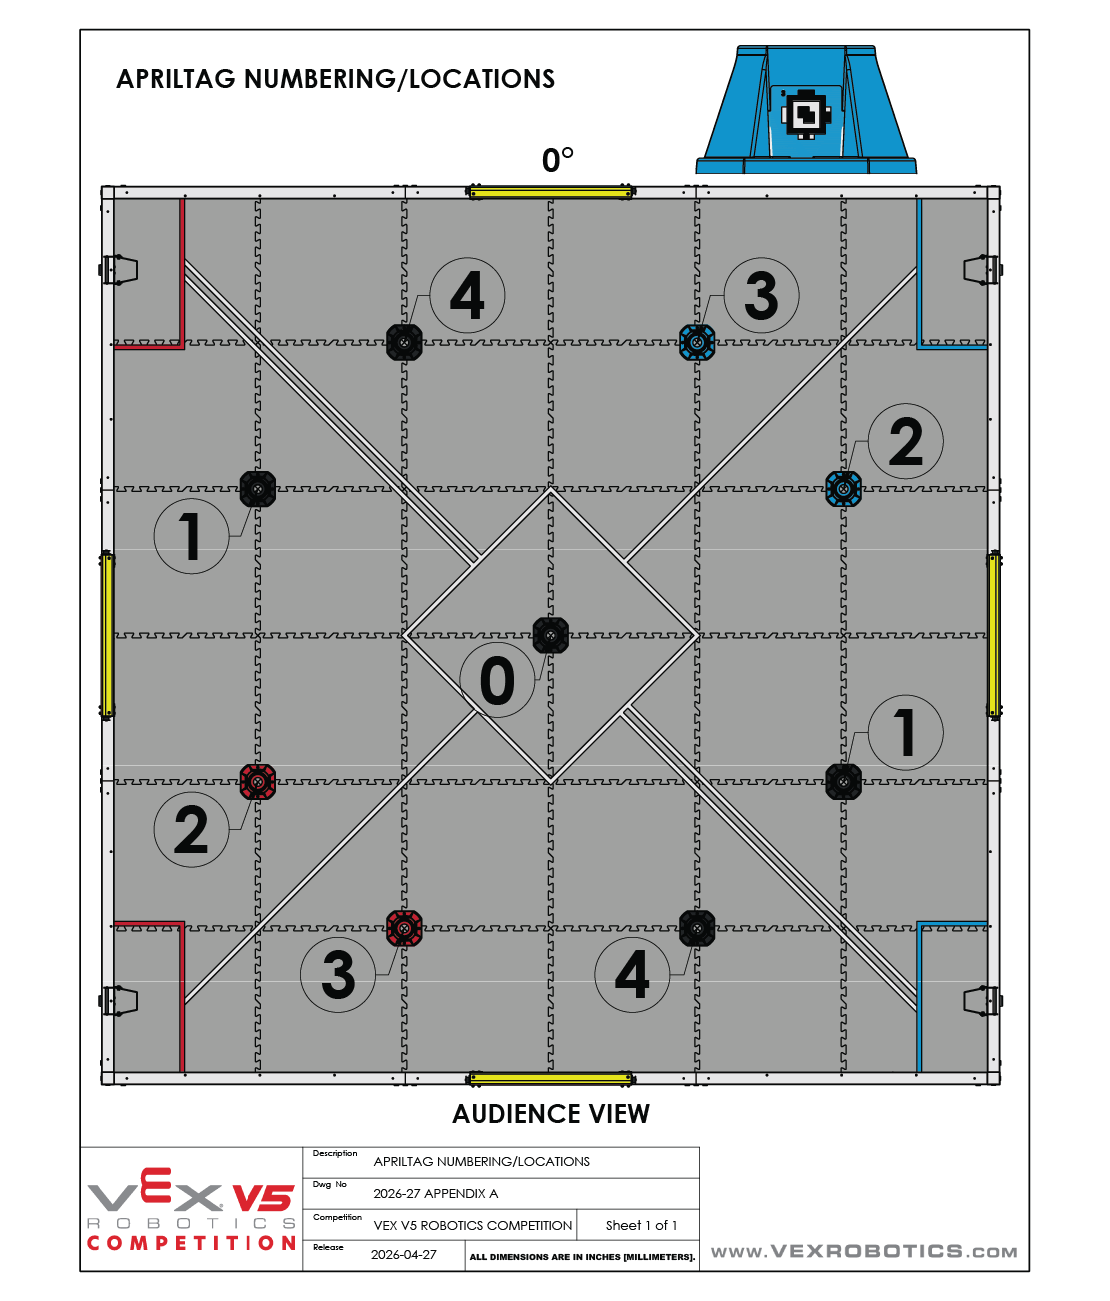
Teams should refer to official Field specifications, found in Appendix A, for exact Field dimensions, a full Field bill of materials, and exact details of Field construction.
We want to take the opportunity to explain how this game was designed and what kind of gameplay we expect to see during the season. This section also points out parts of the game that we will watch closely in case updates are needed.
This is not a rules section. It does not add any new rules. Instead, it helps you understand the purpose of the game and what we as designers had in mind.
What This Game is About & Scoring
Override is a game that focuses on stacking and teamwork. We intend for Teams to work together with their Alliance partners to assemble stacks, gain points using Scoring Objects, and control Toggles to outscore their opponents.
Because of this, success in the game is not just about building a good Robot. It also depends on how well you:
Interaction with the opposing Alliance is still an important part of the game. However, Matches cannot be dominated by tearing down what the other Alliance has built. Some defense and disruption is expected, but the main focus should stay on building and scoring.
If strategies that focus mostly on preventing stacks become too common, the Game Design Committee may consider making changes to ensure the game remains interesting with many strategy choices. We will look at how often these strategies are used and how they affect gameplay compared to our intentions.
Large Point Swings with Toggles and Yellow Pins
The scoring values in Override are designed to encourage dynamic strategy and decision making. Because of this, it is possible for actions like controlling Toggles or scoring yellow Pins to create large point swings during a Match.
These moments can be exciting, but they should not become the only way to win. Teams should still have multiple viable strategies, including building stacks and competing in the Endgame.
We will monitor how these point swings impact Matches throughout the season. If they begin to outweigh other scoring opportunities or reduce strategic variety, the Game Design Committee may adjust point values to maintain a balanced and engaging game.
The Endgame: Final 10 Seconds
The last 10 seconds of the Match are designed to feel more intense and competitive. During this time, the game shifts to a “king of the hill” style challenge in the Midfield. This section of the Match will likely include increased Robot interaction. As such:
Teams should expect more crowded and contested conditions than earlier in the Match.
If the Endgame consistently leads to problems like Robots getting stuck, tipping too often, or not being able to recover, the Game Design Committee may adjust rules to keep Matches fair and playable.
Using Sensors in the Game
Override is a game where sensors can be very helpful. Tools like AI Vision Sensors and Optical Sensors can help your Robot :
The Game Design Committee will work to support sensor use through Field and game design. However, real-world conditions are not always perfect. Lighting and object placement may vary. Because of this, Teams should design and code their Robots so their sensors can handle small changes and still work reliably during a Match.
In addition, Robot rules will continue to be reviewed to make sure the game stays fair throughout the season. One important focus is preventing Teams from building Robots that could interfere with sensors in unfair ways like intentionally trying to confuse sensors or adding parts that look like Field Elements.
Making sure all Teams can rely on their sensors to work as expected is an important part of fair competition.
<SC1>All scoring statuses are evaluated after the Match ends. Scores are calculated five seconds after the Match ends, or once all Scoring Objects, Field Elements, and Robots on the Field come to rest, whichever comes first.
This 5-second delay is intended to be the only permitted “benefit of the doubt” for last-second scoring actions. If an object or Robot is still in motion and “too close to call” between two states at the 5-second mark, then the less advantageous of the two states should be awarded to the Robot (s) in question. A Robot which is breaking the plane of the Midfield but slowly droops down and away from the Midfield at five (5) seconds would not be considered in the Midfield.
At the end of the Match, the on-screen timer displayed by Tournament Manager will hold the current Match information and “0:00” for five (5) seconds before moving to queue the next Match. This should be the primary 5-second visual cue used by Teams and Head Referees.
This 5-second delay is only intended to be a “benefit of the doubt” grace period, not an extra five seconds of Match time. Robots which are designed to strategically exploit this grace period will receive a Minor Violation, and any post-Match movement will not be included in score calculation (i.e., the Match will be scored as it was at 0:00).
Referees should avoid contacting or moving Robots and/or Scoring Objects as much as possible while evaluating scoring statuses. If an object must be moved to evaluate the status of another object, its status must be agreed upon by all Teams and the Head Referee, and noted or recorded, before it is moved.
Referees must record counts based on verified scoring statuses evaluated after the Match, using final positions of Scoring Objects, Field Elements, and Robots. Point considerations used to determine whether a Violation is Match Affecting (e.g., specified in Violation Notes) should NOT be added to or deducted from the actual score, and points scored during a Violation should not be deducted from a score.
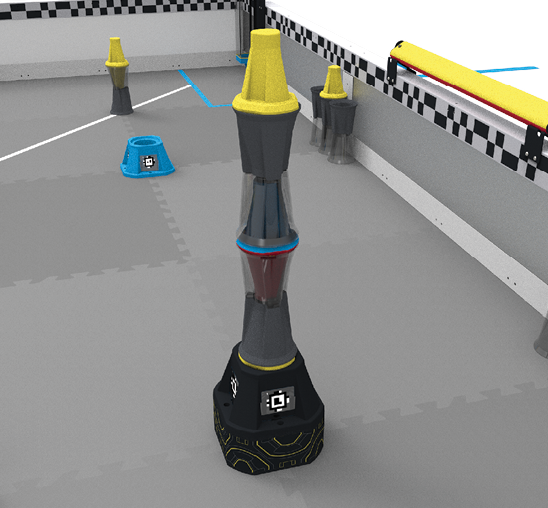
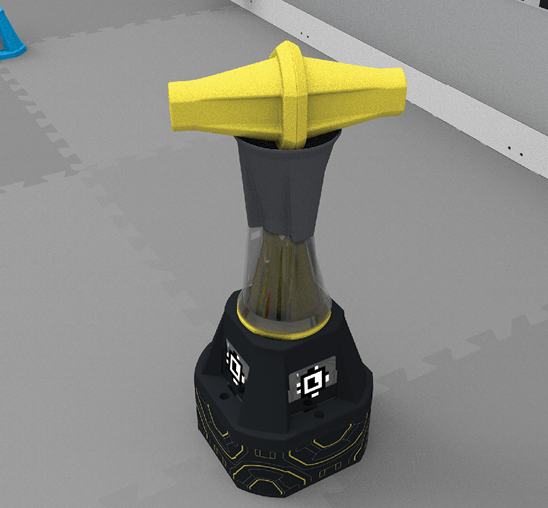
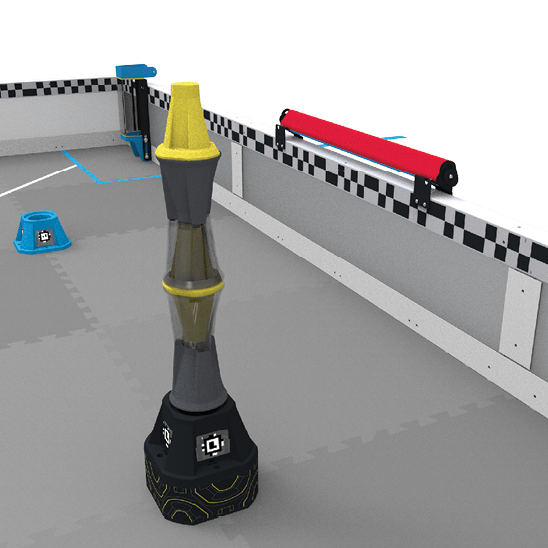
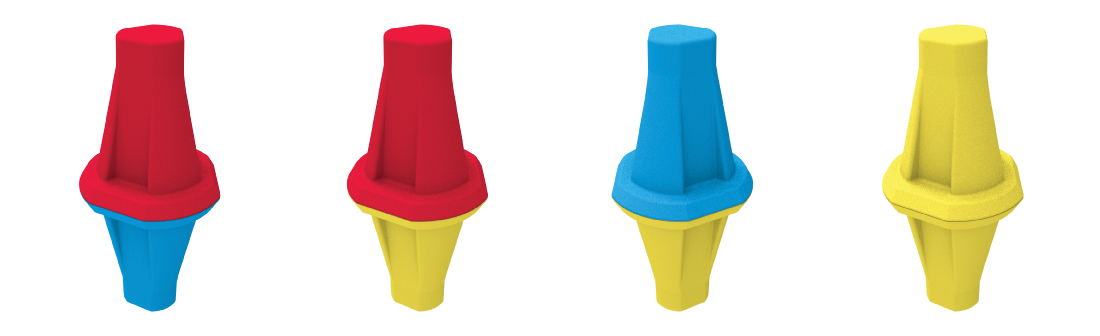
Figure SC2-2: The Pin resting on top is partially nested with the Cup, but the Pin is not considered Placed since that half of the Cup contains more than one Pin Half.
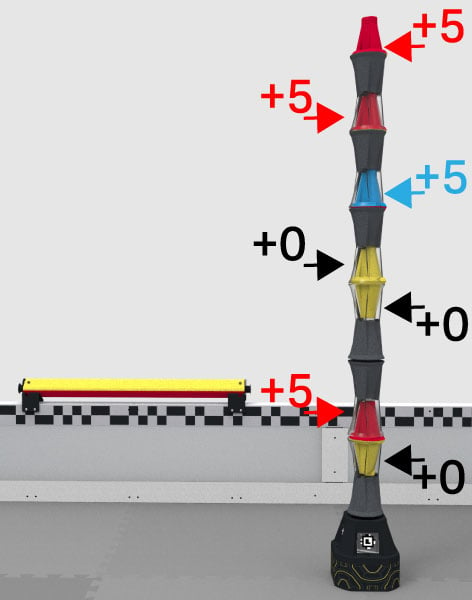
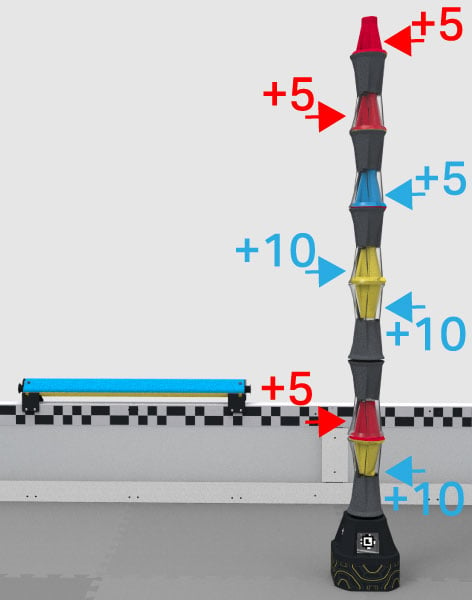
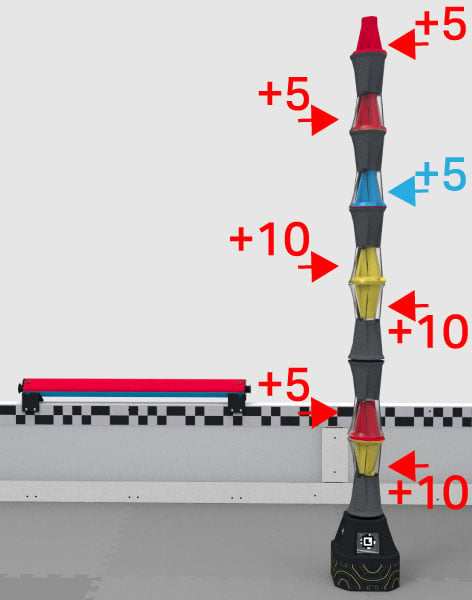
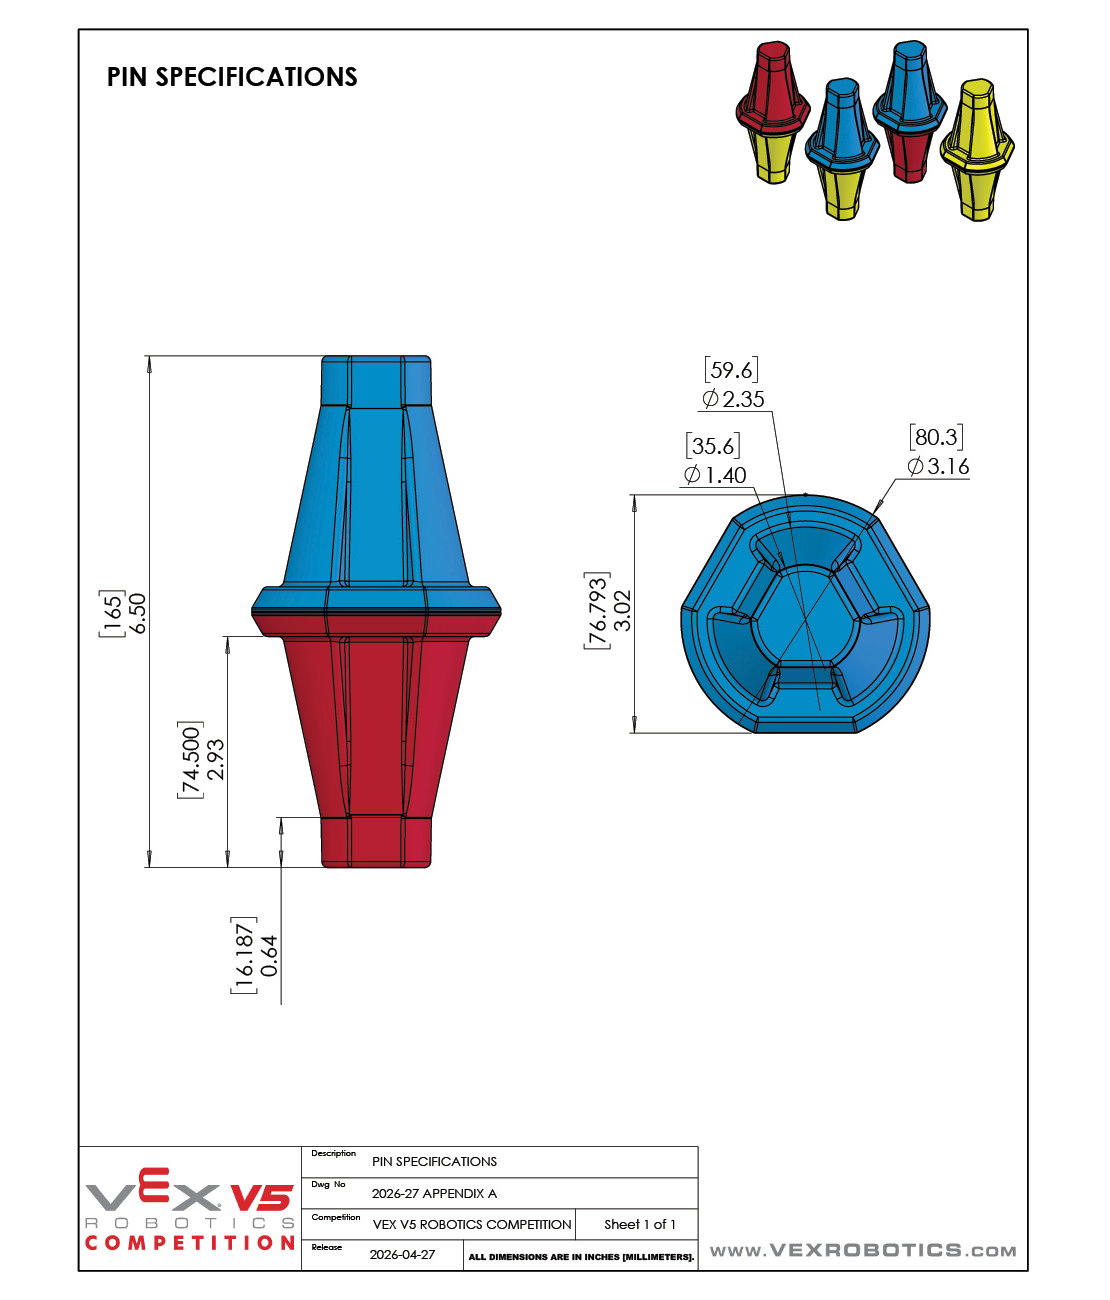
<SC3> Each Pin consists of two Pin Halves. Each visible half of a Placed Pin is Scored and earns points according to its color:
"For the purposes of Match Affecting calculations, the removal of Placed Scoring Objects from neutral Goals should be evaluated as follows:
2. 3. a. For an interaction resulting in the removal of 1, 2, or 3 Pins, each Pin removed as part of
this interaction should be considered worth a value of 10 points.
b. For an interaction resulting in the removal of 4+ Pins, the Pins removed as part of this
interaction should be considered worth a combined value of 50 points.
This question is the definition of "pin" in the violation note.
<SC3><SC3> "Each Pin consists of two halves. Each visible half of a Placed Pin counts as a Scored Pin, according to the following:
Each visible red half of a Placed Pin counts as a Scored red Pin, earning points for the red Alliance.
Each visible blue half of a Placed Pin counts as a Scored blue Pin, earning points for the blue Alliance.
Each visible yellow half of a Placed and Owned Pin counts as a Scored yellow Pin, earning points for the Alliance that Owns the Pin. (See <SC5><SC5>.)
For a Pin half to be considered visible, the Pinhalf must not be partially or fully nested inside the opaque half of a Cup.”
Below (image 1) is 2 (physical pins) or 3 (pin halves)?
(these are not my drawings, I borrowed them from a friend)
Currently, a whole Pin (consisting of two halves) is referred to as a "Pin", and a visible half of a Placed Pin is referred to as a "Scored Pin". We definitely understand the confusion here, and we're hoping to resolve this confusion between Pins and Pin halves in the next game manual update.
In Q&A 3232, we mentioned that when Scoring Objects were removed from neutral Goals, we felt that tracking extra details, such as which parts of Pins were visible or not, was likely too much of a burden on Head Referees that could lead to excessive guesswork. As a result, Head Referees should only count the number of whole Pins removed from the Goal for each SG10 Violation, not the number of visible Pin halves.
For example, if an SG10 Violation involved the removal of two whole Placed Pins (consisting of 4 Pin halves), that would count as 2 Pins removed, meaning this SG10 Violation would be valued at 20 points.
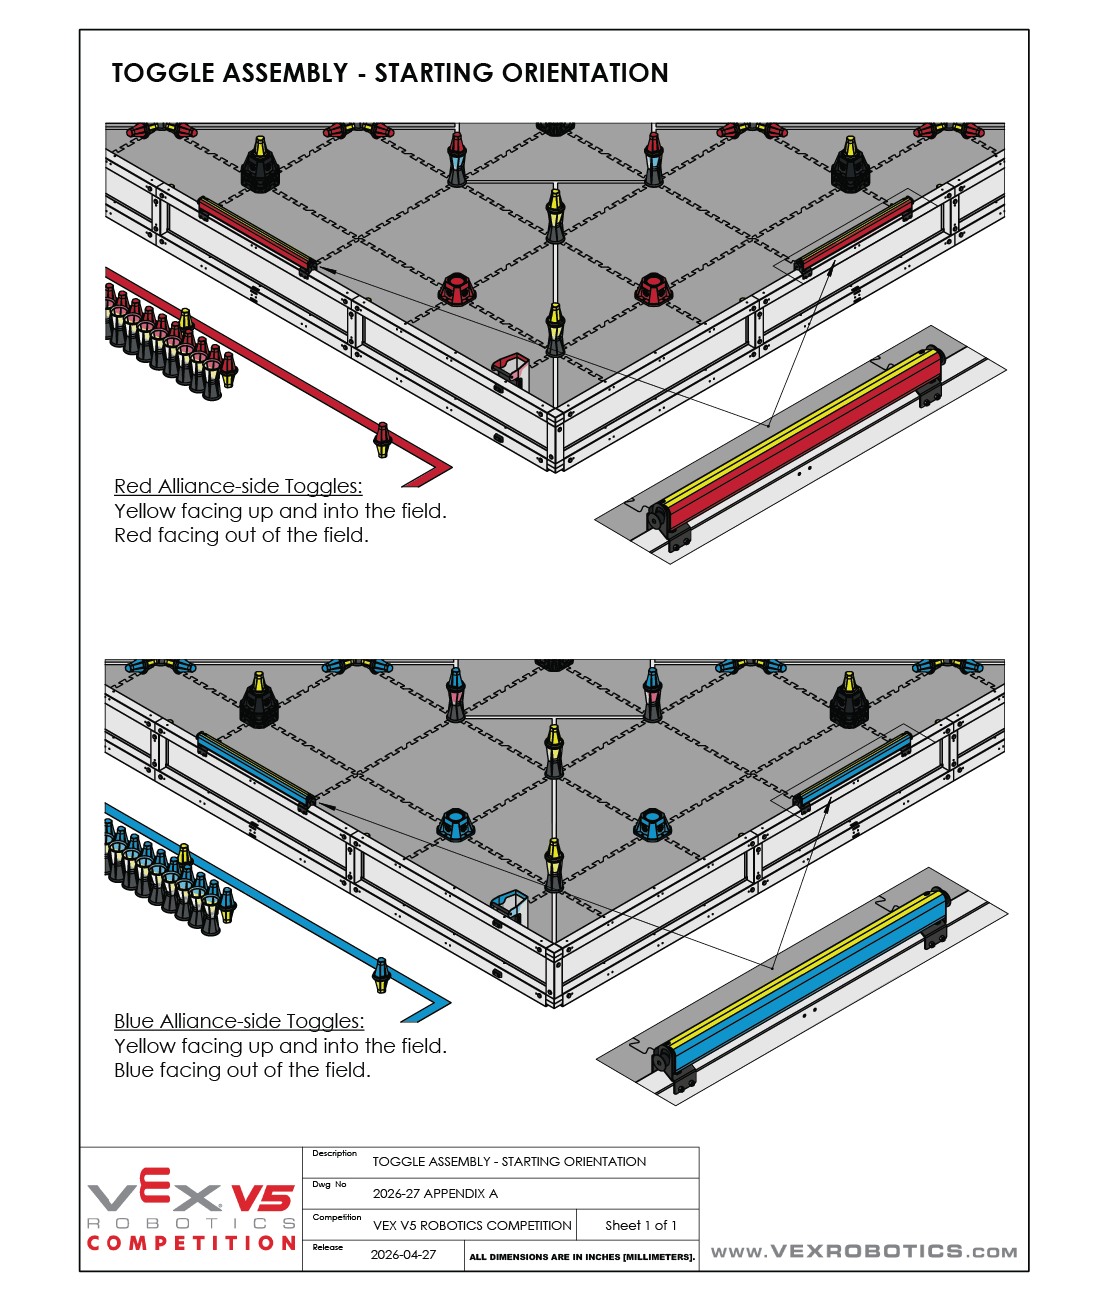
<SC4>A Toggle is considered set to a color when it meets all of the following criteria:
The Toggle must be fully seated, such that there is a face of the Toggle in contact and parallel with its mounts on the Field Perimeter at rest. (see Figure SC5-1)
If a Toggle is not considered set to a color, it is considered a neutral (yellow) Toggle by default, and neither Alliance receives Ownership of the yellow Pin Halves in that Quadrant. While the Toggle has infinite potential orientations, only three discrete orientations are considered “set” states.
<SC5>Ownership of Yellow Pin Halves. Each yellow half of a PlacedPin can be Owned by an Alliance under the following conditions:
<SC6> A Robot counts as ending in the Midfield if the Robot is at least partially within the Midfield at the end of the Match (i.e., any part of the Robot extends into the defined volume of the Midfield).
For events which qualify directly to the VEX Robotics World Championship (such as Event Region Championships and Signature Events), the following tasks must be completed for an Alliance to receive an Autonomous Win Point. The standard criteria above still apply to all other events.
Note: Using external influences, such as Preloads or the Field Perimeter, to maintain a Robot’s starting size is only acceptable if the Robot would still satisfy the constraints of R3 and pass inspection without these influences.
Violation Notes:
The Match will not begin with any conditions in this rule unmet. If a Robot cannot meet these conditions in a timely manner, the Robot will be removed from the Field and rules <R2d> and GG2 will apply until the situation is corrected. They will not receive a Disqualification, but should receive a Minor Violation and will not be permitted to play in the Match.
Clause A of this rule is applied differently for VEX U. See Rule VUG1 and VUG3.
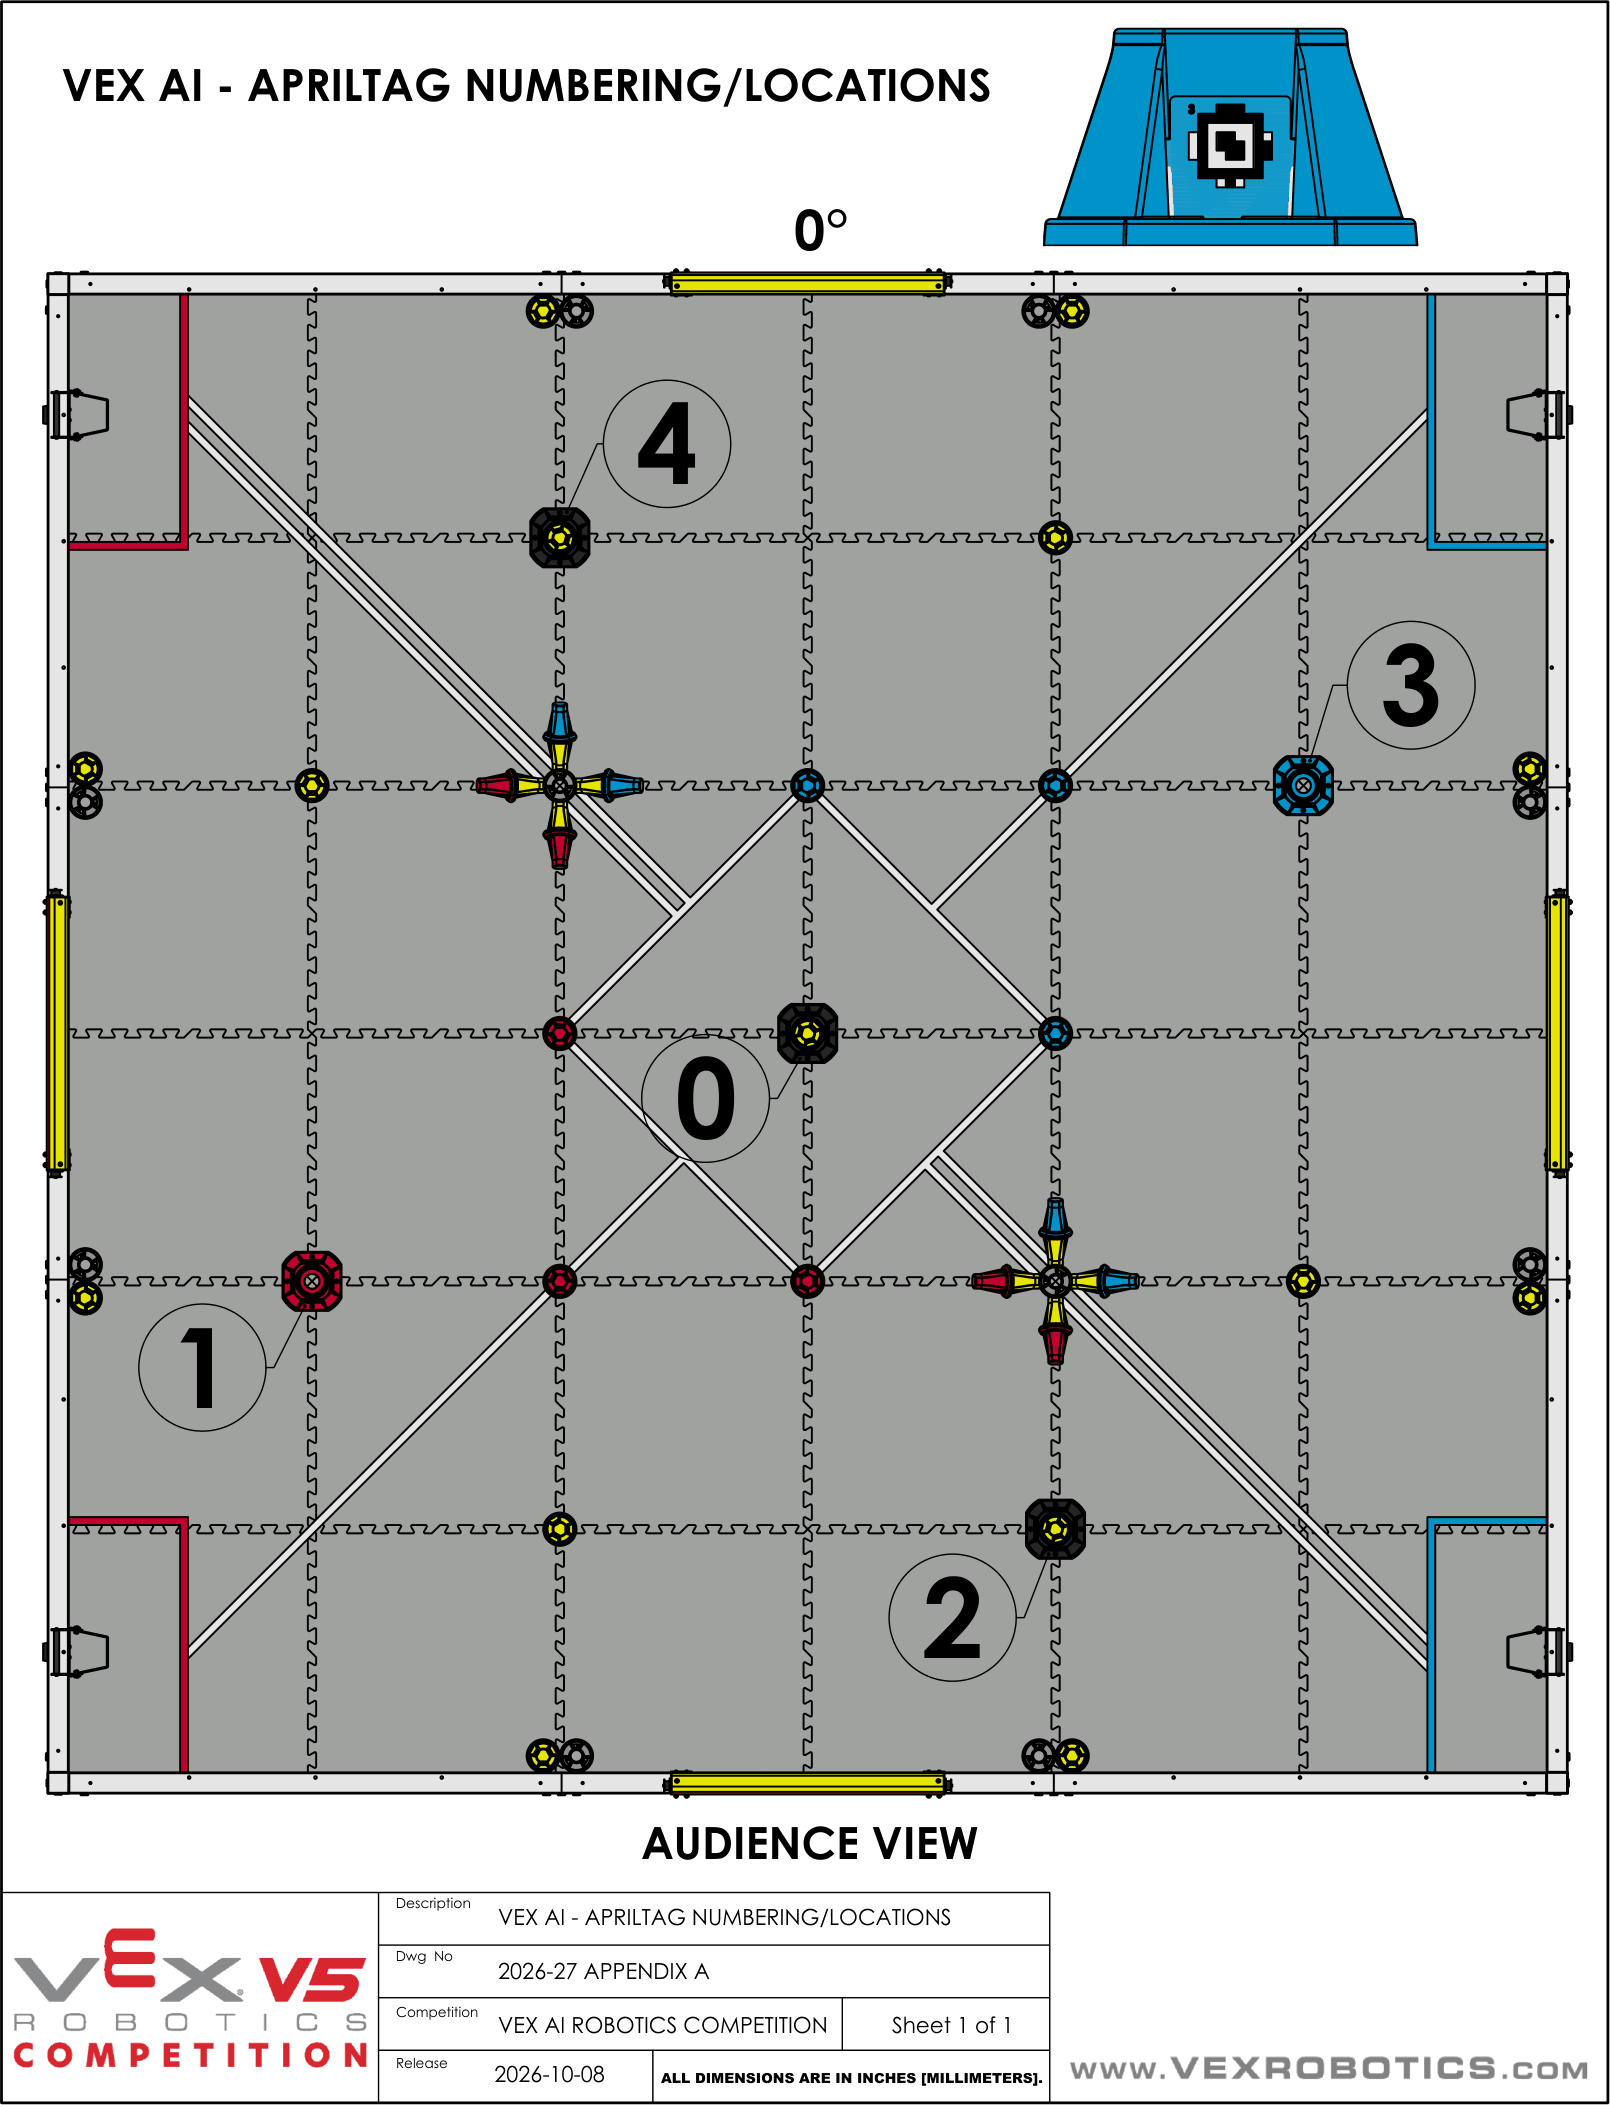
This rule is applied differently for the VEX AI Robotics Competition. See Rule VAIG4.
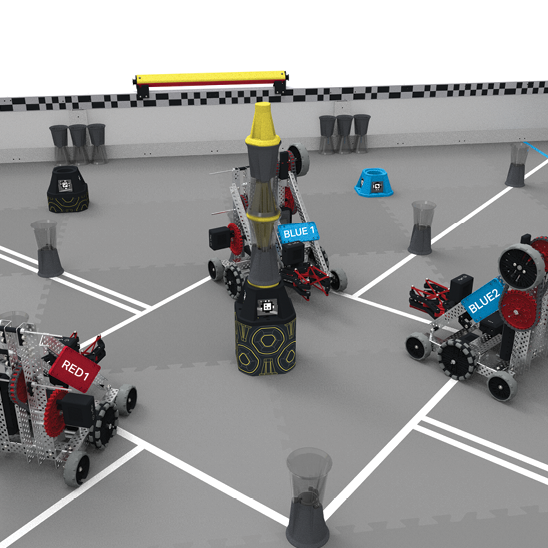
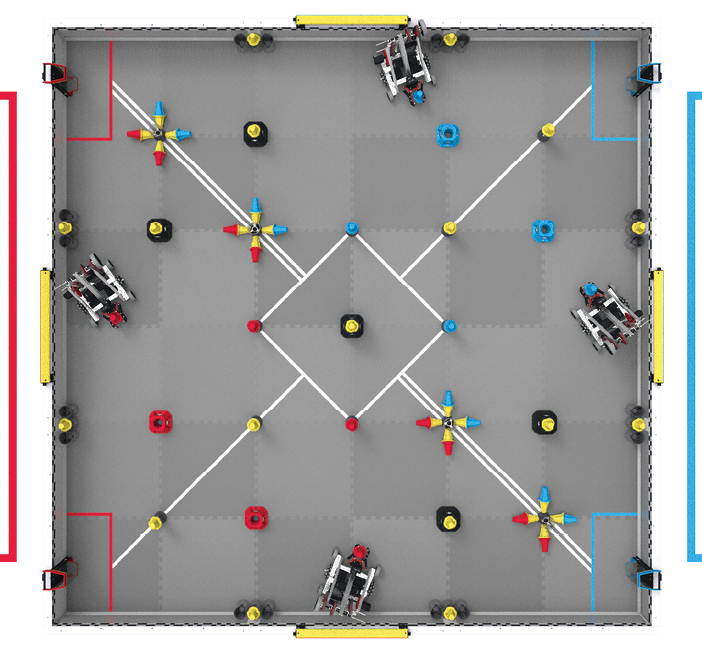
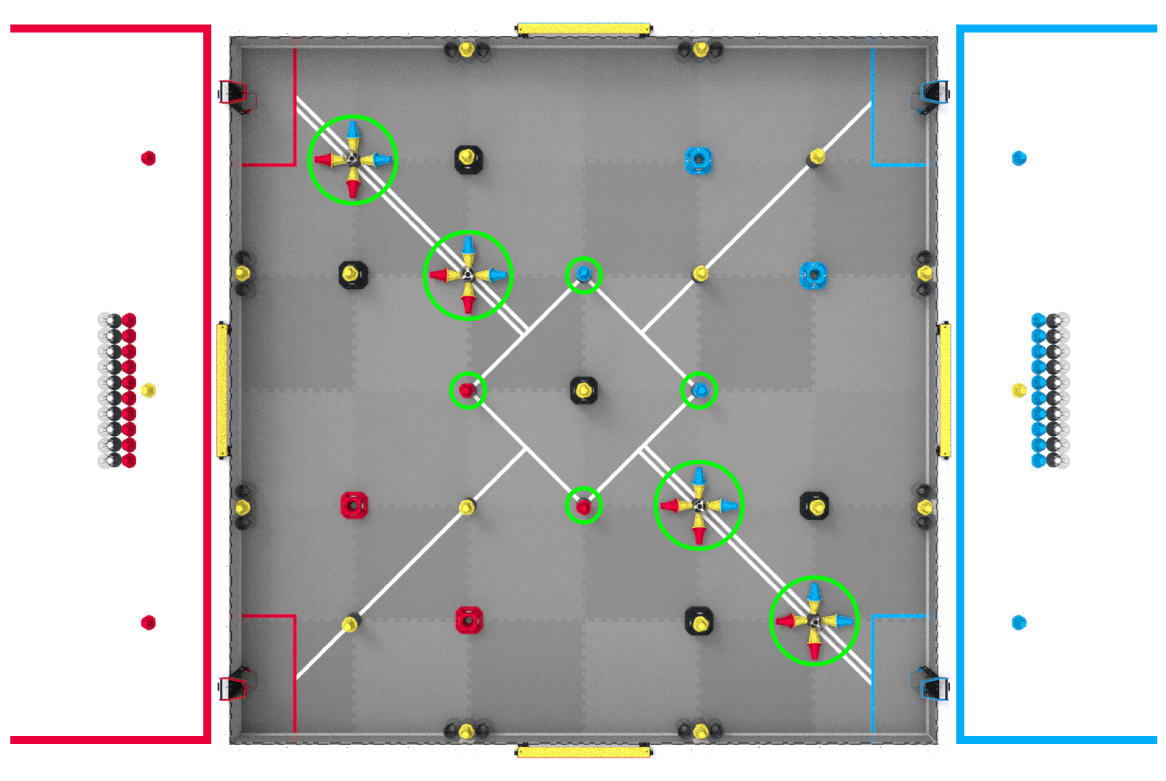
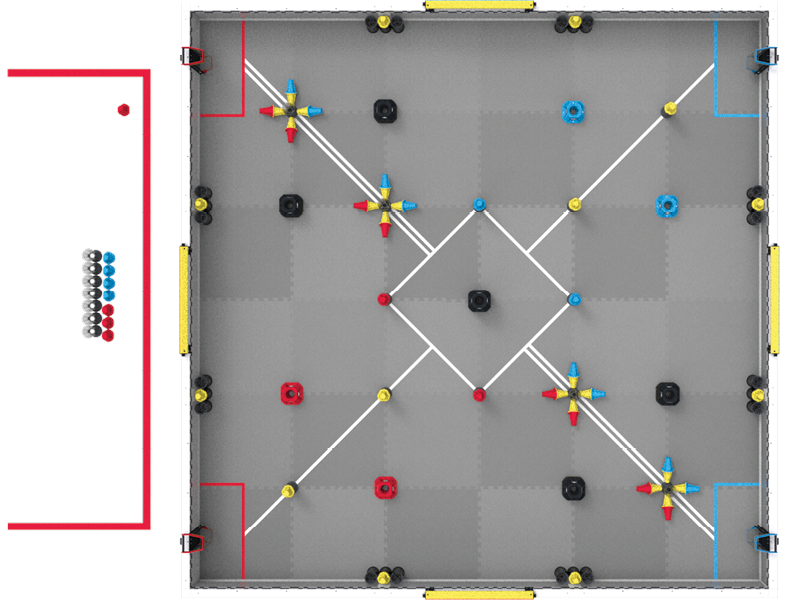
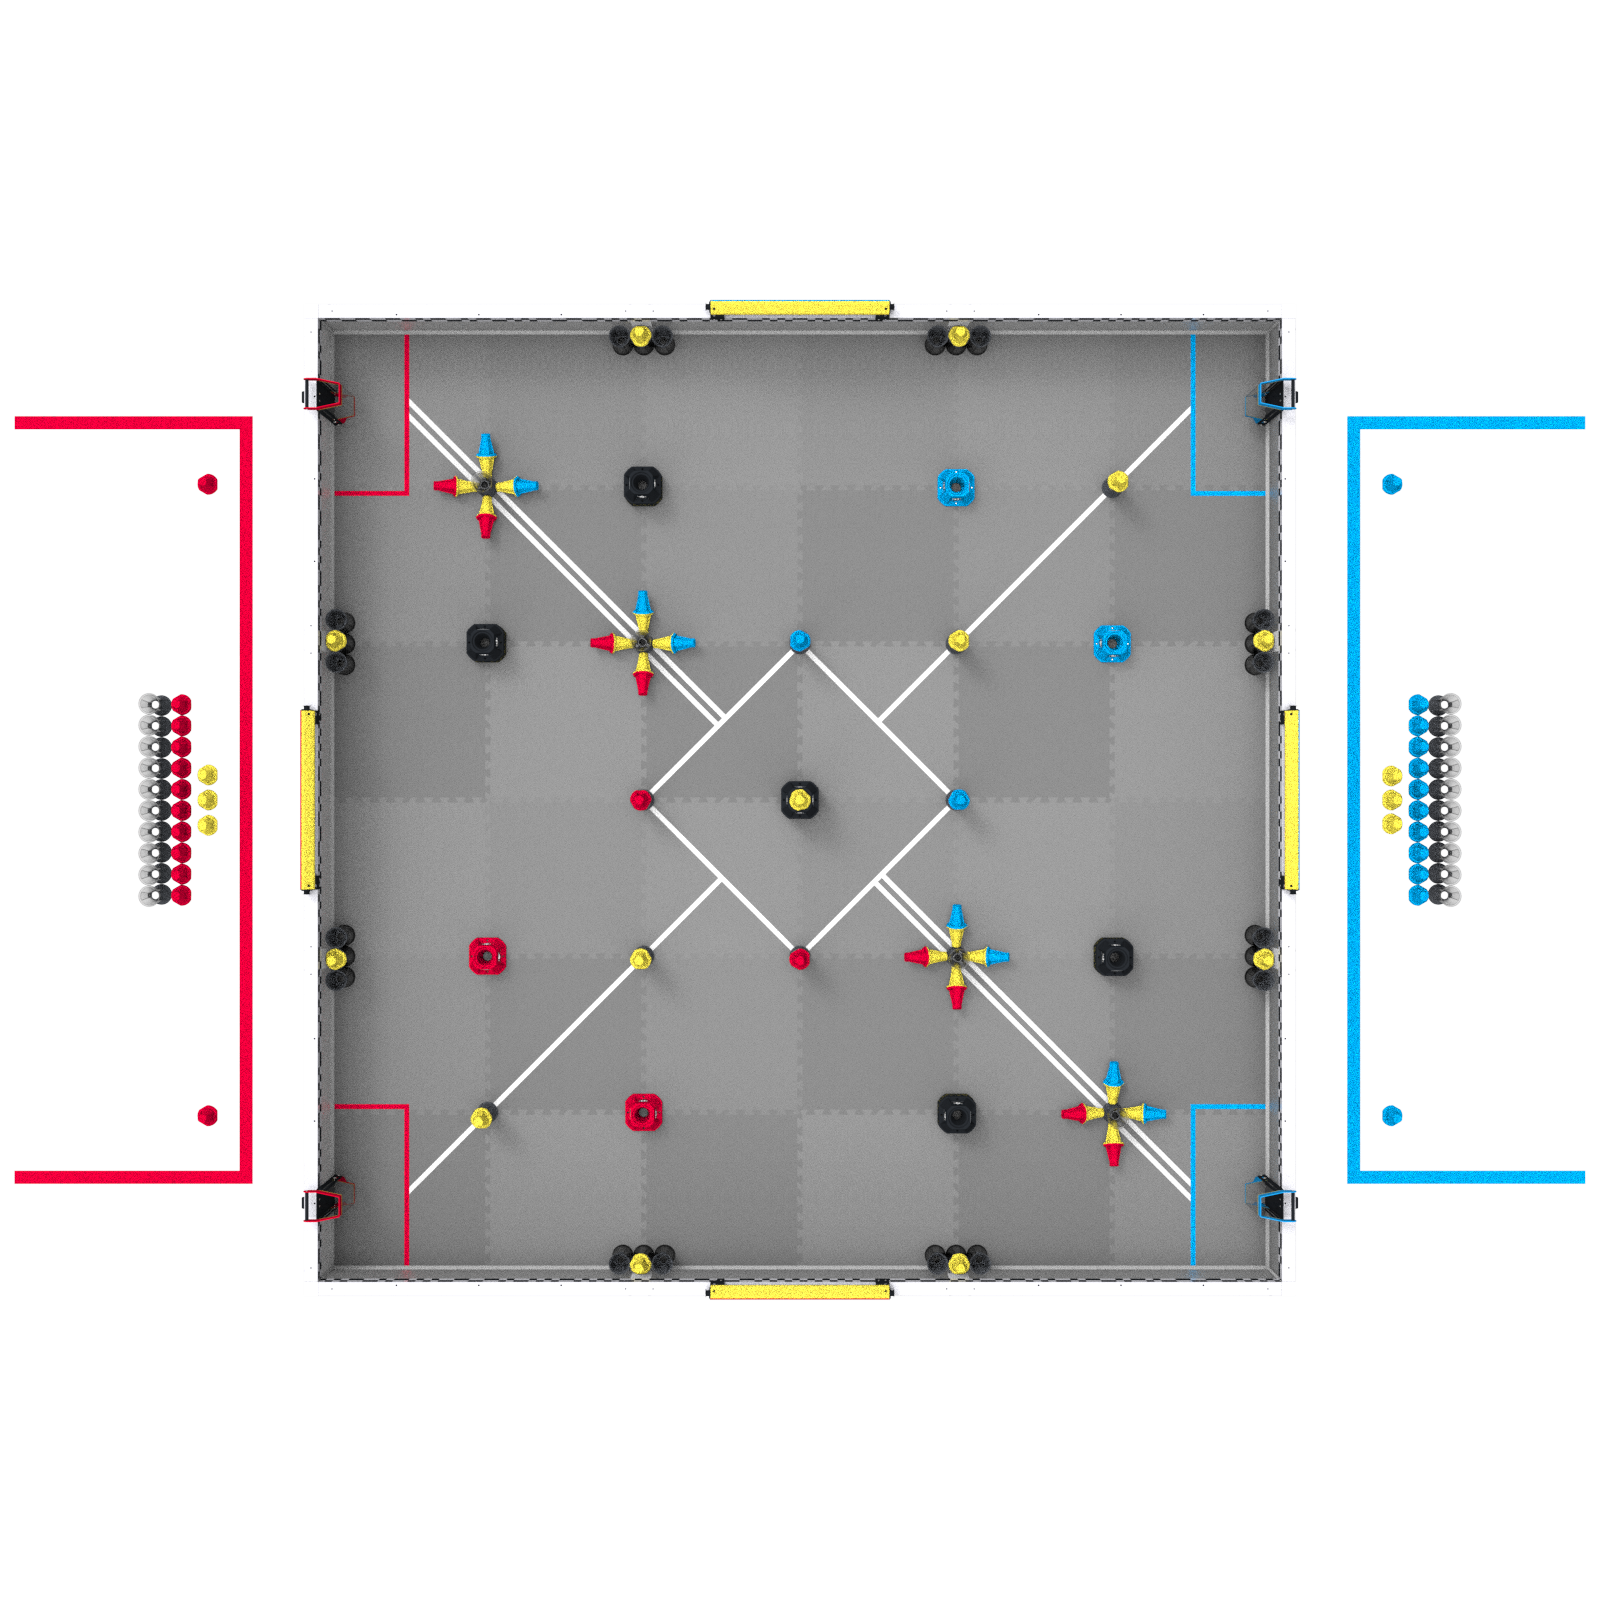
Figure SG-1: An overhead view of the Field, with four Robots in legal starting positions.
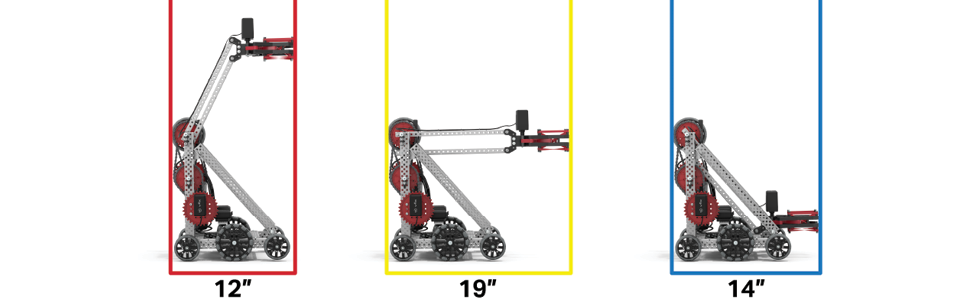
<SG2>Horizontal expansion is limited. Once the Match begins, Robots may expand horizontally beyond the starting size limit within the following criteria:
The Robot can never be larger than 24” wide or 24” long at any point during the Match (must fit within a 24”x24” square horizontal footprint).
Bent or broken mechanical components that are not used for strategic gain
Figure SG-2: A demonstration of how the size of the Robot may change horizontally through the course of a vertical expansion.
<SG3>Vertical expansion is limited. Once the Match begins, Robots may expand vertically beyond the starting size limit, but no part of the Robot may exceed an overall height of 50” at any point during the Match (must always be able to fit within a hypothetical 50” vertical sizing box).
<SG5>Each Robot gets one Pin as a Preload. Red AlliancePreloads are red/yellow Pins ; blue AlliancePreloads are blue/yellow Pins. Prior to the start of each Match, each Preload must be placed such that it meets all of the following criteria:
<SG6>Possession is limited to a maximum of one Pin and one Cup.Robots may not have Possession of more than one (1) Pin at once. Robots may not have Possession of more than (1) Cup at once. Robots in Violation of this rule must immediately stop all actions except for attempting to remove the excess Scoring Objects.
The Autonomous Period should be primarily Offensive, with Teams focusing on scoring and executing strategic maneuvers rather than Defensive disruption. Teams should avoid actions that are primarily Defensive in nature, including but not limited to:
While incidental contact or unintentional interactions may occur with Robots on the other side of the Autonomous Line, Teams that employ deliberate Defensive autonomous strategies that impact their opponents’ autonomous routines may be subject to Minor or Major Violations at the discretion of the Head Referee.
Intentional, strategic, or egregious Violations, such as intentional contact with an opposing Robot while contacting the foam tiles on the opposing side of the Autonomous Line, or the interactions described in <SG7e> will be considered Major Violations and should result in a Disqualification for the Match.
<SG8>Engage with the Midfield and/or Autonomous Line during the Autonomous Period at your own risk. Any Robot that engages with the Midfield and/or Scoring Objects that begin the Match on the Autonomous Line should be aware that opponent Robots may also choose to do the same. Per GG12 and GG13, Teams are responsible for the actions of their Robots at all times.
For the purposes of this rule, “engages with” means any combination of:
<SG9>Alliance Goals are protected.Robots may not directly or indirectly interact with opposing Alliance-colored Goals. Examples of interactions include, but are not limited to:
Strategically covering the Goal in a manner that prevents additional Scoring Objects from being Placed. (Indirect)
Pushing an opposing Robot into Scoring Objects stacked in their own Alliance-colored Goal, knocking some or all of them out of the Goal. (Indirect)
Violation Notes:
Incidental interactions, such as unintentional/inconsequential contact with the Goal and/or Scoring Objects stacked on the Goal, should typically be considered Minor Violations.
Intentional, strategic, or egregious interactions, as well as any interactions involving the addition or removal of PlacedScoring Objects on the Goal, will be considered Major Violations.
<SG10>Placed Scoring Objects may not be removed from neutral Goals via direct or indirect interactions. Examples of interactions include, but are not limited to:
For an interaction resulting in the removal of 1, 2, or 3 Pins, each Pin removed as part of this interaction should be considered worth a value of 10 points.
For an interaction resulting in the removal of 4+ Pins, the Pins removed as part of this interaction should be considered worth a combined value of 50 points.
The value of removed Pins is determined for each independent interaction/Violation. When multiple Violations occur, the point values attributed to each Violation may stack and can cumulatively become Match Affecting.
If subtracting these point values from the offending Alliance’s final score would change the outcome of the Match, then the Violation(s) should be considered Match Affecting. (These point values are not actually subtracted from the final scores of either Alliance; this is merely a check made by the Head Referee.) These calculations should be taken into account simultaneously for both Alliances, prior to determining whether any Violation affected the outcome of the Match in favor of one Alliance or the other.
Note: Head Referees cannot be expected to track the number of PinsPlaced in each Goal throughout a Match, and when Pins get removed from Goals, they cannot be expected to have a 100% accurate count of the Pins that were previously Placed in that Goal. For each interaction involving removed Pins, Head Referees can only be asked to make their best educated guess as to how many Pins were removed, and Teams must accept Head Referee counts, even if not perfectly accurate. (Accurately counting 1, 2, or 3 Pins is difficult. Counting beyond 3 becomes even less reliable, which is why a fixed point value applies to interactions resulting in the removal of 4+ Pins.)
"For the purposes of Match Affecting calculations, the removal of Placed Scoring Objects from neutral Goals should be evaluated as follows:
2. 3. a. For an interaction resulting in the removal of 1, 2, or 3 Pins, each Pin removed as part of
this interaction should be considered worth a value of 10 points.
b. For an interaction resulting in the removal of 4+ Pins, the Pins removed as part of this
interaction should be considered worth a combined value of 50 points.
This question is the definition of "pin" in the violation note.
<SC3><SC3> "Each Pin consists of two halves. Each visible half of a Placed Pin counts as a Scored Pin, according to the following:
Each visible red half of a Placed Pin counts as a Scored red Pin, earning points for the red Alliance.
Each visible blue half of a Placed Pin counts as a Scored blue Pin, earning points for the blue Alliance.
Each visible yellow half of a Placed and Owned Pin counts as a Scored yellow Pin, earning points for the Alliance that Owns the Pin. (See <SC5><SC5>.)
For a Pin half to be considered visible, the Pinhalf must not be partially or fully nested inside the opaque half of a Cup.”
Below (image 1) is 2 (physical pins) or 3 (pin halves)?
(these are not my drawings, I borrowed them from a friend)
Currently, a whole Pin (consisting of two halves) is referred to as a "Pin", and a visible half of a Placed Pin is referred to as a "Scored Pin". We definitely understand the confusion here, and we're hoping to resolve this confusion between Pins and Pin halves in the next game manual update.
In Q&A 3232, we mentioned that when Scoring Objects were removed from neutral Goals, we felt that tracking extra details, such as which parts of Pins were visible or not, was likely too much of a burden on Head Referees that could lead to excessive guesswork. As a result, Head Referees should only count the number of whole Pins removed from the Goal for each SG10 Violation, not the number of visible Pin halves.
For example, if an SG10 Violation involved the removal of two whole Placed Pins (consisting of 4 Pin halves), that would count as 2 Pins removed, meaning this SG10 Violation would be valued at 20 points.
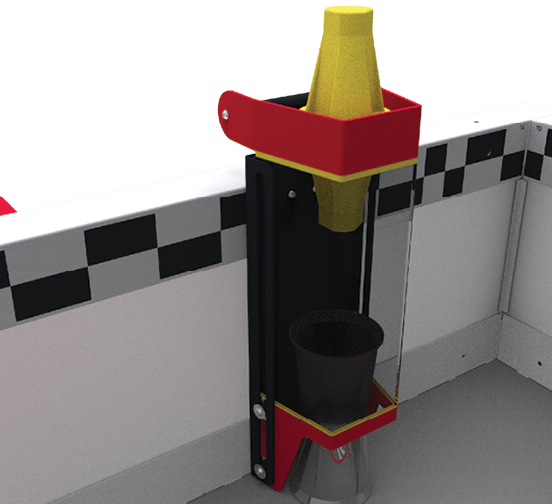
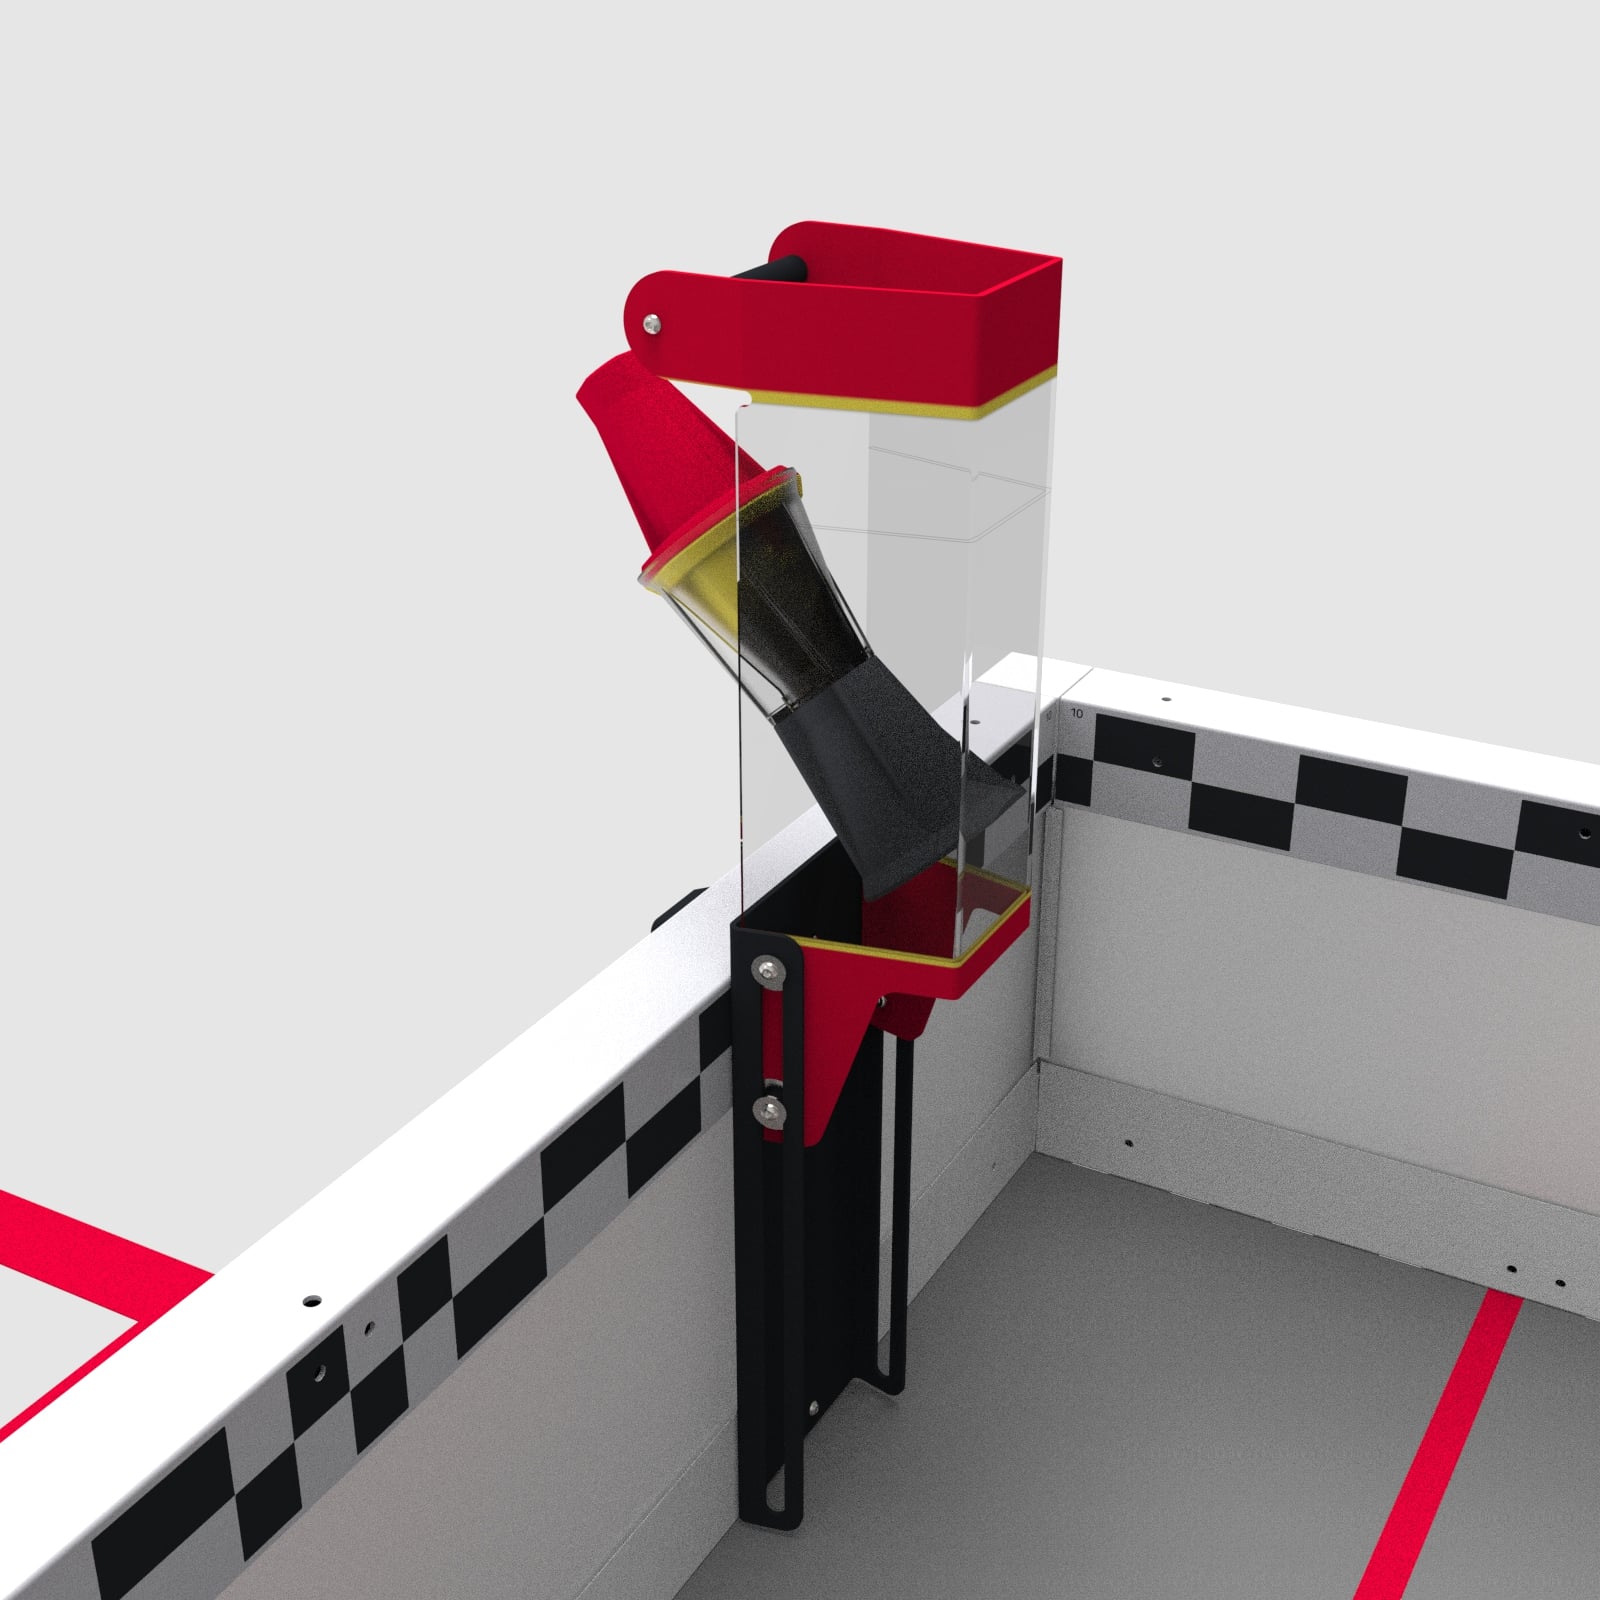
<SG11>Drive Team Members may only introduce Match Loads to the Field through Loaders, under the following conditions:
Robots that attempt to end the Match in the Midfield should expect vigorous interactions from opposing Robots, and must accept increased risk of becoming Entangled or being tipped, especially when vertically expanded. When a Robot is contacting or engaging with the Midfield, or is in proximity to the Midfield, incidental damage that is caused by opposing Robots pushing, tipping, or becoming Entangled with them would not be considered a Violation of GG14. Intentional damage or dangerous mechanisms may still be considered a Violation of S1 or G1 at the Head Referee’s discretion.
<SG13>Load Zones are protected during the Driver Controlled Period of the Match.
A Robot is protected while it is at least partially within one of its AllianceLoad Zones. Robots may not directly or indirectly contact a protected opposing AllianceRobot.
The intent of this rule is to protect Load Zones from intentional interference by the opposing Alliance (i.e., obstructing the Load Zone in an effort to inhibit Loader access).
<S2>Students must be accompanied by an Adult. Every Student at a VEX Robotics Competition event must be supervised by a responsible Adult. The Adult must obey all rules and be careful to not violate Student-centered policies, but must be present for the full duration of the event in the case of an emergency. Violations of this rule may result in removal from the event and additional penalties.
<S3>Each Student Team member must have a completed participant release form on file for the event and season. A StudentTeam member cannot participate in an event without a completed release form on file.
<S4>Stay inside the Field. If a Robot is completely outside of the Field during a Match, it will receive a Disablement for the remainder of the Match.
Note: The intent of this rule is not to penalize Robots for having mechanisms that inadvertently cross the Field Perimeter during normal game play.
<S5>Wear safety glasses.Drive Team Members must wear eye protection. All Drive Team Members must wear some form of eye protection while at the Field for Matches. Safety glasses or other eye wear with side shields and non-shattering lenses are recommended. While in the pit and queuing areas, it is highly recommended that all Team members wear eye protection.
<G1>Participants must follow the Code of Conduct. All event attendees must abide by the guidelines set forth in the Code of Conduct.
Violation Notes:
Any Violation of G1 may be considered a Major Violation and should be addressed on a case-by-case basis. Teams at risk of a G1Major Violation due to multiple disrespectful or uncivil behaviors will usually receive a “final warning”, although the Head Referee is not required to provide one.
<G2>Participants must follow the Student Centered Policy. All event attendees must abide by the guidelines set forth in the Student Centered Policy.
Violation Notes:
Potential Violations of this rule will be reviewed on a case-by-case basis. By definition, all Violations of this rule become Match Affecting as soon as a Robot which was built or programmed by an Adult scores points in a Match.
<G3>Use common sense. When reading and applying the various rules in this document, please remember that common sense always applies in the VEX V5 Robotics Competition.
<G4>Students must meet the Student Eligibility Policy requirements. All Student participants must fall within the eligibility requirements set forth in the Student Eligibility Policy for their respective program.
Violation Notes:
Teams believed to be in Violation of this rule should be reported to the Judge Advisor, Head Referee, or Event Partner for further investigation in coordination with VEX Robotics. Based on the investigation the Team may be removed from further Matches, have their Robot Skills Match scores removed, and/or be removed from consideration from judged awards.
Violations of this rule will be evaluated on a case-by-case basis, in tandem with VEX Robotics as noted in G1 and G2.
<G5>There is a difference between accidentally and willfully violating a Robot rule. Any Violation of Robot rules, accidental or intentional, will result in a Team being unable to play until they pass inspection (per <R2d>).
However, Teams who intentionally and/or knowingly circumvent or violate rules to gain an advantage over their fellow competitors are in Violation of the spirit and ethos of the competition.
Violation Notes:
A Team that circumvents a Robot rule for a competitive advantage should receive an immediate Disqualification for the current Match.
Drive Team Members are prohibited from any of the following actions during a Match :
Using any sort of communication device in the Alliance Station. Non-headphone devices with communication features turned off (e.g., a phone in airplane mode, a walkie talkie turned off, smart glasses with communication features disabled) are allowed. Communication features can be enabled for translation apps during post-Match discussions.
Standing or sitting on any sort of object during a Match, regardless of whether the Field is on the floor or elevated, except as required by an officially approved accommodation request.
Bringing/using additional materials to simplify the game challenge during a Match (e.g., device to align or add Scoring Objects to a Loader.
To ensure that Drive Team Members are aware of verbal calls during a Match (as an application of rules T1, G1, S1, and G3 ), powered headphones, earbuds, passive earpieces connected to electronic devices, or other personal accessories/devices that transmit audio cannot be worn/used in the Alliance Station except as required by an officially approved accommodation request.
Individuals who are not Drive Team Members for a Match cannot provide directions, commands, or advice to the Drive Team Members during that Match. They’re welcome to provide cheerful, positive encouragement, but should not affect Match play or strategy.
<GG3>Robots on the Field must be ready to play. When a Team puts their Robot on the Field, it must be prepared to play (e.g., battery charged, sized within the starting size constraint, includes only the correct Alliance -color license plates, etc.).
Robots must be placed on the Field promptly. Repeated failure to do so could result in a Violation of G1 and/or removal of the Robot from the current Match at the Head Referee’s discretion.
If a Robot is delaying the scheduled start of a Match, it may be removed from the Field at the discretion of the Head Referee and Event Partner. The Robot may remain at the Field so that the Team does not get assessed a “no-show” (per GG2 ).
If a Robot is not placed on the Field prior to the start of a Match, it cannot be placed on the Field during that Match.
Teams who use VEX pneumatics must have their systems charged before they place the Robot on the Field.
If an event is using Smart Field Control and a Robot is unable to successfully connect to Smart Field Control prior to the scheduled start of a Match, the Head Referee may ask the Team to remove their Robot from the Field in accordance with clause B.
A Robot that connects to Smart Field Control but displays a ‘Legacy Field Control’ error on the field monitor is NOT considered successfully connected to Smart Field Control, and may be removed from the Field if it is delaying the scheduled start of a Match.
During the Driver Controlled Period, Drive Team Members may reach into the Field and touch their own Robot only if the Robot has not moved at all during the Match. Movement caused by an external force, such as another Robot, should not prevent a Drive Team Member from interacting with their Robot under this rule. Touching the Robot in this case is permitted only for the following reasons:
Touching the V5 Robot Brain screen, such as to start a program.
This rule is applied differently for the VEX AI Robotics Competition. See Rule VAIG2.
<GG5>Match replays are allowed, but rare.Match replays (i.e., playing a Match over again from its start) must be agreed upon by both the Event Partner and Head Referee, and will only be issued in the most extreme circumstances. Some example situations that may warrant a Match replay are as follows (note that this is not an exhaustive list):
Field control disconnecting or Disabling multiple Robots. Note, this is sometimes confused with a Robot whose motors have overheated, or bent pins on a controller’s competition port causing intermittent drop-outs. In general, any true Field fault will impact both Alliances simultaneously, not one Robot at a time.
<GG8>Keep your Robots together.Robots may not intentionally detach parts during the Match or leave mechanisms on the Field.
Note: Parts which become detached unintentionally are a Minor Violation, are no longer considered “part of a Robot,” and should be ignored for the purpose of any rules which involve Robot contact or location (e.g., scoring) or Robot size.
Violation Notes:
Major Violations of this rule should be rare, as Robots should never be designed to intentionally violate it. Minor Violations are usually due to Robots being damaged during gameplay, such as a wheel falling off.
<GG9>Don’t hook your Robot to the Field, and don’t get Entangled.Robots may not intentionally grasp, grapple, hook, attach to or otherwise Entangled with any Field Elements. Strategies with mechanisms that react against multiple sides of a Field Element in an effort to latch or hook onto said Field Element are prohibited. The intent of this rule is to prevent Teams from unintentionally damaging the Field and/or from anchoring to or otherwise Entangling themselves with the Field.
Whenever possible, Head Referees should alert Teams to potential Violations before they happen to prevent actual Violations. If a Robot takes immediate action to avoid or resolve the issue, and if the Head Referee determines that the issue had no effect on the Match, no Violation should be recorded.
<GG10>The red Alliance may choose to place last. The red Alliance has the right to place its Robots on the Field last in Qualification Matches and Elimination Matches. Once a Team has placed its Robot on the Field, in order to avoid schedule delays its position should not be adjusted prior to the Match. GG3 applies. If a Team chooses to reposition their Robot after it has already been placed, the opposing Alliance will also be given the opportunity to reposition their Robots promptly.
This rule is applied differently for VEX U. See Rule VUG2.
This rule is applied differently for the VEX AI Robotics Competition. See Rule VAIG1.
<GG11>Controllers must stay connected to the Field. Prior to the beginning of each Match, Drive Team Members must plug their V5 Controller into the Field’s control system. This cable must remain plugged in for the duration of the Match, and may not be removed until the “all-clear” has been given for Drive Team Members to retrieve their Robots. See T8 for more information regarding Field control system options.
Violation Notes:
The intent of this rule is to ensure that Robots abide by commands sent by the tournament software. Temporarily removing the cable to assist with mid-Match troubleshooting, with an Event Partner or other event technical staff present and assisting, would not be considered a Violation.
<GG12>Autonomous means “no humans.” During the Autonomous Period, Drive Team Members are not permitted to interact with the Robots in any way, directly or indirectly. This could include, but is not limited to:
Activating any controls on their V5 Controllers
Unplugging or otherwise manually interfering with the Field connection in any way
Manually triggering sensors (including the Vision Sensor) in any way, even without touching them
Note: In extreme cases, with permission from the Head Referee, Teams may Disable their Robot during the Autonomous Period by holding the power button on their V5 Controller. This exception is only intended for egregious safety- or damage-related circumstances; Disabling an autonomous routine for strategic purposes would still be considered a Violation of GG12.
<GG14>Don’t destroy other Robots.But, be prepared to encounter defense. Strategies aimed solely at the destruction, damage, tipping over, or Entanglement of opposing Robots are not part of the ethos of the VEX V5 Robotics Competition and are not allowed.
VEX V5 Override is intended to be an Offensive game. Teams that partake in solely Defensive or destructive strategies will not have the protections implied by this rule (see GG15 ). However, Defensive play which does not involve destructive or illegal strategies is still within the spirit of this rule.
VEX V5 Override is also intended to be an interactive game. Some incidental tipping, Entanglement, and damage may occur as a part of normal gameplay without Violation. It will be up to the Head Referee’s discretion whether the interaction was incidental or intentional.
A Team is responsible for the actions of its Robot at all times, including the Autonomous Period. This applies both to Teams that are driving recklessly or potentially causing damage, and to Teams whose Robots have small and/or unstable wheel bases. A Team should design its Robot such that it is not easily tipped over or damaged by minor contact.
<GG15>Offensive Robots get the “benefit of the doubt” when judgment calls are required. In a case where a Head Referee is forced to make a judgment call regarding a destructive interaction between a Defensive and OffensiveRobot, or an interaction which results in a questionable Violation, referees will decide in favor of the OffensiveRobot. This also applies during the Autonomous Period (see <SG7a>).
<GG16>You can’t force an opponent into a penalty. Actions that cause an opposing Robot to break a rule are not permitted, and will not result in a Violation for the opposing Robot.
Violation Notes:
In most cases, if a Team causes their opponent to break a rule, the Head Referee will simply not enforce the penalty on that opponent, and it will be considered a Minor Violation for the Team that forced a Violation. However, if the forced situation becomes Match Affecting in favor of the Team that forced the Violation, it will be considered a Major Violation for the Team that forced the Violation.
For the purposes of this rule, a “count” is defined as an interval of time that is approximately one second in duration, and “counted out” by Head Referees verbally. A Holding count should begin immediately once the Head Referee observes a suspected Holding interaction.
The Holding count should pause when at least one of the following conditions is met:
The two Robots are separated by at least two (2) feet (approximately one foam tile).
Either Robot has moved at least two (2) feet away (approximately one tile) from the location where the Trapping or Pinning count began.
In the case of Lifting, this location is measured from where the Lifted Robot is released, not from where the Lifting began.
In this case, the original count would end, and a new count would begin for the newly Trapped or Pinned Robot.
In the case of Trapping, if an avenue of escape becomes available due to changing circumstances in the Match.
After a Holding count ends, a Robot may not resume Holding the same Robot again for a 5-count. If a Team resumes Holding the same Robot within that 5-count, the original Holding count will resume from where it ended. A Head Referee should use fingers to display the 5-count that occurs after the end of a Holding count, and “wave it off” after the Holding interaction has been cleared.
If two Robots are working together to Trap an opponent simultaneously, the Holding count can be applied to both Robots ; it’s possible for them to legally take turns Trapping, but it’s risky.
Violation Notes:
When determining whether a HoldingViolation was Match Affecting, they should consider the full context of the Match and both Robots’ actions, including the following. Because the first three seconds of a Hold are legal game play and not a Violation, only the extended portion of a Hold should be considered. Holding is an inherently Defensive action, so rule GG15 may also be considered if a judgment call is required.
How much extra time was included in the Holding interaction
How long the Robots were separated if the HoldingRobot backs away and returns too early
What both Robots were doing within the larger context of the Match
<GG18>Use Scoring Objects to play the game.Scoring Objects may not be used to accomplish actions that would be otherwise illegal if they were attempted by Robot mechanisms. If a rule is Violated through the use of a Scoring Objects instead of a Robot mechanism, it should be evaluated as though the rule in question had been Violated by a Robot mechanism. Examples include, but are not limited to:
Interfering with an opponent’s Autonomous routine per SG7
The intent of this rule is to prohibit Teams from using Scoring Objects as “gloves” to loophole any rule that states “a Robot may not [do some action].” This rule is not intended to be taken in its most extreme literal interpretation, where any interaction between a Scoring Object and a Robot needs to be scrutinized with the same intensity as if it were a Robot.
In the Robot Skills Challenge, the standard definition of Match Affecting does not apply, because there is no winner or loser. When evaluating whether a rule Violation should be classified as a Major Violation or Minor Violation in the context of this criteria, the term “score affecting” can be substituted for “Match Affecting.” A Violation is considered “score affecting” if it results in a net increase of that Team’s score at the end of the Match.
Violations of <GG>, <SG>, and <RSC> rules that occur during a Robot Skills Match should only affect the outcome of that Match and should not be considered when determining whether a Violation has been repeated during the event.
<RSC2>Match play is different in Robot Skills Matches.
Robots may move freely about the Field after the start of the Match.
This rule is applied differently for VEX U. See Rule VURS3.
<RSC3>Scoring Robot Skills Matches. For each Robot Skills Match, Teams are awarded a score based on the following rules and scoring table:
The Team will earn points for ScoredPin Halves of any color. To be considered Scored, each visible half of a PlacedPin must also meet the following conditions:
This V5 Robot Brain must be running the official field control user program.
For more information regarding the use of a V5 Robot Brain for Robot Skills Challenge field control, and to download the official field control user program, visit this VEX Knowledge Base article.
For more information regarding the use of TM Mobile for field control, see the Tournament Manager documentation.
At events which do not have a V5 Robot Brain or the TM Mobile App available for Robot Skills Challenge field control, Drive Team Members and field staff must agree prior to the Match on the signal that will be used to end the Match early. A manual timer must be used in conjunction with a VEXnet Competition Switch.
The moment when the Match ends early is defined as the moment when the Robot is “Disabled ” by the field control system. The time shown on the timer should be rounded up to the nearest second. For example, if the Robot is Disabled and the timer shows 25.2 seconds, then the Skills Stop Time should be recorded as 26.
The agreed-upon signal must be both verbal and visual, such as Drive Team Members crossing their arms in an “X” or placing their V5 Controller(s) on the ground.
It is recommended that Drive Team Members also provide verbal notice that they are approaching their Skills Stop Time, such as by counting out “3-2-1-stop.”
It is at the Event Partner’s discretion which method will be used to record Skills Stop Times at a given event. The chosen method must be communicated prior to the start of Matches (such as during an event meeting), and made equally available to all Teams.
If an event intends to use a manual timekeeping method, a Team cannot bring their own V5 Robot Brain just for use during their own Robot Skills Match.
If an event is using multiple Fields for Robot Skills Matches, the same method must be used at all Fields, as described in rule T21. Multiple V5 Robot Brains may be used as needed (e.g., a “Field 1 Brain” and a “Field 2 Brain”).
The default timed “Drive” program accessed from a V5 Controller is intended for practice only, and cannot be used for an official Robot Skills Match.
If a Team chooses to utilize/record a Skills Stop Time, the 5-second grace period described in rule SC1 does not apply.
All Robots must pass inspection before competing in the VEX V5 Robotics Competition to ensure compliance with all Robot rules. Inspections typically occur during Team check-in or practice time. Teams should use the rules below to pre-inspect their Robot and confirm it meets all requirements.
Most rules are hard limits (e.g., motor quantity), while others are subject to inspector discretion (e.g., safety concerns). At many events, the lead inspector and Head Referee are the same person; if not, inspectors should consult the Head Referee for judgment calls. Per <R2d> and <R2e>, the Head Referee has final authority on all Robot rules and whether a Robot may compete.
<R1>One Robot per Team. Each Team can only bring one Robot to a given event in the VEX V5 Robotics Competition. Though it is expected that Teams will make changes to their Robot at the competition, a Team is limited to only one Robot at a given event, and a given Robot may only be used by one Team. A VEX Robot, for the purposes of the VEX V5 Robotics Competition, has the following subsystems:
Subsystem 1: Mobile robotic base including wheels, tracks, legs, or any other mechanism that allows the Robot to navigate the majority of the flat playing Field surface. For a stationary Robot, the robotic base without wheels would be considered Subsystem 1.
Subsystem 2: Power and control system that includes a legal VEX battery, a legal VEX control system, and associated motors for the mobile robotic base.
Subsystem 3: Additional mechanisms (and associated motors) that allow manipulation of Scoring Objects and interactions with Field Elements and other Robots.
Given the above definitions, a minimum Robot for use in any VEX V5 Robotics Competition event (including Robot Skills Matches ) must consist of subsystems 1 and 2 above. Thus, if you swap out an entire subsystem 1 or 2, you have created a second Robot and are in Violation this rule.
Teams may not compete with one Robot while a second is being modified or assembled at a competition.
Teams may not have an assembled second Robot on hand at a competition that is used to repair or swap parts with the first Robot.
Multiple Teams may not use the same Robot. Once a Robot has competed under a given Team number at an event, it is “their” Robot ; no other Team may EVER compete with it.
This rule is applied differently for VEX U. See Rule VUR1.
<R2>Robots must pass inspection. Every Robot will be required to pass a full inspection before being cleared to compete. This inspection will ensure that all Robot rules and regulations are met. Noncompliance with any Robot design or construction rule will result in removal from Matches or Disqualification of the Robot at an event until the Robot is brought back into compliance, as described in the following subclauses.
Significant changes to a Robot, such as a partial or full swap of Subsystem 3, must be re-inspected before the Robot may compete again.
All possible functional Robot configurations must be inspected before being used in competition. This especially pertains to modular or swappable mechanisms (per R1 ) and Match starting configurations/sizes (per R3 ).
If a Robot is determined to be in Violation of a Robot rule before a Match begins, the Robot will be removed from the Field. The Robot may remain at the Field so that the Team does not get assessed a “no-show” (per GG2 ).
Robots which have not passed inspection (i.e., that are in Violation of one or more Robot rules) will not be permitted to play in any Matches until they have passed inspection. GG2 will apply to any Matches that occur until the Robot has passed inspection.
If a Robot has passed inspection, but is later confirmed to be in Violation of a Robot rule during or immediately following a Match by a Head Referee, they will be Disqualified from that Match. This is the only Match that will be affected; any prior Matches that have already been completed will not be revisited. <R3d> will apply until the Violation is remedied and the Team is re-inspected.
All robot rules are to be enforced within the discretion of the Head Referee within a given event. Robot legality at one event does not automatically imply legality at future events. Robots which rely on “edge-case” interpretations of subjective rules, such as whether a decoration is “non-functional” or not, should expect additional scrutiny during inspection.
Events may wish to use “inspection markers” (e.g., zip tie or sticker) to identify Robots that have passed inspection at that event. Inspection markers are functional components and are subject to all Robot rules, including legal materials and Robot size/expansion limits.
Event staff and volunteers are allowed to contact and/or photograph Robots during inspection and/or at other times as needed.
<R3>Robots must fit within an 18” x 18” x 18” volume.
Compliance with this rule may be checked using the official VEX Robotics On-FieldRobot Expansion Sizing Tool.
Event Partners may construct and/or provide any sizing tool that measures the correct dimensions.
Any restraints used to maintain starting size (i.e., zip ties, rubber bands, etc.) must remain attached to the Robot for the duration of the Match, per GG8.
For the purposes of this rule, it can be assumed that Robots will be inspected and begin each Match on a flat standard foam field tile.
This rule is applied differently for VEX U. See Rule VUR1.
This rule is applied differently for the VEX AI Robotics Competition. See Rule VAIRM2.
<R4>Officially registered Team numbers must be displayed on Robot license plates. To participate in an official VEX V5 Robotics Competition event, a Team must first register on events.vex.com and receive a VEX V5 Team number. This Team number must be displayed on the Robot using license plates. Teams may choose to use the official VEX V5 License Plate Kit, or may create their own using legal materials.
License plates must be placed in fixed locations on exactly two (2) horizontally opposing sides of the Robot and must remain visible, legible, and attached for the entirety of the Match. The top of a Robot is not considered a “side” for these two license plates.
License plates should be mounted in locations that remain stationary on the Robot during a Match (e.g., not on a rotating intake or flipping manipulator). The function of license plates is to identify Robots for referees, spectators, and other Teams. Identification is harder when a license plate on a Robot moves during a Match.
License plates must be securely attached to the Robot using materials that are legal for Robot construction. VEX IQ pins are not legal for mounting license plates on Robots.
Robots may only include license plates that match their Alliance color for the current Match (i.e., red AllianceRobots must have only red plates installed for the Match ).
License plates are considered functional components, and must meet the requirements of all Robot rules.
Additional license plates cannot be used on the Robot for any purpose.
Team numbers must be in white font, and clearly legible. Number/letter stickers are legal for use on license plates instead of or in addition to those in the VEX V5 License Plate Kit.
Custom license plates used to meet the requirements of <R4a> and <R4f> must be within the following size limits:
Height: between 2.0 (50.8mm) and 2.5 inches (63.5mm)
Width: between 4.0 (101.6mm) and 4.5 inches (114.3mm)
Thickness: up to 0.25” (6.35mm)
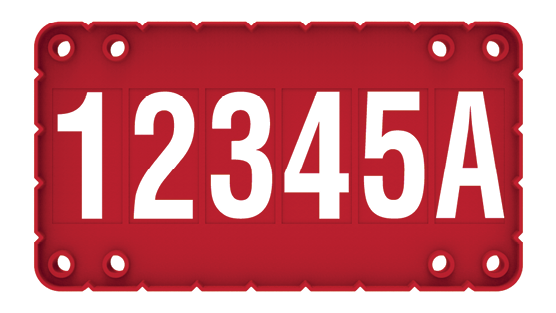
Figure R4-1: An example of a license plate made from the VEX V5 License Plate Kit.
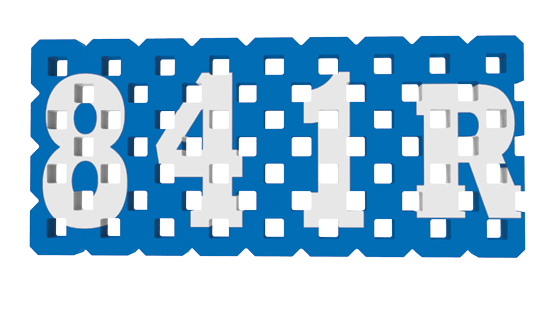
Figure R4-2: An example of a legal custom license plate
<R5>Let go of Scoring Objects after the Match.Robots must be designed to permit easy removal of Scoring Objects from any mechanism without requiring the Robot to have power after a Match.
<R6>Robots have one Brain.Robots must ONLY use one (1) VEX V5 Robot Brain (276-4810). Any other microcontrollers or processing devices are not allowed, even as non-functional decorations.
This includes microcontrollers that are part of other VEX product lines, such as VEX Cortex, VEX EXP, VEXpro, VEX CTE, VEX RCR, VEX IQ, VEX GO, VEX AIR, or VEX Robotics by HEXBUG. This also includes devices that are unrelated to VEX, such as Raspberry Pi or Arduino devices.
V5 Robot Brain accessories (short flanges, long flanges, and the magnetic screen protector) are part of the V5 Robot Brain and are only legal for use on Robots as part of the V5 Robot Brain.
At events using a V5 Smart Field Control System, the “Team Number” field in the Robot Brain must be set as the Team’s registered number and letter (with no spaces).
This rule is applied differently for VEX U. See Rules VUR10 and VUR12.
<R7>Keep the power button or battery connection accessible. The on/off button on the V5 Robot Brain and/or the Battery Cable connection on either the V5 Robot Brain or V5 Robot Battery must be accessible without moving or lifting the Robot. The V5 Brain screen should be easily visible during Robot inspection. Keeping the V5 Brain screen visible throughout a Match is recommended but not required.
The minimum version requirement is subject to change over the course of the season.
When the minimum version is updated, Teams have a one week (7 calendar day) grace period from the time the minimum version is changed to update their firmware to the latest minimum version.
VEX reserves the right to deem any firmware update critical, and remove the allowable grace period.
Beta firmware, which includes any firmware version that ends with the letter ‘b’, is not legal for use in competition.
<R9>Use a “Competition Template” for programming. The Robot must be programmed to follow control directions provided by the VEXnet Field Controllers or Smart Field Control system.
This may be tested in inspection, where Robots may be required to pass a functional “enable/disable” test. For more information on this, Teams should consult the help guides produced by the developers of their chosen programming software.
<R10>Motors are limited.Robots may use any combination of V5 Smart Motors, 11W (276-4840) and/or 5.5W (276-4842), within the following criteria:
The combined power of all motors (11W & 5.5W) must not exceed 88W. This limit applies to all motors on the Robot, even those which are not plugged in.
V5 Smart Motors connected to Smart Ports are the only motors that may be used with a V5 Robot Brain. The 3-wire ports may not be used to control motors of any kind.
Example
A
B
C
D
E
Qty of 11W motors
8
7
6
5
0
Qty of 5.5W motors
0
2
4
6
16
This rule is applied differently for VEX U. See Rule VUR11.
<R11>Motors are limited for Subsystem 2 (see <R1>)Robots may use any combination of V5 Smart Motors, 11W (276-4840) and/or 5.5W (276-4842), in Subsystem 2 within the following criteria:
The combined power of all motors in Subsystem 2 must not exceed 55W.
Motors used in Subsystem 2 cannot provide power to any mechanism that is not a part of Subsystem 1.
Motors in Subsystem 2 cannot be toggled, engaged, or configured such that they are capable of providing power to any part of the Robot that is not a part of Subsystem 1
Teams may be required to demonstrate what each motor is capable of powering on their Robot during inspection in order to satisfy this requirement.
<R12>Electrical power comes from VEX batteries only.Robots may use one (1) V5 Robot Battery (276-4811) to power the V5 Robot Brain.
No other sources of electrical power are permitted, unless used as part of a non-functional decoration per <R23e>.
There are no legal power expanders for the V5 Robot Battery.
V5 Robot Batteries may only be charged by a V5 Robot Battery Charger (276-4812 or 276-4841).
V5 Controllers (276-4820) may only be powered by their internal rechargeable battery.
Teams are permitted to have an external power source (such as a rechargeable battery pack) plugged into their V5 Controller during a Match, provided that this power source is connected safely and does not violate any other rules, such as R28.
Some events may choose to provide Field power for V5 Controllers. If this is provided for all Teams at the event, then this is a legal power source for the V5 Controllers.
This rule is applied differently for VEX U. See Rule VUR12.
<R13>Robots use VEXnet.Robots must ONLY utilize VEXnet for all wireless Robot communication.
Electronics from the Cortex, VEX EXP, VEX CTE. VEXpro, VEX RCR, VEXplorer, VEX IQ, VEX GO, or VEX Robotics by HEXBUG product line are prohibited unless otherwise noted in R16.
Teams are permitted to use the Wi-Fi capabilities of the Vision Sensor in Team pits or outside of Matches. However, the Vision Sensor must have its wireless transmitting functionality disabled during Matches.
This rule is applied differently for VEX U. See Rules VUR2, VUR10 and VUR12.
<R14>Give the radio some space. The V5 Radio should be mounted such that no metal surrounds the radio symbol on the V5 Radio. While failure to do so will affect Robot performance, it will not prevent the Robot from passing inspection.
<R15>One or two Controllers per Robot. No more than two (2) VEX V5 Controllers may control a single Robot.
No physical or electrical modification of these Controllers is allowed under any circumstances.
Attachments which assist the Drive Team Member in holding or manipulating buttons/joysticks on the V5 Controller are permitted, provided that they do not involve direct physical or electrical modification of the Controller itself.
No other methods of controlling the Robot (light, sound, etc.) are permissible.
Using sensor feedback to augment driver control (such as motor encoders or the Vision Sensor) is permitted.
<R16>Robots are built from the VEX V5 system.Robots may be built ONLY using official VEX
V5 components, unless otherwise specifically noted within these rules.
Any questions or concerns about legal parts should be directed to the official Q&A System on events.vex.com.
This rule is applied differently for VEX U. See Rule VUR2.
<R17>New VEX parts are legal. Additional VEX components released during the competition season on www.vexrobotics.com are considered legal for use unless otherwise noted.
Some “new” components may have certain restrictions placed on them upon their release. These restrictions will be documented in the official Q&A, in a Game Manual update, or in the VEX V5 Legal Parts List.
<R18>Prohibited Items. The following types of mechanisms and components are NOT allowed.
Those that could pose a potential safety hazard to Drive Team Members, event staff, or other humans.
Products from the VEXpro, VEX EXP, VEX IQ, VEX GO, VEX 123, VEX CTE, VEX AIM, VEX AIR, VEX Robotics by HEXBUG*, or any other VEX product lines, unless specifically allowed by a clause of R16 or listed in the VEX V5 Legal Parts List (See R16 ).
Components obtained from the V5 beta program. All V5 beta hardware can be identified by its lighter gray pre-production color. Robot Brains, Robot Batteries, Controllers, and Vision Sensors from the V5 beta have a “BETA TEST” stamp on them. Smart Motors and Radios do not have this stamp, but can still be identified by color.
Standalone VEX Smart Field Controller Brains (SKU 276-7577).
VEX apparel, competition support materials, packaging, or other non-Robot products.
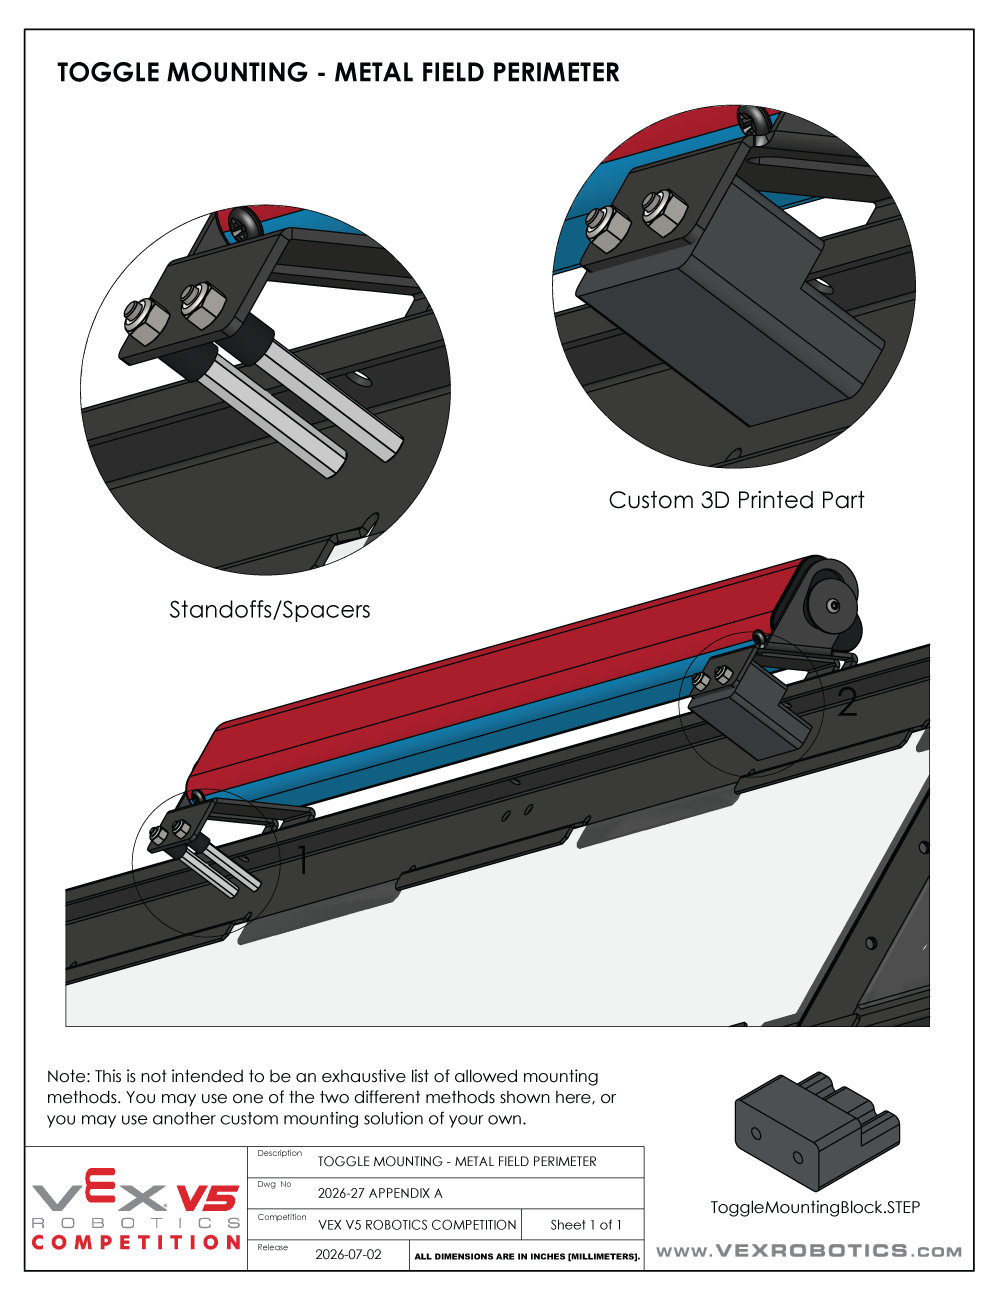
Field Elements or components of Field Elements that are not otherwise explicitly legal materials (e.g., screws, standoffs, nuts, or non-shattering plastic within the limitations of R24 ).
3D printed Robot parts for any purpose, including non-functional decorations and license plates.
Speakers and other audio devices that create sound.
This rule is applied differently for VEX U. See Rules VUR2, VUR5, VUR6, & VUR13.
* The HEXBUG brand is a registered trademark belonging to Spin Master Corp
<R19>Certain non-VEX components are allowed.Robots are allowed the following additional components from sources other than VEX Robotics:
Any non-aerosol-based grease or lubricating compound, when used in extreme moderation on surfaces and locations that do NOT contact the playing Field walls, foam Field tiles, Scoring Objects, or other Robots. Grease or lubricant applied directly to V5 Smart Motors or Smart Motor cartridges is prohibited.
Anti-static compound, when used in extreme moderation (i.e., such that it does not leave residue on Field Elements, Scoring Objects, or other Robots ).
Hot glue when used to secure cable connections.
An unlimited amount of non-elastic rope/string, no thicker than 1/4” (6.35mm).
Commercially available items used solely for bundling or wrapping of 2-wire, 3-wire, 4-wire, or V5 Smart Cables, and/or pneumatic tubing are allowed. These items must solely be used for the purposes of cable/tubing protection, organisation, or management. This includes but is not limited to electrical tape, cable carrier, cable track, etc. It is up to inspectors to determine whether a component is serving a function beyond protecting and managing cables and tubing.
Rubber bands no larger than 7.5” long and 0.25” wide.
Anti-slip drawer liner with similar nominal dimensions to VEX Anti-Slip Mat (275-0120 or 275-0121). The pattern of the matting should be similar to VEX Anti-Slip Mat, and there should be no additional performance gained by using non-VEX anti-slip drawer liner (i.e., no additional elasticity, adhesive backing, etc.). No piece of anti-slip drawer liner can be larger than 12” x 15” and all anti-slip drawer liner must be black in color.
Plastic zip ties no larger than 12” long and 0.25” wide.
Aerosol-based cooling/freeze spray may be used to assist in cooling motors. Teams using freeze spray or similar products in ways that may reasonably be deemed unsafe could be subject to S1Violations.
Cleaners, disinfectants, and/or sanitizers may be used to assist in cleaning Robots, parts, components, etc.
See rules R21 through R25 for additional legal non-VEX components.
<R20>Custom V5 Smart Cables are allowed.Teams who create custom cables acknowledge that incorrect wiring may have undesired results.
Official V5 Smart Cable Stock must be used.
Use of non-VEX 4P4C connectors and 4P4C crimping tools is permissible.
V5 Smart Cables may only be used for connecting legal electronic devices to the V5 Robot Brain.
<R21>A limited amount of tape is allowed.Robots may use a small amount of tape for the following purposes:
To secure any connection between the ends of two (2) VEX cables.
To label wires, motors, Robot Brains, and/or controllers.
To prevent leaks on the threaded portions of pneumatic fittings. This is the only acceptable use of Teflon tape.
In any other application that would be considered a “decoration” per R23.
As an aglet at the end of rope/string to prevent fraying.
<R22>Certain non-VEX fasteners are allowed.Robots may use the following commercially available hardware:
#4, #6, #8, M3, M3.5, or M4 screws up to 2.5” (63.5 mm) long, and M2.5 x 8mm screws.
Shoulder screws with a shoulder length no longer than 0.20” and a diameter no larger than 0.176”.
Any commercially available nut, washer, threaded standoff up to 6” (152.4mm) long, and/or non-threaded spacer up to 2.5” (63.5mm) long which fits these screws.
This rule is applied differently for VEX U. See Rule VUR9.
<R23>Visual decorations are allowed.Teams may add non-functional decorations, provided that they do not affect Robot performance in any significant way or affect the outcome of the Match. These decorations must be in the spirit of the competition. Inspectors and Head Referees will have final say in what is considered “non-functional.” Unless otherwise specified below, non-functional decorations are governed by all standard Robot rules.
To be considered “non-functional,” decorations must be backed by legal materials that provide the same functionality. For example, if a Robot has a giant decal that prevents Scoring Objects from falling out of the Robot, the decal must be backed by VEX material that would also prevent the Scoring Objects from falling out. A simple way to check this is to determine if removing the decoration would impact the performance of the Robot in any way.
Anodizing, painting, dyeing, or otherwise changing the color of any legal VEX part is considered a legal nonfunctional decoration.
Note: For official events held in mainland China, anodizing, painting, dyeing, or otherwise changing the color of any legal VEX part is prohibited.
Small cameras are permitted as non-functional decorations, provided that any transmitting functions or wireless communications are disabled. Unusually large cameras used as ballast are not permitted.
VEX electronics may not be used as non-functional decorations.
Decorations that visually mimic Field Elements or Scoring Objects are not permitted. The inspector and Head Referee will make the final decision on whether a given decoration or mechanism violates this rule.
Decorations cannot be designed to intentionally interfere with opponent Vision or Color Sensors. Teams will be asked to remove these decorations if the inspector or Head Referee determines that it interferes with opponent systems.
Decorations which provide feedback to a Robot (e.g., by influencing legal sensors) would be considered “functional,” and are not permitted.
Decorations that cover or obscure identifying features of electronics and/or pneumatics parts are not legal.
Teams will be asked to either replace the electronics and/or pneumatics part entirely, or remove the decoration if possible.
Identifying features include, but are not limited to, VEX logos, part numbers, and other distinctive colors or features of the part that allow an inspector to easily confirm it is a legal part.
<R24>A limited amount of custom plastic is allowed.Robots may use custom-made pieces cut from certain types of non-shattering plastic, up to 0.070” (1.78mm) thick.
Each Robot is limited to a maximum of 12 individual pieces cut from non-shattering plastic. This includes non-shattering plastic used in non-functional decorations.
Each individual piece of non-shattering plastic cannot be larger than 4” x 8” x 0.070”.
Teams must present and display ALL non-shattering plastic parts during inspection.
Inspectors will verify the total number of plastic pieces. They may use dry-erase markers or other forms of temporary marking to aid in counting.
Inspectors will verify that no non-shattering piece exceeds the size limitation.
Plastic may be mechanically altered by cutting, drilling, bending, etc. It cannot be chemically treated, melted, cast, or bonded to another part. Heating non-shattering plastic to aid in bending is acceptable.
Shattering plastics, such as PMMA (also called plexiglass, acrylic, or perspex), and structurally non-homogeneous plastics, such as woven (e.g., SRPP) and/or fiber-reinforced sheets, are prohibited.
Plastic sheets sold by VEX (such as the 276-8340 PET Sheets) are considered custom plastic in the context of this rule, and are subject to the same limitations as other plastic parts.
This rule does not apply to 3D printed plastic parts. 3D printed Robot parts are not permitted in the VEX V5 Robotics Competition for any purpose, including non-functional decorations.
Note: Teams are strongly encouraged to provide inspectors with 1:1 scale drawings, identical spares, or 1:1 scale tracings of their non-shattering plastic pieces to aid in inspection. Drawings and tracings should accurately reflect ALL shapes and dimensions of each piece. Complex bent/cut parts, and parts that are cut diagonally across a 4”x8” sheet to gain length may require more evidence.
This rule is applied differently for VEX U. See Rules VUR3 & VUR4.
Violation Notes:
Teams must replace broken plastic pieces that result in temporary, unintentional R24Violations.
<R25>Pneumatics are limited. A Robot’s pneumatic subsystem must satisfy all of the following criteria:
Teams may use a maximum of two (2) VEX Air Tanks (276-8749) on a Robot.
Pneumatic devices may be charged to a maximum of 100 psi.
The compressed air contained inside a pneumatic subsystem can only be used to actuate legal pneumatic devices (e.g., cylinders).
This rule is applied differently for VEX U. See Rule VUR14.
<R26>The VEX Pressure Gauge (276-8748) is a required part if a Robot includes pneumatics.
The gauge must be plumbed to the high pressure side of the system if the Team is using a regulator.
The pressure gauge must be visible and readable by referees and inspectors without moving or removing other Robot components or mechanisms.
The pressure gauge will be used to verify that the pneumatics system is charged to no more than 100psi, per R25.
The VEX Pressure Gauge on the Robot will take precedence over any off-board measurement.
<R27>Most modifications to non-electrical components are allowed. Physical modifications, such as bending or cutting, of legal metal structure or plastic components are permitted.
Modifying the arm of limit switches (by bending or trimming) or removing the rubber cap of bumper switches is permitted.
Metallurgical modifications that change fundamental material properties, such as heat treating or melting, are not permitted.
Pneumatic tubing may be cut to desired lengths.
Fusing/melting the end of legal nylon rope/string (see <R19d>) to prevent fraying is permitted.
Welding, soldering, brazing, gluing, or attaching parts to each other in any way that is not provided within the VEX platform is not permitted. Rule <R19c> is an exception to this rule.
Mechanical fasteners may be secured using Loctite or a similar thread-locking product. This may ONLY be used for securing hardware, such as screws and nuts.
This rule is applied differently for VEX U. See Rules VUR3, VUR12& VUR13.
<R28>No modifications to electronic or pneumatic components are allowed. Motors (including the V5 Smart Motor firmware), microcontrollers (including V5 Robot Brain firmware), cables, sensors, controllers, battery packs, reservoirs, solenoids, pneumatic cylinders, and any other electrical or pneumatics component of the VEX platform may NOT be altered from their original state in ANY way.
Teams may make the following modifications to the V5 Smart Motor (11W)’s user-serviceable features. This list is all-inclusive; no other modifications are permitted. Where applicable, the components listed below (in the specific applications listed below) are permissible exceptions to R19.
Replacing the gear cartridge with other official cartridges.
Removing or replacing the screws from the V5 Smart Motor Cap (276-6780).
Removing or replacing the threaded mounting inserts (276-6781).
V5 Smart Motors (11W) must use an official VEX V5 gear cartridge. For the purposes of this rule, the gear cartridges found within the V5 Smart Motor are considered “part of the motor.” Therefore, any physical or functional modifications to official gear cartridges is not permitted. V5 Smart Motors (11W) may only use official VEX motor cartridges
For the purposes of this rule, the V5 Smart Motor Cap is not considered “part of the motor.” Therefore, R27 applies.
External wires on VEX 2-wire or 3-wire electrical components may be repaired by soldering or using twist/crimp connectors, electrical tape, or shrink tubing such that the original functionality and length are not modified in any way.
Wire used in repairs must be identical to VEX wire.
Teams make these repairs at their own risk; incorrect wiring may have undesired results.
V5 Robot Brain accessories (short flanges, long flanges, and the magnetic screen protector) are considered “part of the V5 Robot Brain” and cannot be modified.
The modifications listed in clause A also apply to equivalent parts for the 276-4842 V5 Smart Motor (5.5W), with the exception of gear cartridges which only apply to the V5 Smart Motor (11W). For the purposes of this rule, the motor cap for the V5 Smart Motor (5.5W) is not considered “part of the motor,” and therefore R27 applies.
<T3>Drive Team Members are permitted to immediately appeal a Head Referee’s ruling. If Drive Team Members wish to dispute a score or ruling, they must stay in the Alliance Station until the Head Referee from the Match talks with them. The Head Referee may then choose to meet with the Drive Team Members at another location and/or at a later time so that the Head Referee has time to reference materials or resources to help with the decision. Once the Head Referee announces that their decision has been made final, the issue is over and no more appeals may be made (See rule T1 ); failure to accept this final decision may be considered a G1Violation. There is no system or opportunity for an appeal of the Head Referee’s final decision, either at or after the event.
Referees are not permitted to review any photo or video Match recordings when determining a score or ruling. Some events may also prohibit Drive Team Members from reviewing photo or video Match recordings while in the Alliance Station ; this should be announced to all Teams before Matches start.
Communication and conflict resolution skills are an important life skill for Students to practice and learn. In the VEX V5 Robotics Competition, we expect Students to practice proper conflict resolution using the proper chain of command. Violations of this rule may be considered a Violation of G1.
<T4>The Event Partner has ultimate authority regarding all non-gameplay decisions during an event. The Game Manual is intended to provide a set of rules for successfully playing VEX V5 Override; it is not intended to be an exhaustive compilation of guidelines for running a VEX V5 Robotics Competition event. Rules such as, but not limited to, the following examples are at the discretion of the Event Partner and should be treated with the same respect as the Game Manual.
<T5>Be prepared for minor Field variance.Field Element tolerances and Scoring Objects may vary from specified locations/dimensions; Teams are encouraged to design their Robots accordingly. Please make sure to check Appendix A for more specific nominal dimensions and tolerances.
Field Element tolerances may vary from nominal by up to ±1.0”.
Scoring Object placement at the beginning of the Match may vary from nominal by up to ±1” (25.4mm). If a Scoring Object is within tolerance, it should not be adjusted before the Match.
The Field Perimeter and Field Elements are designed to be assembled and disassembled multiple times each year. Event Partners store and transport Fields between events, and the individuals setting up the Field at one event may differ from those at the next. While every effort will be made to ensure minimal variance, Teams should expect that any Field may be slightly different than another, and prepare accordingly. Just because something works on one Field does not fully guarantee it will work on the next, and is not enough evidence alone to determine if a Field is out of tolerance.
<T6>Fields may be repaired at the Event Partner’s discretion. All competition Fields at an event must be set up in accordance with the specifications in Appendix A and/or other applicable Sections. Minor aesthetic customizations or repairs are permitted, provided that they do not impact gameplay (see T4 ).
Examples of permissible modifications include, but are not limited to:
Applying threadlocker to Field Element mounting hardware
Using non-VEX electrical tape to add required lines to the Field
Anchoring Field Elements directly to Field risers instead of the metal plates
Anchoring the metal plates to the underlying surface with hardware or tape
Utilizing a non-VEX Strap under the Field to tie walls together
Parts added to the exterior of the Portable Field Perimeter to assist in assembly, transportation, and rigidity during Matches
Modifications that may impact Robot functionality and/or how the game is played are generally not allowed. Examples of prohibited modifications include, but are not limited to:
Additional VEX structural parts attached to a Field Element
Replacing the opaque Field walls on the VEX Portable Competition Field Perimeter with transparent panels
Assembling a VEX Portable Competition Field Perimeter without including the securing straps
Affixing stickers to the foam Field Tiles or otherwise marking object placements for Field reset
Any specific repairs and/or modifications which pertain to the current season’s game will be documented in this rule and Appendix A, as needed.
<T7>Fields at an event must be consistent with each other. There are many types of permissible aesthetic and/or logistical modifications that may be made to competition Fields at the Event Partner’s discretion (see T6 ). If an event has multiple Head-to-Head competition Fields, they must all incorporate the same permissible/applicable modifications. If an event has multiple Robot Skills Challenge Fields, they must all incorporate the same permissible modifications. For example, if one Head-to-Head competition Field is elevated, then all Head-to-Head competition Fields must be elevated to the same height.
Examples of these modifications may include, but are not limited to:
Elevating the playing Field off of the floor (common heights are 12” to 24” [30.5cm to 61cm])
Utilizing non-VEX Straps to hold the Field walls together
Note: If an event has dedicated Fields for Robot Skills Matches, there is no requirement for them to have the same consistent modifications as the Head-to-Head Fields. See T21 for more details.
<T8>There are three types of Field control that may be used.
A VEXnet Field Controller controlled by Tournament Manager, which connects to a Controller’s competition port via ethernet cable.
A V5 Event Brain controlled by Tournament Manager, which connects to a Controller via Smart Cable.
A VEXnet Competition Switch, which connects to a Controller’s competition port via Cat-5 cable, may only be used in Practice Matches, Robot Skills Matches, and Leagues, and only under extreme circumstances.
If an event has multiple Fields, then all Fields of the same game type must use the same control system, in accordance with T7 and T21. For example, it would be permissible for Head-to-Head competition Fields to use V5 Event Brains, and for Skills Challenge Fields to use VEXnet Field Controllers. However, it would not be permissible for one Head-to-Head Field to use a V5 Event Brain while another Head-to-Head Field uses a VEXnet Field Controller.
Note: Official Qualifying Events may only use the official, unmodified version of Tournament Manager for field control, along with approved hardware and networking solutions. Add-ons that abide by the TM Public API guidelines are permitted. Once add-ons are enabled, the software is no longer supported by VEX Robotics, or DWAB Technologies; any necessary troubleshooting will be done at the user’s own risk.
<T9>There are two types of Field Perimeter that may be used.
If an event has multiple Fields, then all Fields of the same game type must use the same Field Perimeter type, in accordance with T7 and T21. For example, it would be permissible for Head-to-Head competition Fields to use metal Field Perimeters, and for Skills Challenge Fields to use Portable Field Perimeters.
A Qualification Match can only start before its scheduled time if all Teams, Robots, and assigned volunteers are at the Field and ready to play.
Any multi-division event must be approved by VEX Robotics prior to the event, and divisions must be assigned in sequential order by Team number.
The Match Schedule is subject to change at the Event Partner’s discretion. Events should generally wait to generate the Match Schedule until all Teams have checked in and passed Robot Inspection, or when it has been confirmed that Teams will not be participating.
If it is determined by both the Event Partner and VEX Robotics that a Team should be removed from further Matches at the event based on the outcome of a serious Violation, the Event Partner can use the full-event Disqualification feature in TM to remove that Team from all further Matches at the event. Their spots in later Qualification Matches will be replaced automatically by Teams from the end of the Match Schedule, and Matches will be removed from the end of the schedule as appropriate. The Event Partner cannot do this without permission from VEX Robotics.
<T11>Each Team will have at least six Qualification Matches.
A league must include at least three league ranking sessions, with at least one week between sessions. Each session must include a minimum of two Qualification Matches per Team at that session. The suggested number of Qualification Matches per Team for a standard league ranking session is four. Leagues will have a championship session where elimination rounds will be played. Event Partners may also choose to have Qualification Matches as part of their championship session.
<T12>Qualification Matches contribute to a Team’s ranking for Alliance Selection.
For Tournaments that have more than one division, Teams will be ranked among all Teams in their specific division.
When in a league, every Team will be ranked based on the number of Matches played. Teams that participate in at least 60% of the total Matches available will be ranked above Teams that participate in less than 60% of the total Matches available; e.g., if the league offers 3 ranking sessions with 4 Qualification Matches per Team, Teams that participate in 8 or more Matches will be ranked higher than Teams who participate in 7 or fewer Matches. Being a no-show to a Match that a Team is scheduled in still constitutes participation for these calculations.
<T14>Small Tournaments have fewer Alliances. The number of Alliances for a given event is determined as follows, except in extraordinary circumstances with the permission of VEX Robotics:
This rule is applied differently for VEX U. See rule <VUT6>.
<T15>Send a Student representative to Alliance Selection. Each Team must send one Student representative to the playing Field (or other designated area) to participate in Alliance Selection. If the Team representative fails to report in for Alliance Selection, their Team will be ineligible for participation in the Alliance Selection process.
Once the Alliance Selection begins, Student representatives cannot use electronic devices unless they have been demonstrated to be in airplane mode. No electronic communication by or with Student representatives is allowed during the Alliance Selection process.
Teams are advised to complete their scouting prior to the beginning of Alliance Selection, and to come to Alliance Selection prepared with a written list of potential Alliance Partners. Non-electronic methods of communication are allowed. Rule G2 and the Student-centered Policy still apply during Alliance Selection. Any communication about Alliance Selection and specific Teams should be limited to StudentTeam Members.
Note: Alliances must have two Teams, and there are no “do-overs” during Alliance Selection. If enough Teams decline their invitations such that the full number of Alliances cannot be filled, the event will proceed with a reduced number of Alliances.
<T17>Elimination Matches follow the Elimination Bracket. A sixteen (16) Alliance bracket plays as shown in Figure T17-1, with Matches proceeding in numbered order through each round.
If an event is run with fewer than 16 Alliances, then they will use the bracket shown in Figure T17-1, with Byes awarded when there is no applicable Alliance. For example, in a Tournament with 12 Alliances, Alliances 1, 2, 3, & 4 would automatically advance to the Quarterfinals.
At events with multiple divisions, each division champion Alliance will advance to the overall event finals. Alliance color assignment for these Matches will be determined by the original Alliance seeding within their respective divisions. The higher seeded Alliance (e.g., 1 is higher than 2) will be designated as the red Alliance, and the lower-seeded Alliance will be designated as the blue Alliance.
If both Alliances hold the same seed number within their divisions, the Event Partner will conduct a coin flip to determine which Alliance is assigned to the red Alliance, with the remaining Alliance assigned to blue.
<T18>Elimination Matches are a blend of “Best of 1” and “Best of 3.” “Best of 1” means that the winning Alliance in each Match advances to the next round of the Elimination Bracket. “Best of 3” means that the first Alliance to reach two wins will advance.
See the flowchart below for more information.
Figure T18-1: The process for determining how Elimination Matches should be played.
<T19>Ties in Elimination Matches lead to limited rematches. In the case of tied Matches during Elimination Matches, Tournament Manager will apply the following logic to determine which Alliance will progress to the next round.
In a “Best of 1” Elimination Round, the higher-seeded Alliance will advance and be declared the winner under the following guidelines.
For single-division events or within a division: in a ”Best of 3” Elimination Round, the higher-seeded Alliance will advance and be declared the winner under the following guidelines.
After three (3) ties in a round in which neither Alliance has yet won a Match (0-0).
After two (2) ties in a round in which each Alliance has won a single Match (1-1).
For single-division events or within a division: after two (2) ties in a “Best of 3” Elimination Round in which one Alliance has won a single Match (1-0), the Alliance with one (1) win will be declared the winner.
For a “Best of 3” overall Finals round at a multi-division event, Teams should continue to play tiebreaker Matches until one Alliance has won two (2) Matches.
Teams should review the event agenda and their Match Schedule to determine when the best possible time is to complete their Robot Skills Matches. If the Robot Skills Challenge area closes before a Team has completed all six (6) Robot Skills Matches, but it is determined that there was adequate time given, then the Team will automatically forfeit those unused Matches.
<T21>There is no requirement that Skills Challenge Fields have the same consistent modifications as the Head-to-Head Fields. For example, there is no requirement that all Skills Challenge Fields are elevated to the same height as Head-to-Head Fields. However, all Skills Challenge Fields at a single event must use the same type of Field control and Field Perimeter, as described in rules T8 and T9.
It is strongly recommended/preferred that all Skills Challenge Fields are consistent with each other, but this may not be the case in extreme circumstances. In order to use non-conforming Head-to-Head Fields for Skills Challenge runs (e.g. during lunch), the following steps should be taken:
Teams must be informed that the Head-to-Head Fields may have some differences from the Skills Challenge Fields (e.g., they might not have GPS strips).
Teams must be given an opportunity to select which type of Field they want to use, i.e. they cannot be required to use a Head-to-Head Field for any Skills Challenge run.
<T22>Skills Rankings at events.Teams will be ranked at an event based on the following scores and tiebreakers:
If a tie cannot be broken after all above criteria, then the following ordered criteria will be used to determine which Team had the “best” Autonomous Coding Skills Match :
Number of Toggles set to a color other than yellow
If the tie still isn’t broken, the same process in Step 9 will be applied to each Team’s best Driving Skills Match.
If the tie still isn’t broken, events may choose to allow Teams to have one more deciding Driving Skills Match, to be ranked according to the standard criteria above, or declare both Teams the Robot Skills Challenge Winner.
This rule is applied differently for the VEX AI Robotics Competition. See Rule VAIRS2.
<T23>Skills Rankings Globally.Teams will be ranked globally based on their Robot Skills scores from Tournaments and Leagues that upload results to events.vex.com, according to the following tiebreakers:
Earliest posting of the highest Autonomous Coding Skills Match score. The first Team to post a score ranks ahead of other Teams that post the same score at a later time, all else being equal.
Earliest posting of the highest Driving Skills Match score. The first Team to post a score ranks ahead of other Teams that post the same score at a later time, all else being equal.
This rule is applied differently for the VEX AI Robotics Competition. See Rule VAIRS2.
<T24>Robot Skills at League Events. At league events in which Teams may submit Robot Skills Challenge scores across multiple sessions, the Robot Skills scores (combined highest Autonomous Coding Skills Match and Driving Skills Match scores) used for rankings will be calculated from Matches within the same session.
For example, consider the following scores for a hypothetical Team across two league event sessions:
This Team would have a Robot Skills score of 140 for this event, and their scores from Session 2 would be used for the Event and Global tiebreakers listed in T22 and T23.
While many colleges and universities already use the VEX V5 system in their academic classes, many more have extensive manufacturing capabilities beyond the standard “VEX metal” library. Fabrication techniques like machining and 3D printing are more common than ever in collegiate engineering programs, and we can’t wait to see what VEX U Robotics Competition Teams from around the world are able to create under these more advanced rules.
As in past years, the season will include a culminating VEX U event at the VEX Robotics World Championship, along with regional Tournaments across the world. Participating schools will get the chance to prove their abilities in front of thousands of future engineers and show off what truly makes their school remarkable. The VEX U Robotics Competition is the perfect project-based supplement to many university level engineering programs, and gives Students the unique opportunity to demonstrate their real-world skills to potential employers, such as our event sponsors.
The VEX U Robotics Competition uses the VEX V5 Robotics Competition Override Field with some minor modifications. Anyone that has a VEX V5 Override Field can use it for a VEX U event or Team. Please consult earlier sections of this game manual for the basic set of competition rules and details. All of the standard rules apply, except for the modifications listed in this section. In the event of a conflict between rules, the rules listed in this Section of the game manual and any rulings on the official VEX U Q&A take precedence.
Additional Electronics - Any Sensor, processor, or other electronic component used in Robot construction, and connected to the V5 Robot Brain, that is not sold by VEX Robotics. Examples include commercially-available devices (e.g., Raspberry Pi) or custom devices designed and fabricated by the Team. See VUR12 and VUR13 for more details.
Alliance - A grouping of two (2) Robots from the same Team that have been chosen by the Students to play together during a given Match.
Electromechanical Assembly - A complex system composed of multiple off-the-shelf components, which may include Sensors, mechanical parts, and actuators.
External Processor - A computing device or microcontroller that independently processes Sensor data before sending it to the VEX V5 Brain.
Fabricated Part - Any component used in Robot construction that is fabricated by Team members. See VUR3 through VUR7 for more details.
Raw Stock - Stock materials purchased from third-party vendors that may be used to create Fabricated Parts. See VUR4 and VUR5.
Sensor - A device that detects and responds to changes in the environment, providing data to the Robot’s control system.
<VUG3>Some electronic devices may be in motion or moving at the beginning of the Match. This includes active cooling fans, spinning LIDAR modules, and/or other similar sensors or Additional Electronics. These electronic devices should not initiate any form of motion for the entire Robot or any of its subsystems, and may not directly interact with Scoring Objects and/or other Robots.
<VUG5>Different scoring during the Autonomous Period. For the purpose of determining the Autonomous Bonus winner, the following are included in Autonomous Period scoring calculations:
<VUT1> Instead of a 2-TeamAlliance format, VURC Head-to-Head Matches will be played 1-Team vs. 1-Team. Each Team will use two (2) Robots in each Match.
Teams are allowed to build and bring as many Robots as they would like, but only two (2)—one of each size as described in VUR1 —may be brought from the pit to the playing Field for any Match.
All Robots must pass inspection before they are allowed to compete.
<VUT2>Qualification Matches will be conducted in the same manner as in a VEX V5 tournament, but in the revised 1v1 format described in VUT1.
<VUT3>Elimination Matches will be conducted in the same manner as in a VEX V5 tournament, but without an Alliance Selection. At the end of the competition, one Team will emerge as the Tournament champion.
<VUT4> The Autonomous Period at the beginning of each Head-to-Head Match will be 30 seconds.
If both Teams complete their routines before 30 seconds have elapsed, they have the option to signal that they wish to end the Autonomous Period early. Both Teams and the Head Referee must all agree on the “early stop.” This is not a requirement, and the option must have been established for all Teams at the event, such as during the event meeting.
<VUT5> The Driver Controlled Period is shortened to 90 seconds and immediately follows the Autonomous Period.
<VUT6>VURC tournaments have fewer Teams in Eliminations. The number of Teams in Elimination Matches for a given event is determined as follows, except in extraordinary circumstances with the permission of VEX Robotics. A number of Teams below 16 will result in one or more Byes for highest-ranking Teams.
One Robot must be no larger than 24” (609.6 mm) x 24” (609.6 mm) x 24” (609.6 mm) at the start of the Match.
One Robot must be no larger than 15” (381 mm) x 15” (381 mm) x 15” (381 mm) at the start of the Match.
<VUR2>Teams may use any official VEX Robotics products, other than the exceptions listed in the tables below, to construct their Robot. This includes those from the VEXpro, VEX EXP, VEX IQ, VEX GO, VEX 123, VEX CTE, and VEX Robotics by HEXBUG* product lines. Rule R28 applies, but most modifications to non-electrical components are allowed.
Additive manufacturing processes, such as 3D printing.
Subtractive manufacturing processes, such as cutting, drilling, routing, or machining.
Bending, such as sheet metal braking or thermoforming.
Attaching materials to one another, such as welding or chemically bonding (e.g., epoxy).
Molding of non-metals, such as injecting polyurethane into a 3D printed mold.
<VUR4>Fabricated Parts must be made from legal Raw Stock. To be considered Raw Stock, the material must be obtained in one of the following forms before undergoing the fabrication processes listed in VUR3 :
Type
Shape / Profile
Examples
1
Sheet
Flat Plane
* Sheet metal * ⅛” polycarbonate sheet * Plywood
2
Solid Billet
“Thick” rectangular beam / block
* 4” x 4” x 6” solid aluminum billet * 2” x 2” x 2” acetal block
3
Solid Bar
“Thin” rectangular beam
* 2x4 wood planks * ¼” x 3” aluminum bars
4
Hollow Bar
Hollow rectangular beam
* 1” x 1”, 1/32” wall aluminum box tube
5
Solid Rod
Cylinder, Hexagonal or Rounded Hexagonal Stock
* ¼” steel rod * ¼” acetal rod * VEXpro Hex Shaft
6
Hollow Rod / Tube
Hollow Cylinder, Drilled/Threaded Hexagonal or Rounded Hexagonal Stock
Commercial Off-the-Shelf items that are intended to be used with minimal modification
* Wheels * Gears * Timing belts and pulleys
5
Materials that are intended to be cast or sintered
* Resin / powdered-bed 3D printing * Molten aluminum used for sand casting
Note: VUR2 takes precedence over this rule. Materials purchased from VEX Robotics that fall under one of these categories (e.g., VersaFrame pre-drilled extrusion) are permitted.
<VUR6>Fabricated Parts cannot be made from Raw Stock which poses a safety or damage risk to the event, other Teams, or Field Elements. Examples of prohibited materials include, but are not limited to:
Any material intended to produce flames or pyrotechnic effects.
Any material that is liquid at the time of the Match. Examples include hydraulic fluids, oils, greases, liquid mercury, and tire sealant.
This does not include fabrication processes that involve the use of liquids, such as milling coolant or epoxy.
Any matter that shatters or otherwise presents an excessive Field /safety hazard upon failure. Examples include fiberglass, acrylic, and carbon fiber sheet/tube stock.
This rule refers specifically to material legality itself. Any potentially unsafe mechanisms made from legal Raw Stock may still be addressed by S1 and R19.
3D printer filaments that include carbon fiber (or similar) additives or carbon fiber (or similar) inlay are exempt from this exception, and are considered legal for use in Fabricated Parts.
<VUR7>Fabricated Parts must be made by Team members. Any Fabricated Parts must be accompanied by documentation that demonstrates the Team’s design and construction process for that Fabricated Part.
The minimum acceptable form of documentation is an engineering drawing with multiple views for the part in question. These drawings may be included in a Team’s Engineering Notebook or in a standalone appendix to the Engineering Notebook.
Any Fabricated Part must have been entirely designed and produced by Team members. For example, parts ordered by the Team and 3D printed by a third party would be prohibited.
Teams will be required to provide this documentation as requested by inspectors, Head Referees, or judges at any time at an event. Failure to provide acceptable documentation will result in the part being deemed illegal for use; therefore, R2, <G5>, and/or G1 will apply.
<VUR8>Teams may use commercially-available springs on their Robots. For the purposes of this rule, a “spring” is any device used for storing and releasing elastic potential energy. Examples include, but are not limited to:
Compression, tension, torsion, constant force, or conical springs made from spring steel.
Springs made from elastic thread or rubber, such as surgical tubing, bungee cords, or stretchable braided rope.
Closed-loop (pneumatic) gas shocks.
Note: Gas shocks are not considered pneumatic devices in the context of VUR14. Gas shocks may not be modified in any way.>
<VUR9>Teams may use commercially available fastener hardware on their Robot. Examples include (but are not limited to):
Screws, nuts, rivets, and heatset inserts
Hinges, pins, rod ends, threaded rods, and hose clamps
Ancillary fastener accessories, such as washers or spacers
Adhesives such as epoxy, glue, or tape (only when used to join together two parts)
If the primary function of the part is not “fastening”, then VUR5, VUR6, and/or VUR7 take precedence over this rule. Illegal examples include (but are not limited to):
A prefabricated non-VEX wheel, even though it may technically connect tread to a shaft
80/20 extrusion; other items get “fastened to it”, it is not the part doing the “fastening”
Using grip tape to improve wheel traction
<VUR10> Each Robot must utilize exactly one (1) V5 Robot Brain and at least one (1) V5 Robot Radio connected to a V5 Controller.
Wireless communication between Robots is permitted if using legal V5 Robot Brains and V5 Robot Radios. No other types of wireless communication protocols (e.g., radio, Bluetooth, Wi-Fi) are permitted.
<VUR11> There is no restriction on the number of V5 Smart Motors, 11W (276-4840) and/or 5.5W (276-4842) that Robots may use. No other motors, servos, or electronic actuators are permitted, including those sold by VEX (e.g., the 2-Wire 393 Motor).
Note 1: Rule R28 still applies in VEX U. Teams may not modify Smart Motors, and must use official/unmodified gear cartridges.
Note 2: Commercially available pneumatic actuators and pneumatic solenoids are permitted within the guidelines of VUR14.
Note 4: The 55W drivetrain limit specified in R11 does not apply for VEX U.
<VUR12> There is no restriction on commercially available Sensors, External Processors, or Additional Electronics that Robots may use for sensing and processing, except as follows:
Sensors and External Processors MUST be connected to the V5 Robot Brain via any of the externally accessible ports (i.e., without any modification to the commercially available electronics). A Sensor may be connected to an External Processor which then connects to the V5 Robot Brain.
Directly from the V5 Robot Brain via any externally accessible port.
From an additional lithium ion, lithium iron, or nickel metal hydride battery pack (only one (1) additional battery can be used for Sensor/processing power). This additional battery pack must operate at a maximum of less than 13 volts.
Standalone motors which serve no additional sensing or processing functionality (e.g., using a commercially-available brushless motor in a drivetrain) are not considered legal Additional Electronics, and would be considered a Violation of VUR11.
Pneumatic solenoids are the only types of solenoids that are permitted as Additional Electronics. Solenoids used for any purpose other than opening and closing a pneumatic valve are considered an actuator and therefore prohibited, per VUR11.
R28 still applies in VEX U, Teams may not alter or modify electronic parts from the VEX product lines. It is legal to rotate the blocks of the V5 Optical Sensor and V5 Distance Sensor relative to their bases, and to manufacture custom back plates for these sensors.
<VUR13> Commercially available Electromechanical Assemblies are not legal for use on Robots.
For the purposes of this rule, any system that integrates Sensors with other mechanical parts that are fabricated by anyone other than Team members and which serve more use than the basic definition of a Sensor would be considered an Electromechanical Assembly, and is therefore not legal.
Examples may include but are not limited to: odometry pods.
Commercially available Sensors with simple plastic housings that do not have any use beyond protecting internal components and aiding in mounting of the Sensor are not considered Electromechanical Assemblies.
<VUR14>Teams may utilize an unlimited amount of the following commercially available pneumatic components: cylinders, actuators, valves, gauges, storage tanks, regulators, manifolds, tubing, and solenoids.
Pneumatic devices may only be charged to a maximum of 100 psi.
Compressors or any other forms of “on-Robot ” charging are not permitted.
All commercial components must be rated for 100 psi or higher. Teams should be prepared to provide documentation that verifies these ratings to inspectors if requested.
Components must not be modified from their original state, other than the following exceptions:
Cutting pneumatic tubing or wiring to length; assembling components using pre-existing threads, brackets, or fittings; or minor cosmetic labels
If commercially available 12V solenoids are used, these are considered Additional Electronics and must therefore satisfy all conditions listed in VUR12. 12V solenoids may be either powered by an additional power source (per <VUR12d>), or by a 5V-12V step-up converter from the V5 Robot Brain. If an external power source (or other Additional Electronics device) is used to interface with the solenoid, Teams MUST be able to demonstrate that there is no way for the solenoid to receive power while the Robot is receiving a Disabled state from the field controller.
<VUR15>Teams may use commercially available bearings on their Robot. For the purpose of this rule, a ‘bearing’ is a part that supports external loads, reduces friction, and improves efficiency by facilitating smooth dynamic motion between components. Legal examples include (but are not limited to):
Parts supporting rotational motion: radial bearings, roller bearings, thrust bearings, needle bearings, one-way bearings, bushings, etc.
Parts supporting linear motion: linear bearings, linear slides, drawer slides, etc.
We want to see Universities face off in a global head-to-head competition. Schools are not limited to one Team, and a Team may consist of multiple colleges, but we hope that each Team identifies with and proudly represents one (1) post-secondary institution. (e.g., “Clarkson University” vs. “UC Santa Barbara”). Of course, university-level “club” Teams and mixed composition Teams are encouraged to join! However, as noted in the Student Eligibility Policy, Students who have not yet graduated secondary school are not eligible to participate in VEX U, even if they are “dual-enrolled” or taking post-secondary courses. A Student cannot be a member of a VEX V5 and a VURC Team simultaneously, regardless of eligibility.
This document will provide Bill of Materials (BOM) information and detailed specifications for the Official Competition Field.
Please note: this Field can utilize both the VEX Portable Competition Field Perimeter (276-8242 and the VEX Competition Field Perimeter (278-1501) developed by VEX Robotics. Instructions and specifications for these Field Perimeters are available in separate documents and are important for the Field assembly.
There is also an accompanying STEP file which can be imported into most 3D modeling programs (e.g., Inventor, Sketchup, Solidworks, etc.). This 3D model shows the “official” setup of a VEX V5 Robotics Competition Override competition Field, as well as detailed models of individual Field Elements. For additional game-play detail, please refer to the VEX V5 Robotics Competition Override Game Manual.
VEX V5 Override is played on a 12ft x 12ft foam mat, surrounded by a Field Perimeter, with nine (9) Goals, four (4) Loaders, and four (4) Toggles on the Field.
The VEX V5 Override Field consists of fifty-six (56) Cups and sixty-three (63) Pins.
For more details and specific gameplay rules, please refer to the VEX V5 Override Game Manual.
This section will outline the specifications that are most important to Teams designing a Robot to compete in VEX V5 Robotics Competition Override. Though many of the critical dimensions are included in this section, it may be necessary to consult the separate assembly guide and 3D CAD models of the Field for an additional level of detail. If you can’t find a dimension in the specifications, we include a full model of the Field to “virtually” measure whatever dimension is necessary.
Field components may vary slightly from event to event. This is to be expected; Teams will need to adapt accordingly. It is good design practice to create mechanisms capable of accommodating variances in the Field and Scoring Objects.
Note: Minor Field repairs are permissible, provided that the repairs do not affect gameplay. Examples of minor Field repairs include (but are not limited to) threadlocker applied to Field Element mounting hardware. Be sure to check the Official Q&A for specific examples or to get an official clarification.
Appendix B - Glossary of Terms
Adult - Anyone who is not a Student or another defined term (e.g., Head Referee ).
Alliance - A pre-assigned grouping of two Robots that are paired together during a given Head-to-Head Match.
Alliance Station - The designated regions where the Drive Team Members must remain for the duration of the Match.
Autonomous Bonus - A point bonus awarded to the Alliance that has earned the most points at the end of the Autonomous Period. See SC7 for more information.
Autonomous Line - The pair of white tape lines that run diagonally across the Field and around the Midfield, and the space between those lines. See SG7 for more information.
Autonomous Period - A time period during which Robots operate and react only to sensor inputs and pre-programmed commands.
Autonomous Points (AP) - The second basis of ranking Teams. An Alliance who wins the Autonomous Bonus during a Qualification Match earns ten (10) Autonomous Points. In the event of a tie, both Alliances will receive five (5) Autonomous Points.
Autonomous Win Point (AWP) - An additional Win Point awarded to any Alliance that has completed a defined set of tasks at the end of the Autonomous Period of a Qualification Match. Both Alliances can earn an Autonomous Win Point if both Alliances accomplish these tasks. See SC7 for more information.
Builder - Any StudentTeam member who helps build the Robot. Adults are permitted to teach Builders associated concepts, but should never work on the Robot.
Bye - A situation in which an Alliance automatically advances to the next round of Tournament play without competing.
Coder - Any StudentTeam member who contributes to the computer code that is downloaded onto the Robot. Adults are permitted to teach Coders associated concepts, but should never work on the code that goes on the Robot.
Cup - A Scoring Object, measuring approximately 3.15” (80mm) in diameter and 6.5” (164.5mm) tall. Each Cup consists of two halves: one transparent and one opaque.
Defensive - A category of strategies, Robot actions, and/or Robot statuses that can be employed by a Team during a Match ; see rules GG14 and GG15 for more information. A Robot is Defensive while it is engaged in actions that cannot increase its Alliance’s score for the current Match, and instead limits an opponent’s ability to score or play the game. A Robot can be in Possession of a Scoring Object and capable of scoring, but still be Defensive based on its actions. Examples include, but are not limited to:
De-scoring in a way that doesn’t increase points for the Robot’s own Alliance
Limiting access to a portion of the Field while not attempting to score
Holding, blocking, impeding, or otherwise restricting or controlling an opponent’s movements
Designer - Any StudentTeam member who helps design the Robot to be built for competition. Adults are permitted to teach Designers associated concepts, but should never work on the design of the Robot.
Disablement - A penalty applied to a Team for a safety Violation. A Team that receives a Disablement is not allowed to operate their Robot for the remainder of the Match, and the Drive Team Member (s) will be asked to place their controller(s) on the ground or another safe location outside of the Field, as directed by the Head Referee.
Entanglement - A Robot status. A Robot is Entangled if it has grabbed, hooked, or attached to an opposing Robot or a Field Element. See rule GG14.
Event Partner - The volunteer VEX V5 Robotics Competition Tournament coordinator who serves as an overall manager for the volunteers, venue, event materials, and all other event considerations.
Field Element - The Field, white tape, Loaders, Goals, Toggles, and all supporting structures and accessories (such as field monitors, etc.).
Field Perimeter - The outer part of the Field, made up of 12 straight sections.
Floor - The interior flat part of the playing Field, made up of an array of six (6) gray foam field tiles wide by six (6) gray foam field tiles long (totaling 36 Field tiles) that are within the Field Perimeter.
Game Design Committee (GDC) - The creators of Override, and authors of this Game Manual. The Game Design Committee is the only official source for rules clarifications and Q&A responses; see Section 1.
Goal - One of the nine (9) designated locations around the Field in which Robots attempt to score Pins and Cups. Goals are octagonal, and each Goal is one of three colors: red, blue, or black. The center Goal is 8.7” (222.7mm) tall, neutral Goals in Quadrants are 5.8” (146.5mm) tall, and Alliance -specific Goals are 3.25” (82.5mm) tall.
Figure G-1: The four types of Goals in a VEX V5 Override Match
Head Referee - A certified impartial volunteer responsible for enforcing the rules in this manual as written. Head Referees are the only people who may discuss ruling interpretations or scoring questions with Teams at an event. Large events (e.g., Signature Events, World Championships, etc.) might include multiple Head Referees at the Event Partner’s discretion.
Holding - A Robot status; see rule GG17 for more information. Holding is legal until it exceeds the limits in GG17. A Robot is considered to be Holding if it meets any of the following criteria during a Match :
Trapping - Limiting the movement of an opponent Robot to a small or confined area of the Field, approximately the size of one foam field tile or less, without an avenue for escape. Note that if a Robot is not attempting to escape, it is not considered Trapped.
Lifting - Controlling an opponent’s movements by raising or tilting the opponent’s Robot off of the Floor. Preventing a Robot that is already off of the Floor from returning to the Floor may also be considered Lifting or Trapping.
Load Zone - An infinitely tall three-dimensional volume bounded by the inner edges of the Field Perimeter and the outer edges of the red or blue tape lines surrounding each Loader.
Match Schedule - A list of Matches that is generated at the start of an event. The Match Schedule includes the predetermined, randomly-paired Alliances that will be competing in each Qualification Match, and the expected start times for these Matches. The Match Schedule may be subject to change at the Event Partner’s discretion.
Midfield - The square-shaped central area of the Field in which Robots attempt to end the Match to score additional points. The Midfield is an infinitely tall three-dimensional volume bounded by the inner edges of the white tape line square, and can be entered by all Robots during the Autonomous Period See Figure Q-1.
Notebooker - Any StudentTeam member who contributes to the Team’s engineering notebook or associated documentation. Adults are permitted to teach Notebookers associated concepts, but should never work on the engineering notebook or other documentation.
Offensive - A category of strategies, Robot actions, and/or Robot statuses that can be employed by a Team during a Match ; see rules GG14 and GG15 for more information. A Robot is Offensive while it is engaged in actions that could directly increase its Alliance’s score for the current Match. Examples include, but are not limited to:
Pin - A Scoring Object measuring approximately 1.6” (40mm) in diameter and 6.5” (165mm) tall. Each Pin consists of two Pin Halves, with one of the following color combinations: red/yellow, blue/yellow, red/blue, or yellow/yellow.
Figure P-1: The four types of Pins in a VEX V5 Override Match
Pin Half - One of two halves that make up a Pin. Each Pin Half is colored red, blue, or yellow.
The Robot’s movement in all directions would result in maintained control of the Scoring Object (i.e., the Scoring Object moves along with the Robot as the Robot turns and moves forward, backward, left, and right).
Example 2 (No Possession): Scoring Objects being pushed forward on the Floor by the front face of a Robot would not be considered Possessed by that Robot, since driving backward would cause the Robot to lose control of those Scoring Objects (i.e., the Scoring Objects would not move backward with the Robot, and would become separated from it). This remains true whether the Robot’s face is flat, convex, or concave, as long as movement in at least one direction would result in the Robot losing control of the Scoring Object(s).
Preload - The Pins, one (1) per Robot, placed by each Team prior to the start of each Match. See SG5.
Quadrant - One of four designated triangular areas of the Field. Each Quadrant contains two Goals and one Toggle. Robots may score Pins in the Goals within a Quadrant and may attempt to set that Quadrant’s Toggle to control ownership of yellow PinsScored in that Quadrant.
A Quadrant is defined by the outer edges of the white tape lines, the Field Perimeter, and the colored tape that defines the Load Zones.
Robot - A machine that has passed inspection, designed by StudentTeam members to execute one or more tasks autonomously and/or by remote control from a Drive Team Member.
Scorekeeper Referee - An impartial volunteer responsible for tallying scores at the end of a Match. Scorekeeper Referees do not make ruling interpretations, and should redirect any Team questions regarding rules or scores to a Head Referee.
Strategist - Any StudentTeam member who contributes to the Match strategies used to score points during a Qualification Match or Robot Skills Match, including assessing the impact of other Teams’ performance and strategies on the Team’s strategy (e.g., scouting). Adults are permitted to teach Strategists associated concepts, but should never create or dictate a Team’sMatch strategy.
Strength of Schedule Points (SP) - The third basis of ranking Teams. Strength of Schedule Points are equivalent to the score of the losing Alliance in a Qualification Match. In the event of a tie, both Alliances receive Strength of Schedule Points equal to the tie score. If both Teams on an Alliance are Disqualified, the Teams on the not Disqualified Alliance will receive their own score as Strength of Schedule Points for that Match.
Student - A person that meets the Student Eligibility Policy requirements for their respective competition program and level.
Team - One or more Students make up a Team. In the context of this game manual, Student Team members fill multiple roles related to Robot design, build, coding, strategy, and documentation. See G2, G4, G5 for more information. Adults may not fulfill any of these roles. See Appendix D for more information about Team classifications and Student roles.
Time-out - A single break period no greater than three minutes (3:00) allotted for each Alliance during the Elimination Bracket. See GG7.
Toggle - One of four (4) triangular shaped Field Elements mounted to the Field Perimeter, which determine Ownership status of yellow Pin Halves in the corresponding Quadrant. Each Toggle has 3 differently colored sides that, when viewed from inside the Field, indicate whether the Toggle is neutral (yellow) or set to an Alliance color (red or blue). Toggles are 25.8” (656.2mm) long, and each face of the triangle is approximately 2.05” (52.2mm) wide. See SC4 for more information.
Win Percentage (WP) - Replaces Win Points in a league event. Win Percentage is calculated by the number of wins divided by the number of Qualification Matches the Team plays. In cases of a tie, the Team is given a 0.5 number of “wins” for that Match. The Autonomous Win Point is also considered 0.5 “wins,” added to the total number of wins.
Win Points (WP) - The first basis of ranking Teams. Teams will receive zero (0), one (1), two (2), or three (3) Win Points for each Qualification Match. Unless a Team is Disqualified, both Teams on an Alliance always earn the same number of Win Points.
This appendix is intended to provide additional guidance regarding rule Violations within the VEX V5 Robotics Competition, and offer further explanation on how Violations may be interpreted and enforced during Matches. It is designed to promote consistency in officiating and to help Teams better understand how actions on the Field may impact scoring, Match outcomes, and referee decisions.
This appendix does not supersede any existing rule, but instead serves as a secondary resource to aid in their application. If no Violation Notes are found in a given rule, then it should be assumed that the below “default” definitions apply.
Violation - The act of breaking a rule in the Game Manual.
The Match will not begin with any conditions in this rule unmet. If a Robot cannot meet these conditions in a timely manner, the Robot will be removed from the Field and rules <R2d> and GG2 will apply until the situation is corrected. They will not receive a Disqualification, but should receive a Minor Violation and will not be permitted to play in the Match.
Intentional, strategic, or egregious Violations, such as intentional contact with an opposing Robot while contacting the foam tiles on the opposing side of the Autonomous Line, or the interactions described in <SG7e> will be considered Major Violations and should result in a Disqualification for the Match.
Incidental interactions, such as unintentional contact with the Goal and/or Scoring Objects stacked on the Goal, should typically be considered Minor Violations.
Intentional interactions, as well as any interactions (intentional or unintentional) involving the addition or removal of Scoring Objects on the Goal, will be considered Major Violations.
For the purposes of Match Affecting calculations, each illegal Match Load should be considered worth a value of 3 points. These values are not added to the actual score. If subtracting 3 points per illegal Match Load from the offending Alliance’s final score would change the outcome of the Match, then the SG11Violation should be considered Match Affecting.
Any Violation of G1 may be considered a Major Violation and should be addressed on a case-by-case basis. Teams at risk of a G1Major Violation due to multiple disrespectful or uncivil behaviors will usually receive a “final warning”, although the Head Referee is not required to provide one.
Potential Violations of this rule will be reviewed on a case-by-case basis. By definition, all Violations of this rule become Match Affecting as soon as a Robot which was built or programmed by an Adult scores points in a Match.
Teams believed to be in Violation of this rule should be reported to the Judge Advisor, Head Referee, or Event Partner for further investigation in coordination with VEX Robotics. Based on the investigation the Team may be removed from further Matches, have their Robot Skills Match scores removed, and/or be removed from consideration from judged awards.
Violations of this rule will be evaluated on a case-by-case basis, in tandem with VEX Robotics as noted in G1 and G2.
Major Violations of this rule should be rare, as Robots should never be designed to intentionally violate it. Minor Violations are usually due to Robots being damaged during gameplay, such as a wheel falling off.
The intent of this rule is to ensure that Robots abide by commands sent by the tournament software. Temporarily removing the cable to assist with mid-Match troubleshooting, with an Event Partner or other event technical staff present and assisting, would not be considered a Violation.
In most cases, if a Team causes their opponent to break a rule, the Head Referee will simply not enforce the penalty on that opponent, and it will be considered a Minor Violation for the Team that forced a Violation. However, if the forced situation becomes Match Affecting in favor of the Team that forced the Violation, it will be considered a Major Violation for the Team that forced the Violation.
When determining whether a HoldingViolation was Match Affecting, they should consider the full context of the Match and both Robots’ actions, including the following. Because the first three seconds of a Hold are legal game play and not a Violation, only the extended portion of a Hold should be considered. Holding is an inherently Defensive action, so rule GG15 may also be considered if a judgment call is required.
How much extra time was included in the Holding interaction
How long the Robots were separated if the HoldingRobot backs away and returns too early
What both Robots were doing within the larger context of the Match
Teams must replace broken plastic pieces that result in temporary, unintentional R24Violations.
Appendix D - Team Classifications and Student Roles
One or more Students make up a Team. To participate in an official VEX V5 Robotics Competition event, a Team must first register on events.vex.com and receive a VEX V5 Robotics Competition Team number. A Team’s unique number identifies their organisation and their Team within that organisation. Each Team must design and build their own Robot, create their own code, develop their own strategies to play the game, and maintain their own engineering notebook if they choose to use one.
A Team is classified as a Secondary School Team if all members are Secondary School Students.
A Team is classified as a Secondary School Team if any of its members are Secondary School Students, or if the Team is made up of Secondary School Students who declare themselves “playing up” as Secondary School Students by registering their Team as a Secondary School Team.
Once a Team has competed in an event as a Secondary School Team, that Team may not change back to a Secondary School Team for the remainder of the season. If a Team mistakenly registers as a Secondary School Team but is ineligible for that age group, their registration may be revised mid-season with the assistance of VEX Robotics; all prior qualifications for the season will be lost.
Teams may be associated with schools, community/youth organizations, or groups of neighborhood Students.
In the context of this Game Manual, StudentTeam members fill multiple roles related to Robot design, build, coding, strategy, and documentation. See G2, G4, G5 for more information. Adults may not fulfill any of these roles.
Designer - Any StudentTeam member who helps design the Robot to be built for competition. Adults are permitted to teach Designers associated concepts, but should never work on the design of the Robot.
Builder - Any StudentTeam member who helps build the Robot. Adults are permitted to teach Builders associated concepts, but should never work on the Robot.
Coder - Any StudentTeam member who contributes to the computer code that is downloaded onto the Robot. Adults are permitted to teach Coders associated concepts, but should never work on the code that goes on the Robot.
Strategist - Any StudentTeam member who contributes to the Match strategies used to score points during a Qualification Match or Robot Skills Match, including assessing the impact of other Teams’ performance and strategies on the Team’s strategy (e.g., scouting). Adults are permitted to teach Strategists associated concepts, but should never create or dictate a Team’sMatch strategy.
Notebooker - Any StudentTeam member who contributes to the Team’s engineering notebook or associated documentation. Adults are permitted to teach Notebookers associated concepts, but should never work on the engineering notebook or other documentation.
Override Manual Versions
Every edition of the Override manual published this season. The Version menu at the top of each page opens the same page in another edition, and Compare with shows what changed on that page since an earlier one, side by side with its wording. On a phone, both are in the menu.